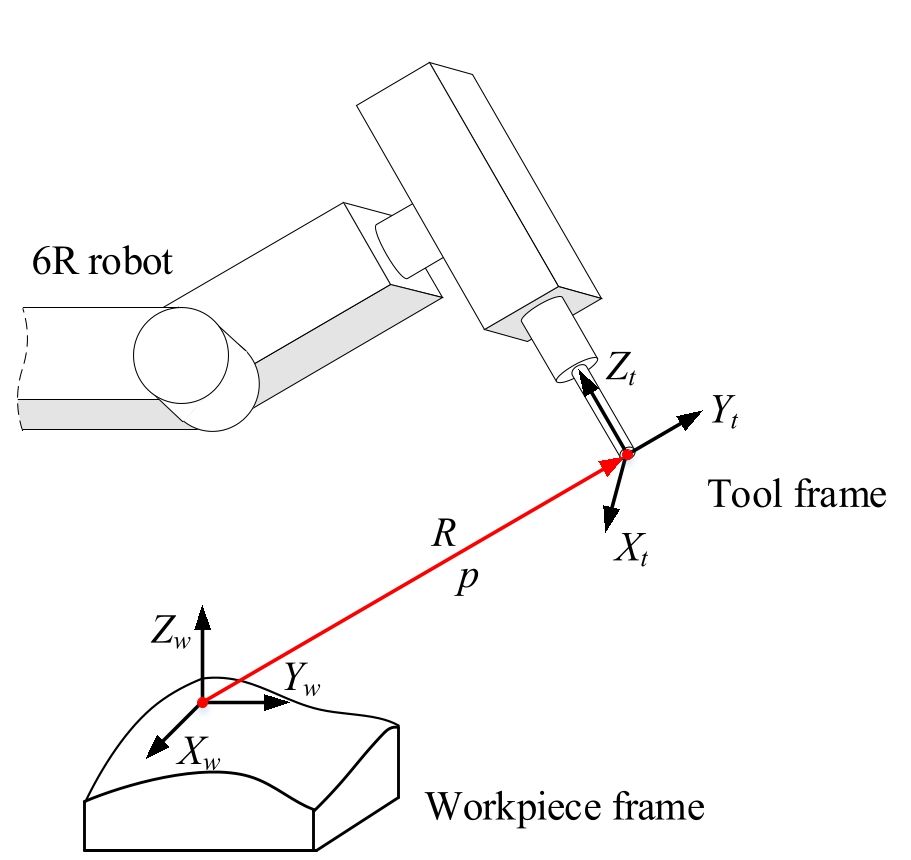
Fig. 1.
Transformation of tool frame related to workpiece frame in robotic machining system
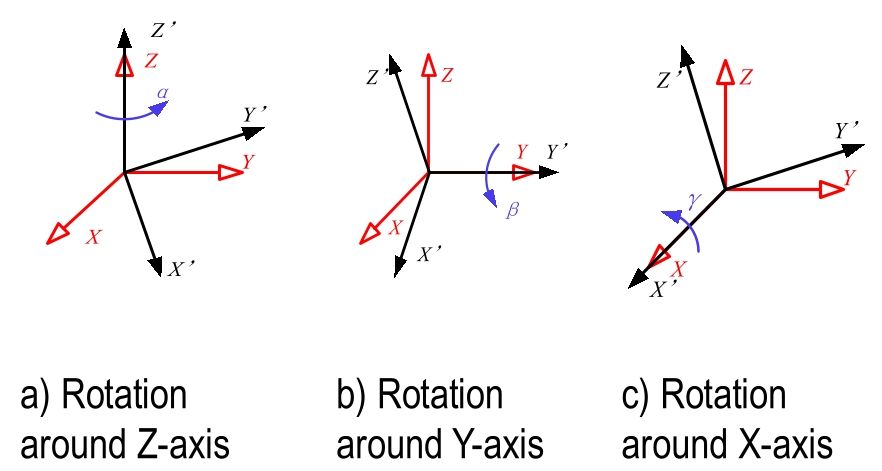
Fig. 2.
Rotation around fixed global coordinate system
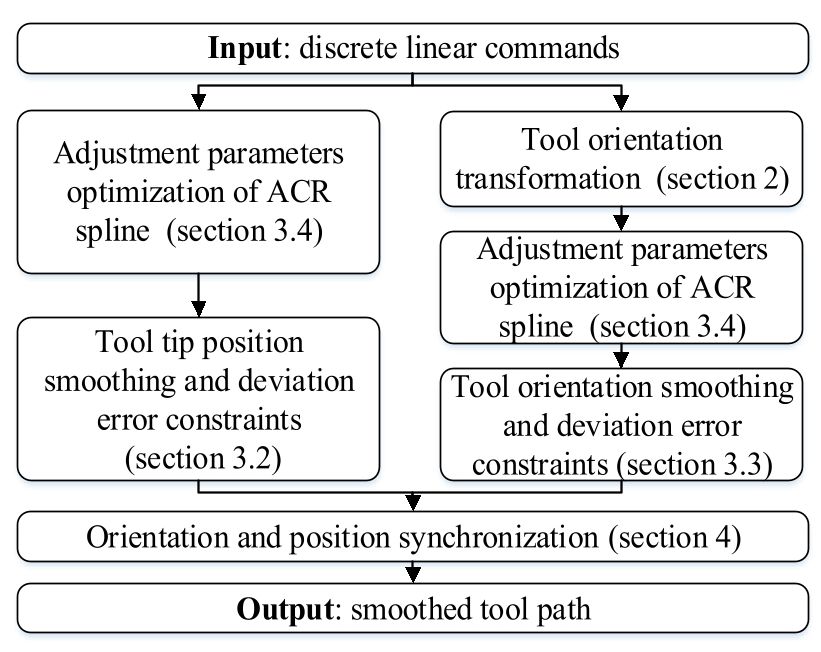
Fig. 3.
Flowchart of the proposed tool path smoothing method
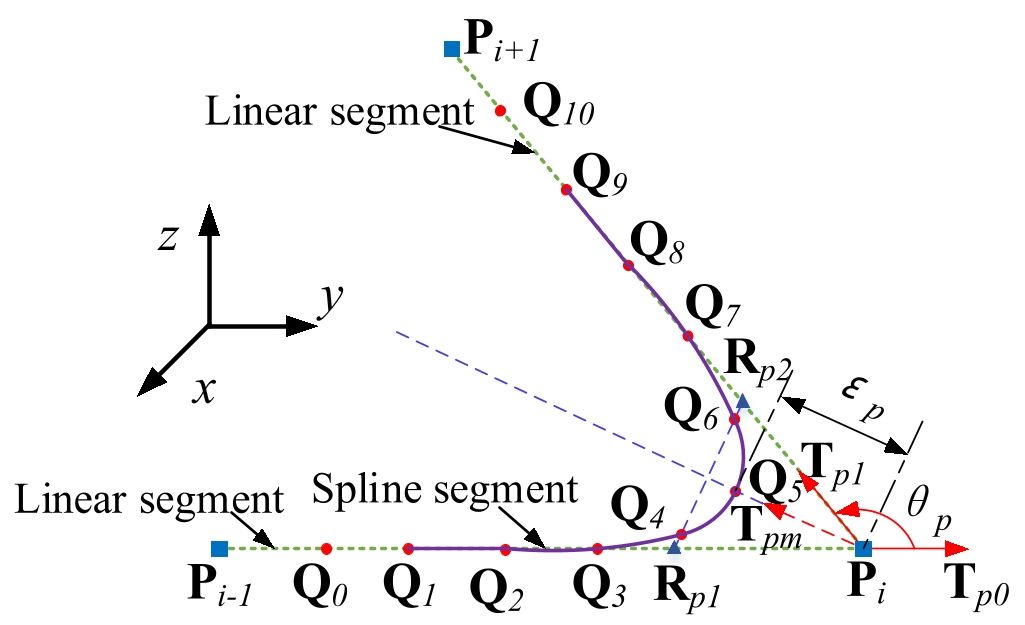
Fig. 4.
Corner smoothing of tool tip position
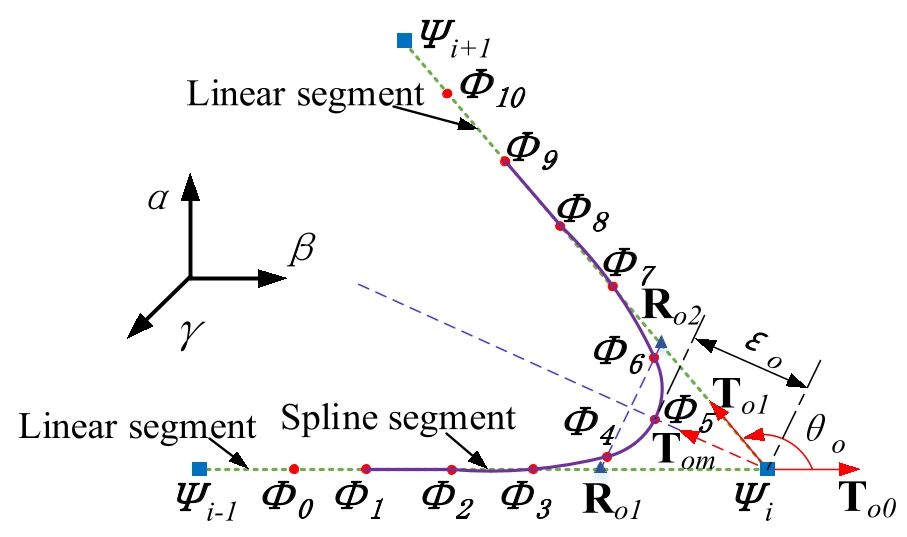
Fig. 5.
Corner smoothing of tool orientation
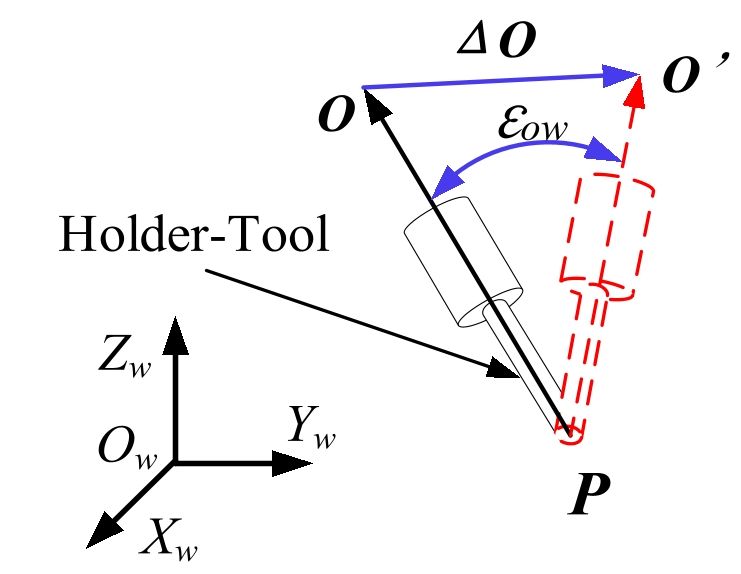
Fig. 6.
Tool orientation error in the WCS
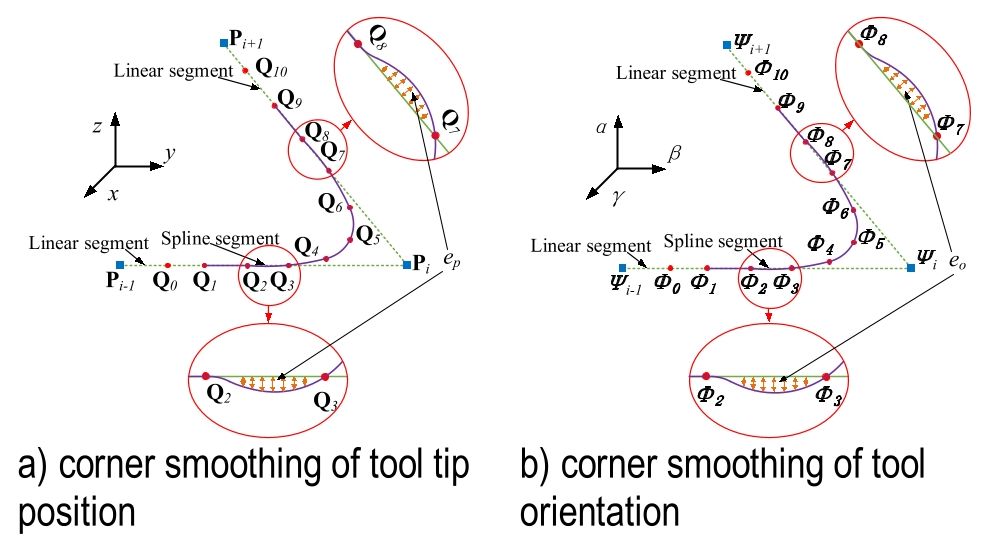
Fig. 7.
The deviation between spline segment and linear segment
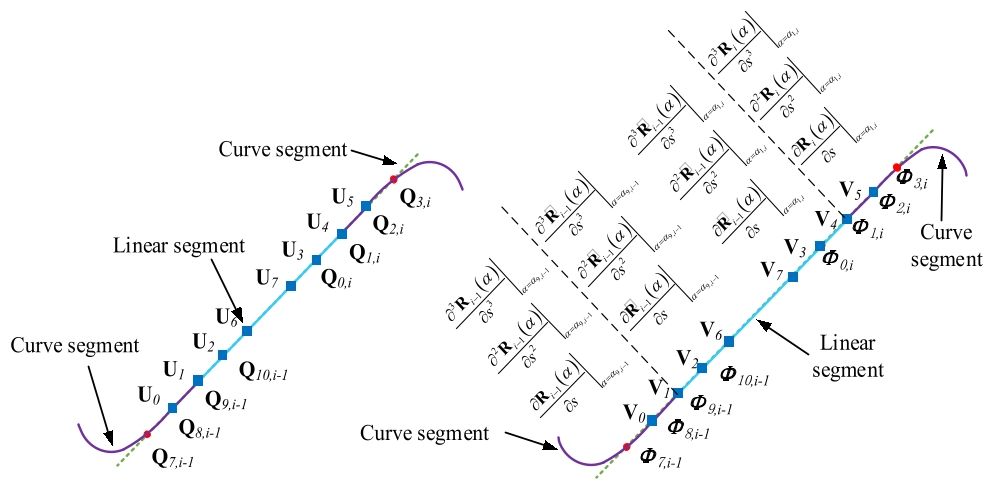
Fig. 8.
Synchronization of the tool tip position and orientation
Tab. 1.
Parameters of the testing tool path
| No. of corners | No. of tool path | Tool tip position (x, y, z)(mm) | Tool orientation(α,β,γ) (rad) |
|---|---|---|---|
| 1 | 1 | (240, 200, 220) | (0.6283, 0.5236, 0.3142) |
| 2 | (230, 240, 250) | (1.0472, 0.7854, 0.3927) | |
| 2 | 3 | (270, 230, 252.2) | (0.3142, 0.1571, 0.2094) |
| 3 | 4 | (250, 210, 242) | (0.6283, 0.7854, 0.5236) |
| (235, 230, 246.8) | (0.3142, 0.3927, 0.5236) |
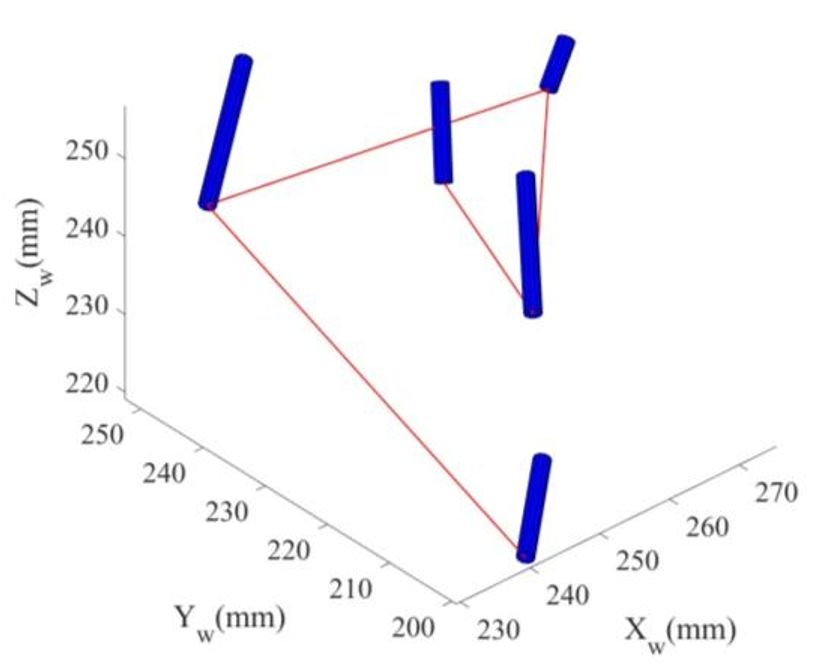
Fig. 9.
The testing tool path utilized in numerical simulation
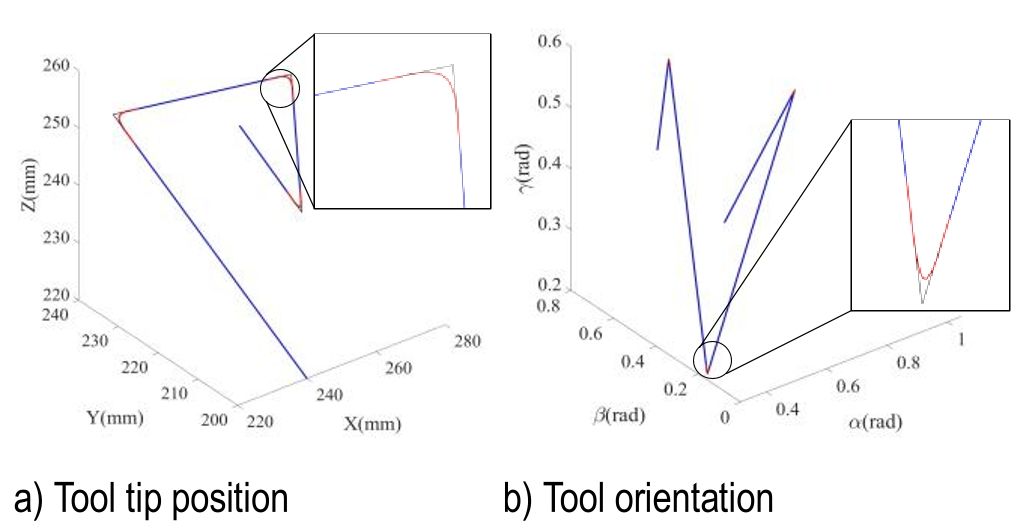
Fig. 10.
The smoothed tool tip position and tool orientation
Tab. 2.
Deviation errors of the tool tip and tool orientation with error tolerances εp = 0.8mm and ε0 = 0.01rad
| No. of corners | 1 | 2 | 3 | |
|---|---|---|---|---|
| Tool tip Position error | εp (mm) | 0.8 | 0.8 | 0.8 |
| εp(mm3) (κ,λ) | 5.4858e-06 (0.48, - 5.4e-4) | 2.3160e-06 (0.51, -1.4e-4) | 3.9818e-05 (0.47, 5.3e-4) | |
| Tool orientation error | ε0 (rad) | 0.01 | 0.01 | 0.01 |
| ε0 (rad3) (κ,λ) | 2.2647e-11 (0.46, -2.4e-3) | 1.2184e-10 (0.49, 7.2e-3) | 2.8408e-11 (0.47, -3.0e-3) | |
Tab. 3.
Deviation errors of the tool tip and tool orientation with error tolerances εp = 1.2mm andε0 = 0.005rad
| No. of corners | 1 | 2 | 3 | |
|---|---|---|---|---|
| Tool tip Position error | εp (mm) | 1.2 | 1.2 | 1.2 |
| ep (mm3)(κ,λ) | 1.8557e-05 (0.48, -8.1e-4) | 7.8179e-06 (0.51, -2.2e-4) | 1.3406e-04 (0.47, 7.9e-4) | |
| Tool orientation error | ε0 (rad) | 0.005 | 0.005 | 0.005 |
| e0 (rad3) (κ,λ) | 2.8111e-12 (0.46, -1.2e-3) | 1.5905e-11 (0.49, 3.6e-3) | 3.5244e-12 (0.47, -1.5e-3) | |
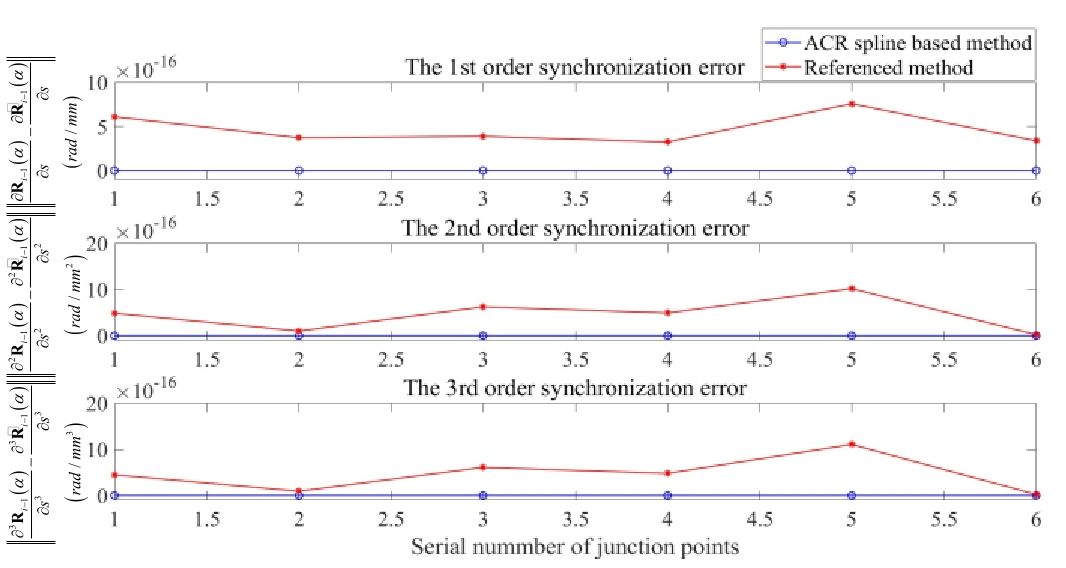
Fig. 11.
Synchronization errors of the tool orientation with respect to the tool tip displacement with εp = 0.8mm and ε0 = 0.01rad
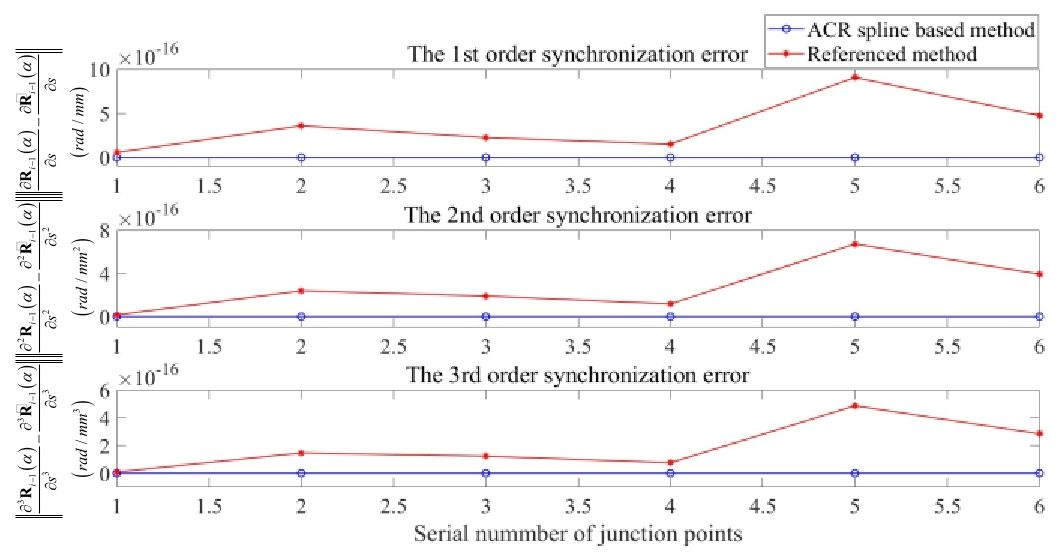
Fig. 12.
Synchronization errors of the tool orientation with respect to the tool tip displacement with εp = 1.2mm andε0 = 0.005 rad
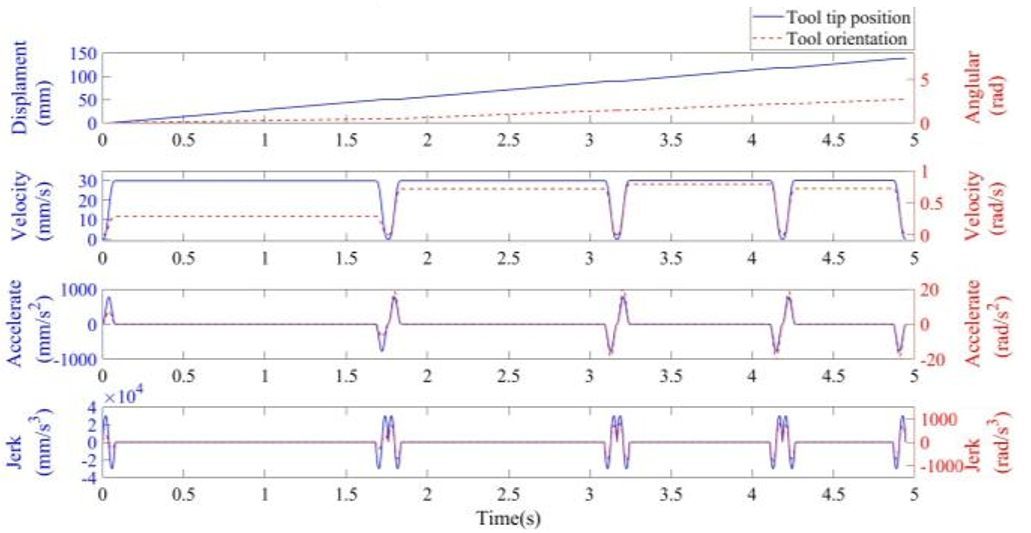
Fig. 13.
Kinematic profile after interpolation
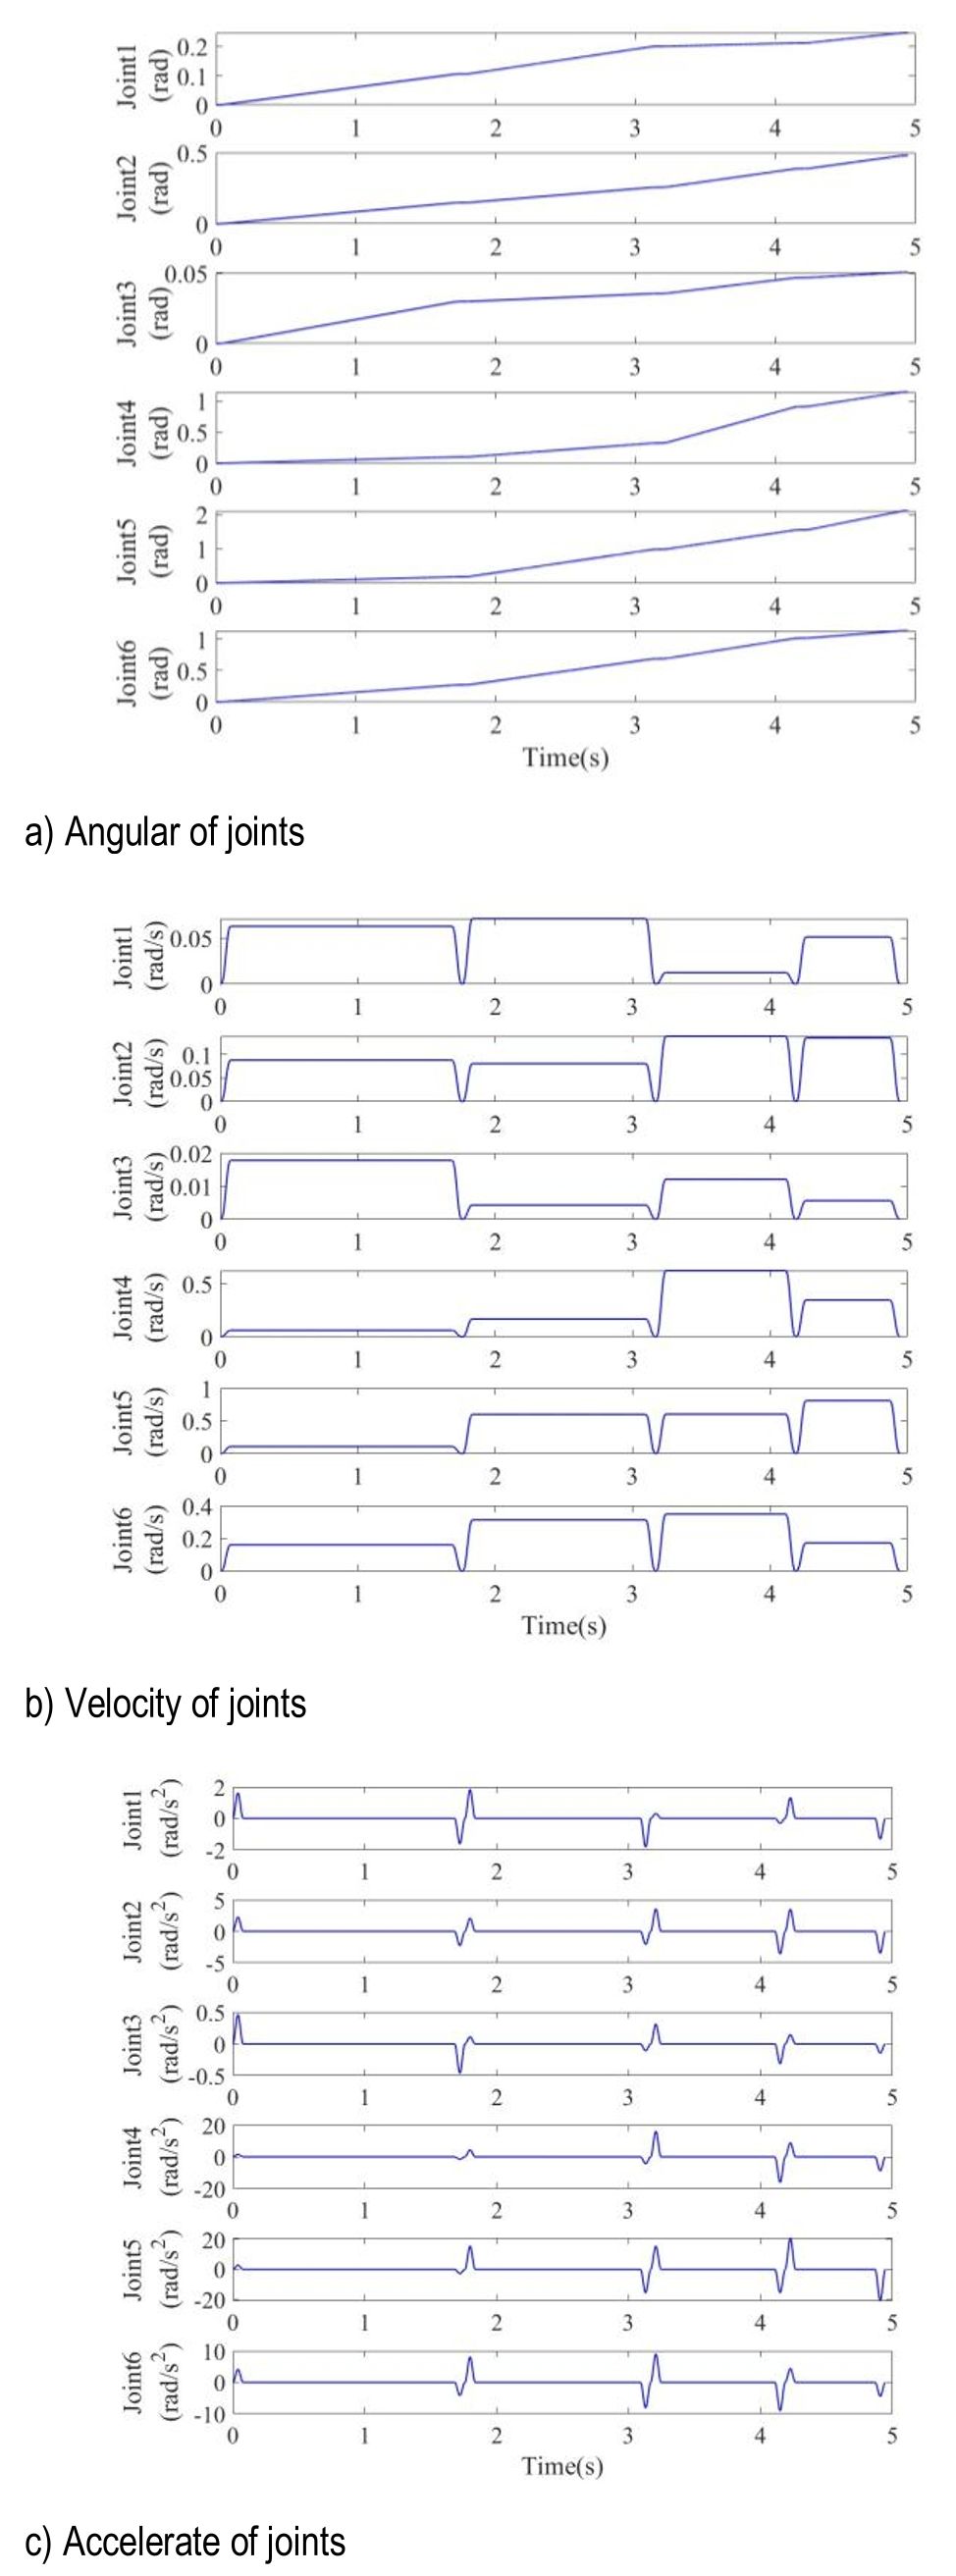
Fig. 14.
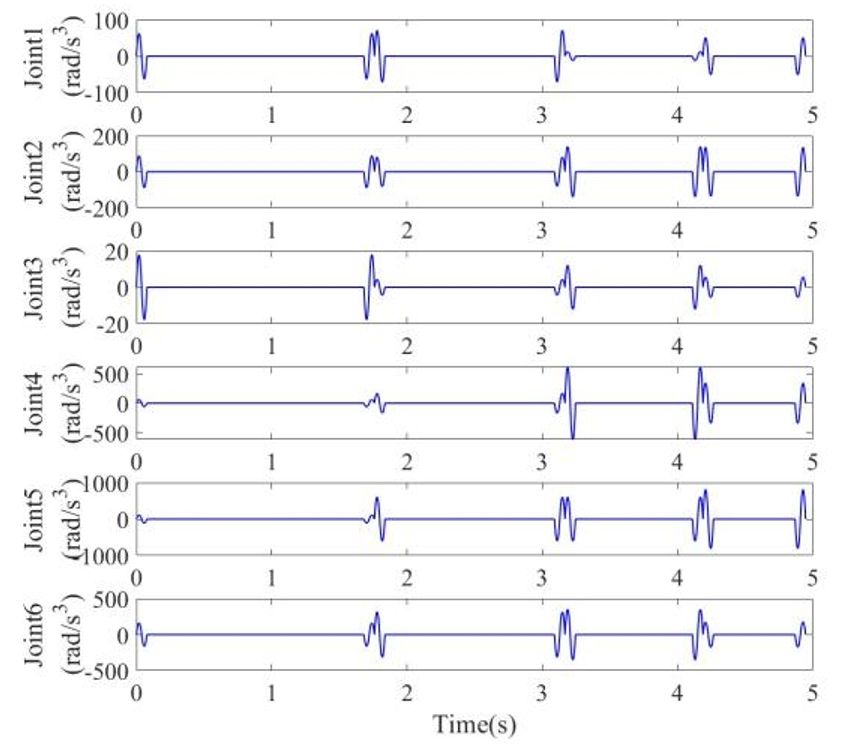
Kinematic profiles of each joint of robot