

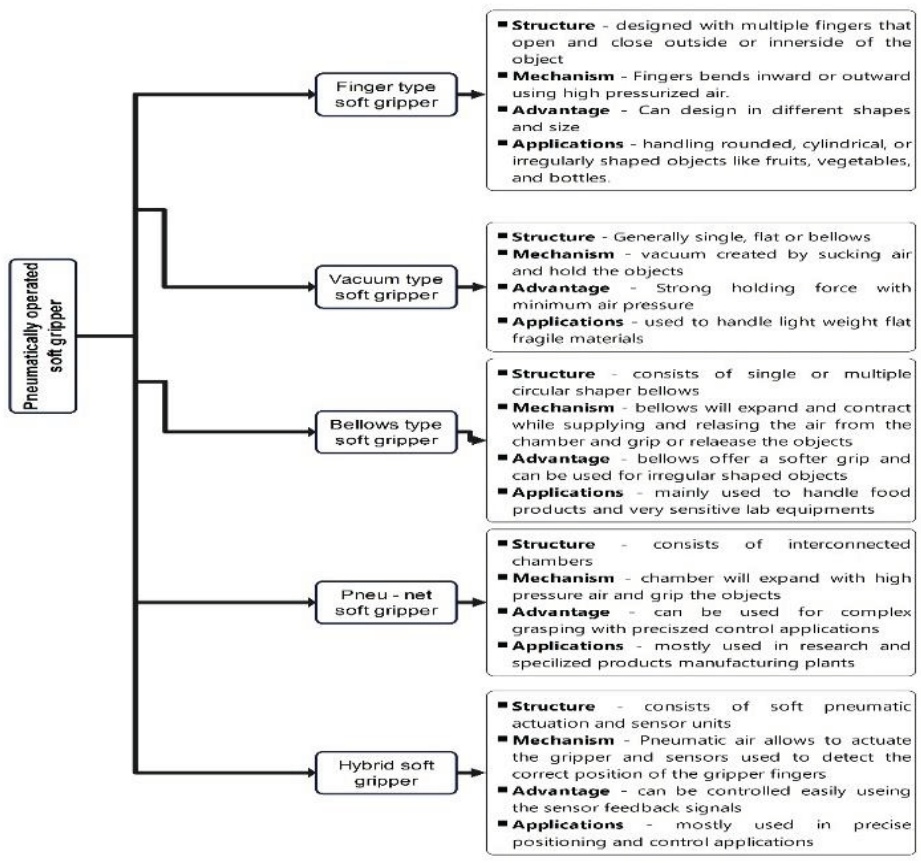
Figure 1.
Details of different types of soft gripper
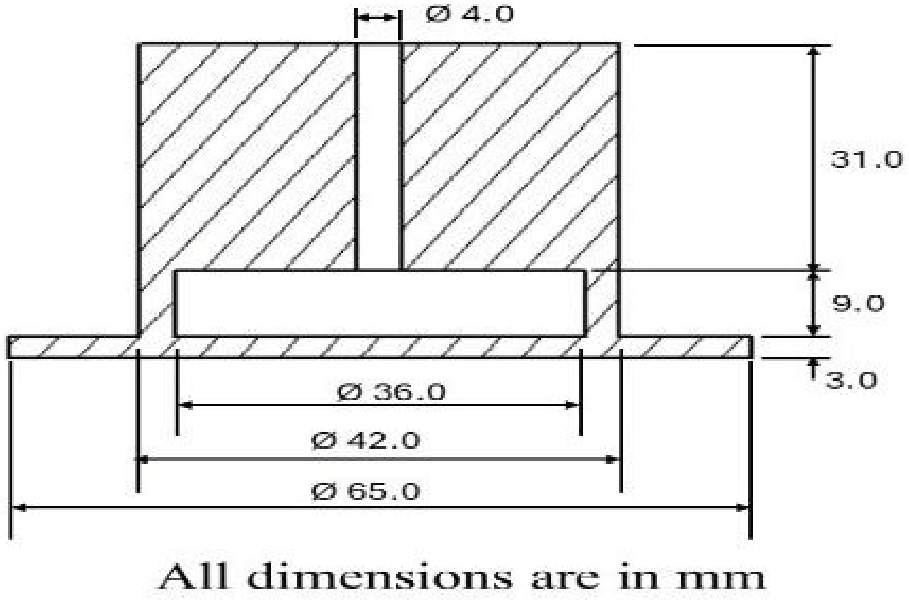
Figure 2.
Measurements of this study’s soft gripper
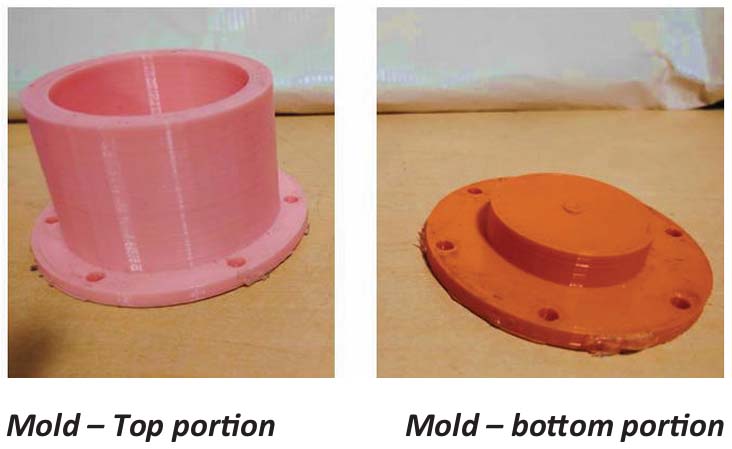
Figure 3.
Pictorial views of the top and bottom portions of the fabricated 3D-printed mold
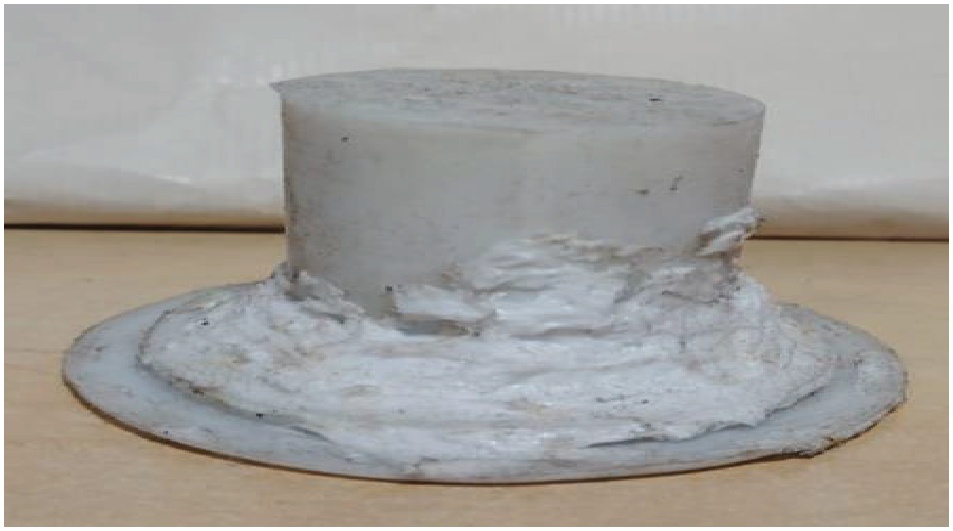
Figure 4.
Fabricated vacuum-actuated soft gripper
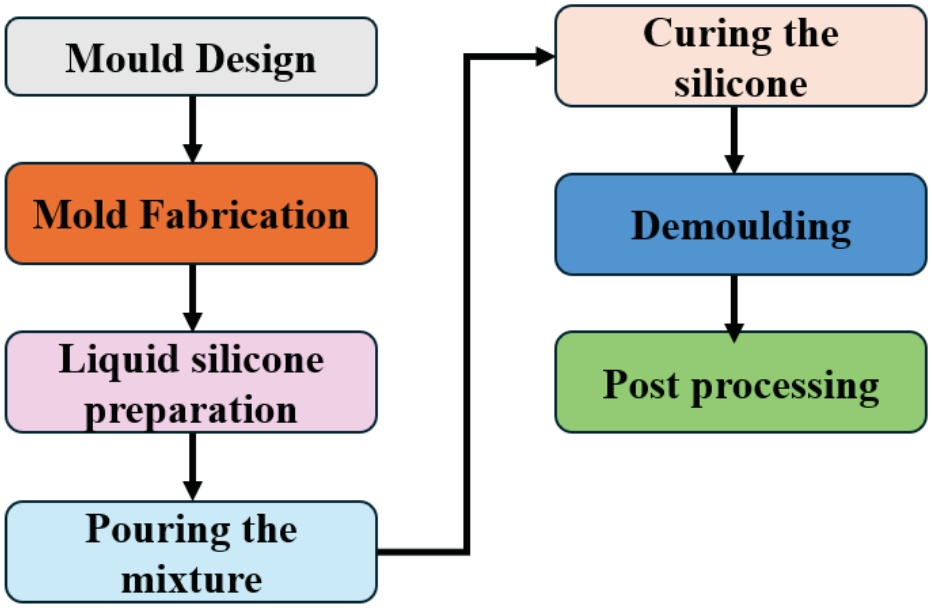
Figure 5.
Step-by-step procedure adopted to fabricate the soft gripper
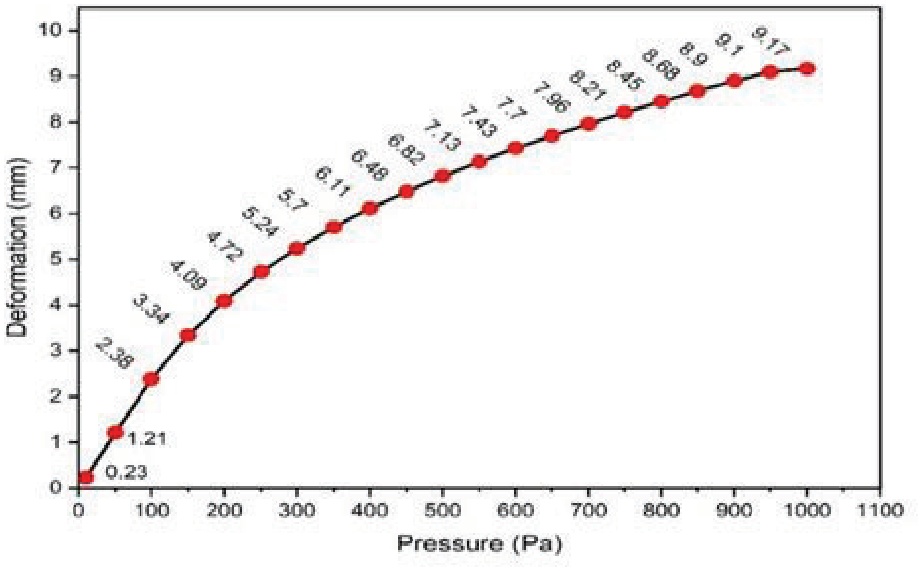
Figure 6.
Variations of deflection of the soft gripper surface with respect to pressure
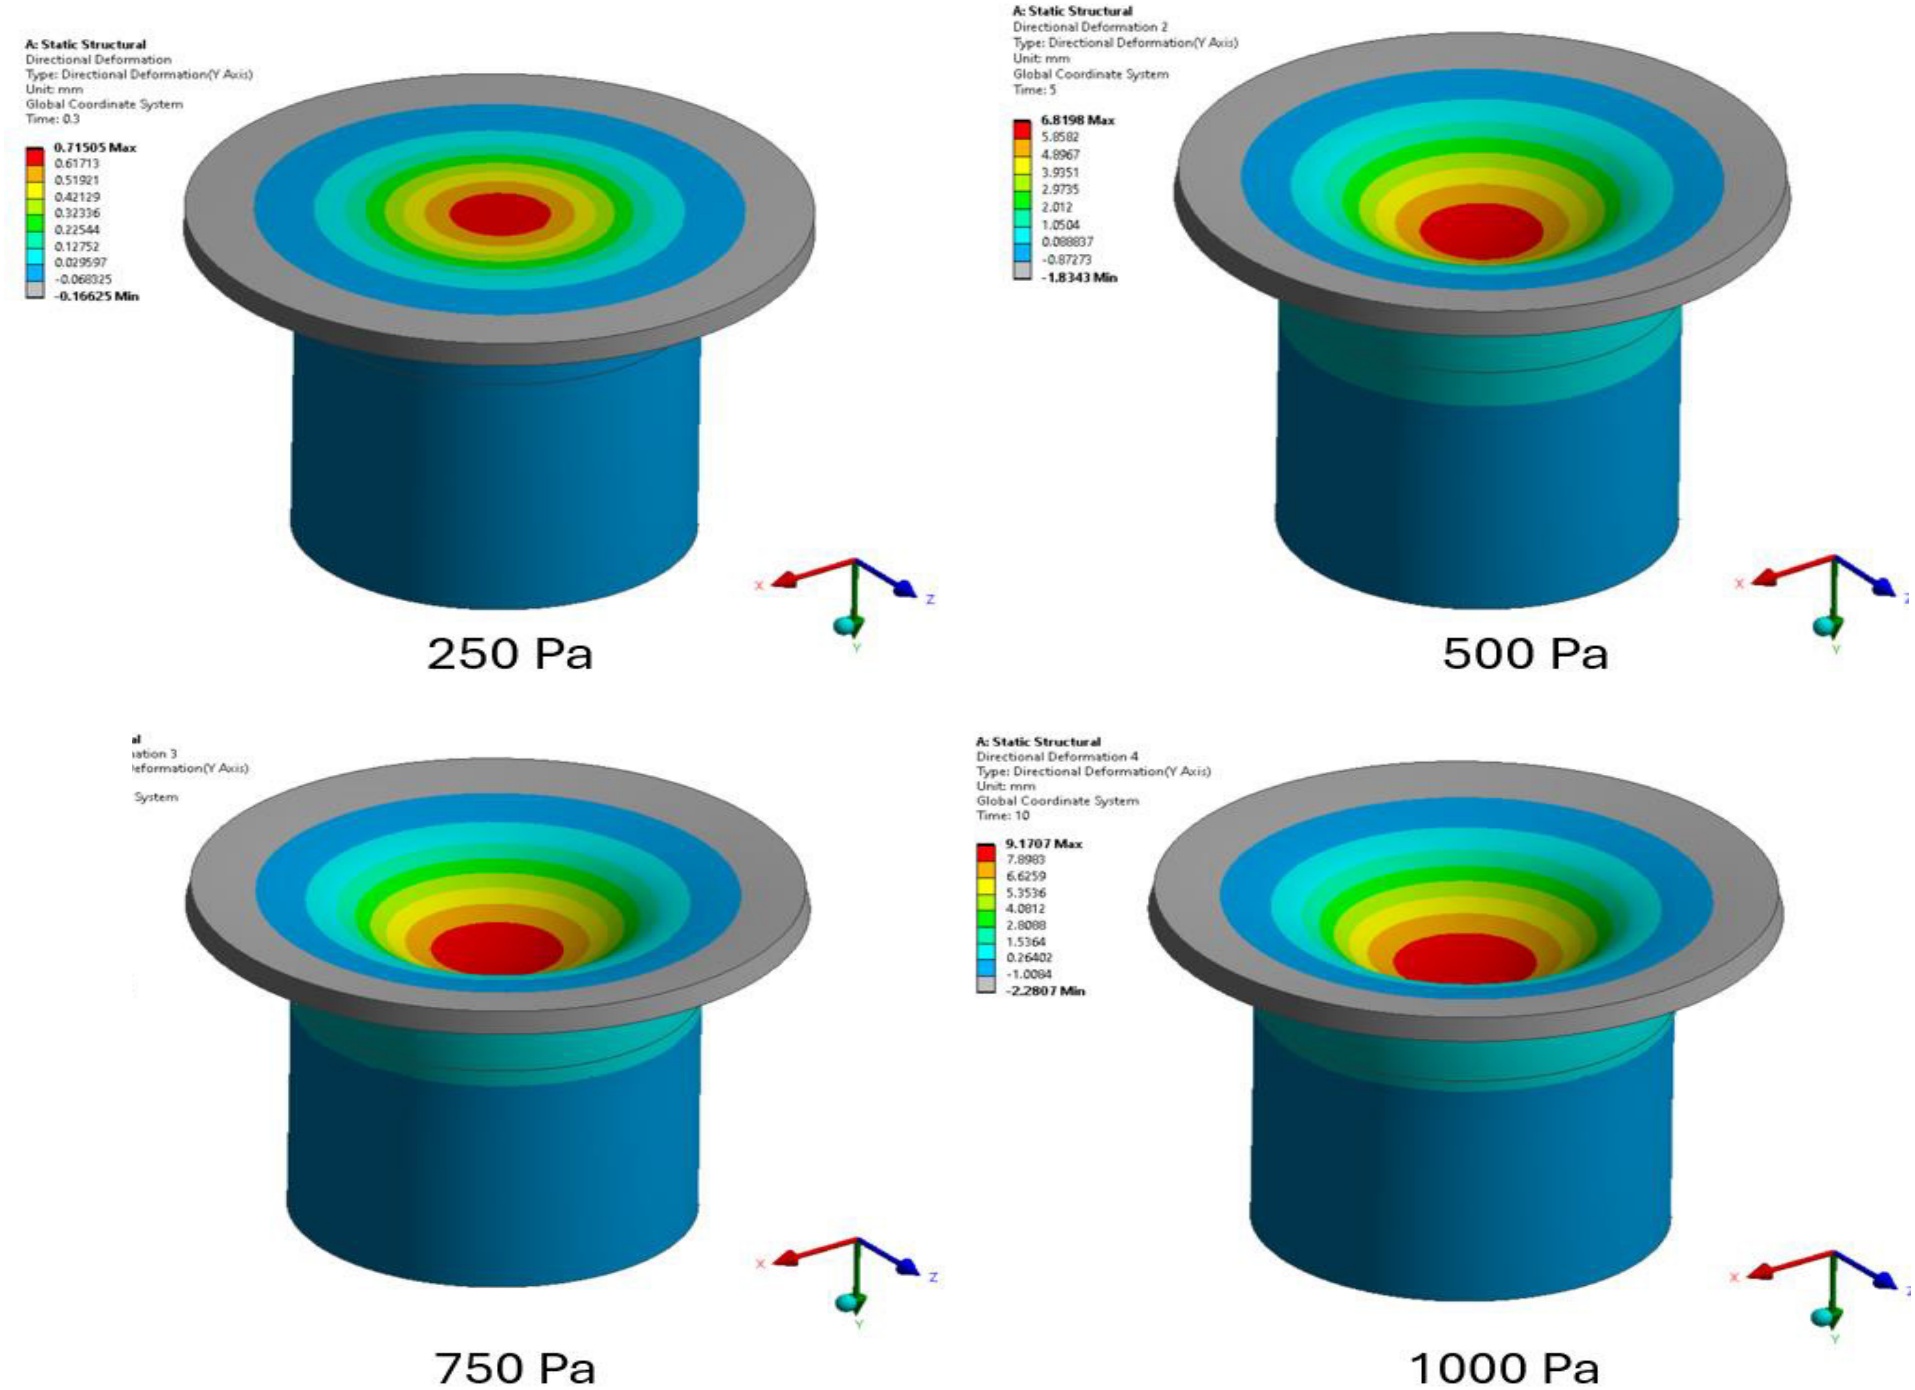
Figure 7.
The variations of deflection of the finite element model at 250Pa, 500Pa, 750 Pa and 1000 Pa
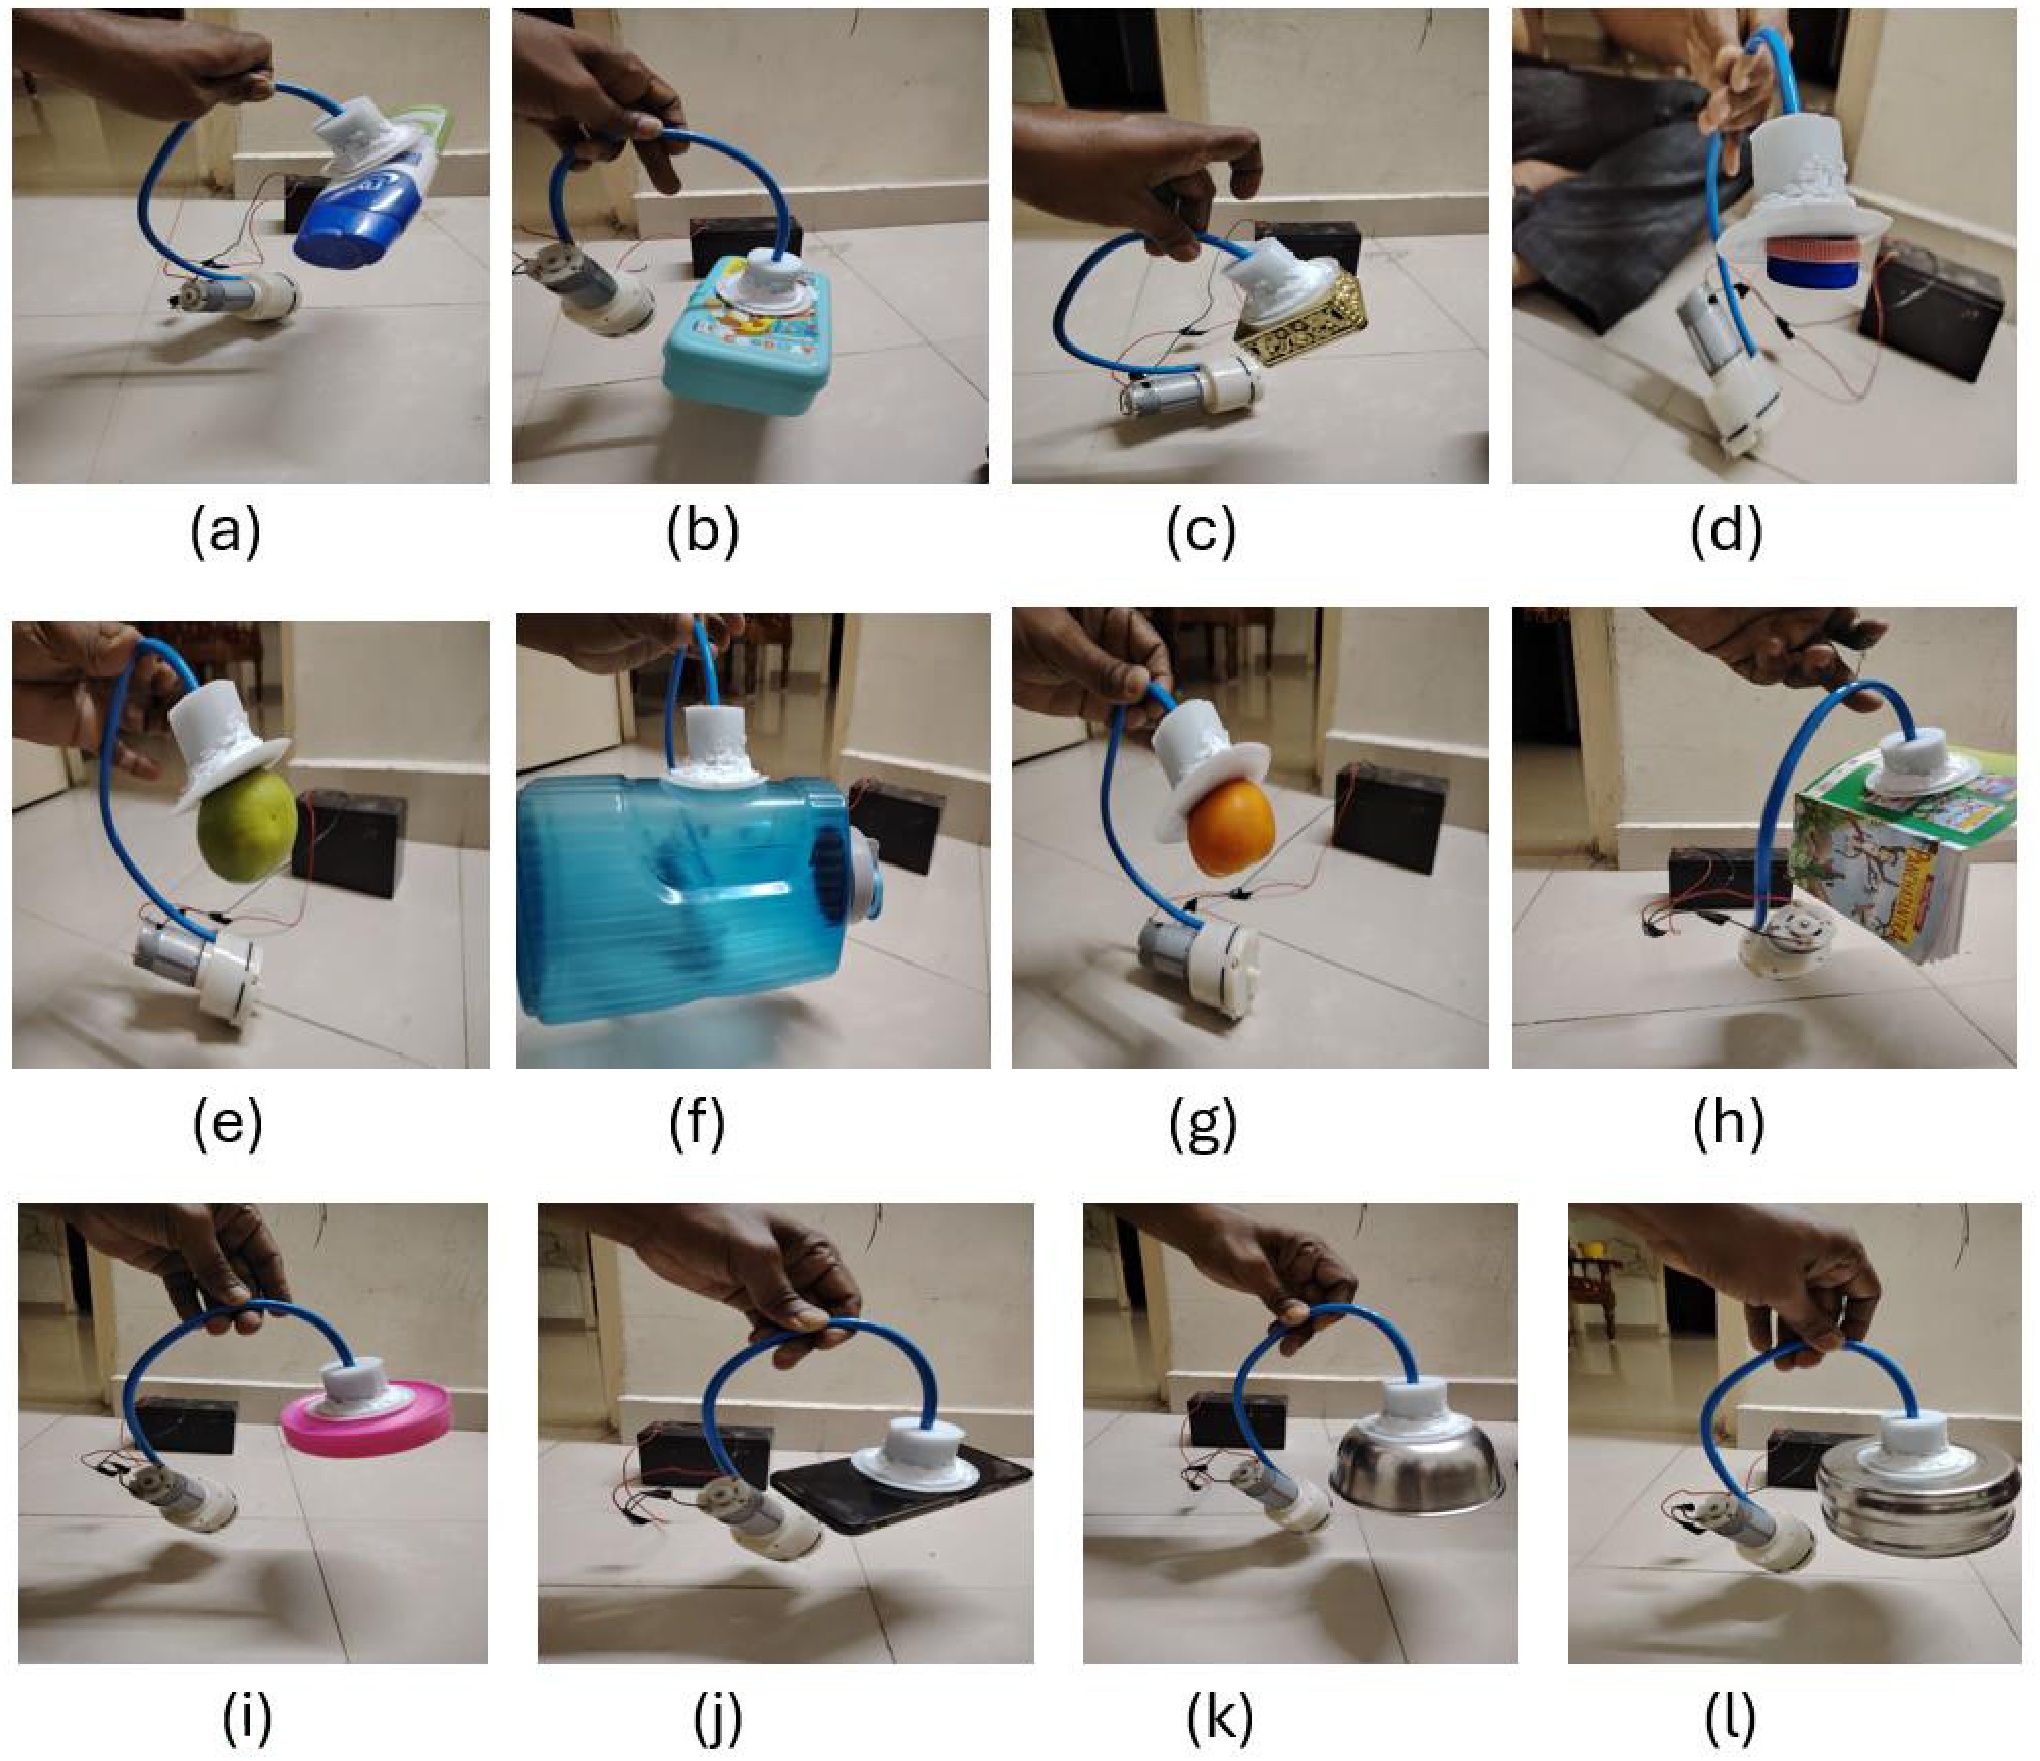
Figure 8.
Applications of the proposed vacuum soft gripper: (a) Grasping plastic bottle; (b) Grasping rectangular plastic box; (c) Grasping jewelry box; (d) Grasping medicine bottle; (e) Grasping mosambi fruit; (f) Graspin empty water bottle; (g) Grasping orange; (h) Grasping book; (i) Grasping plastic bottle cap; (j) Grasping mobile phone; (k) Grasping stainless steel cup; (l) Grasping stainless steel tiffin box