
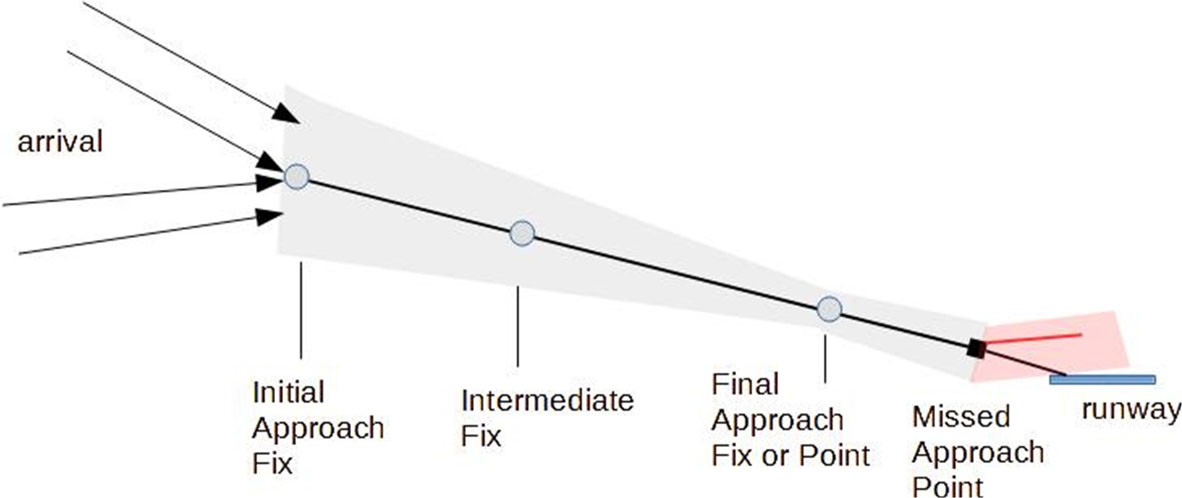
Fig. 1.
Standard fixed wing aircraft approach
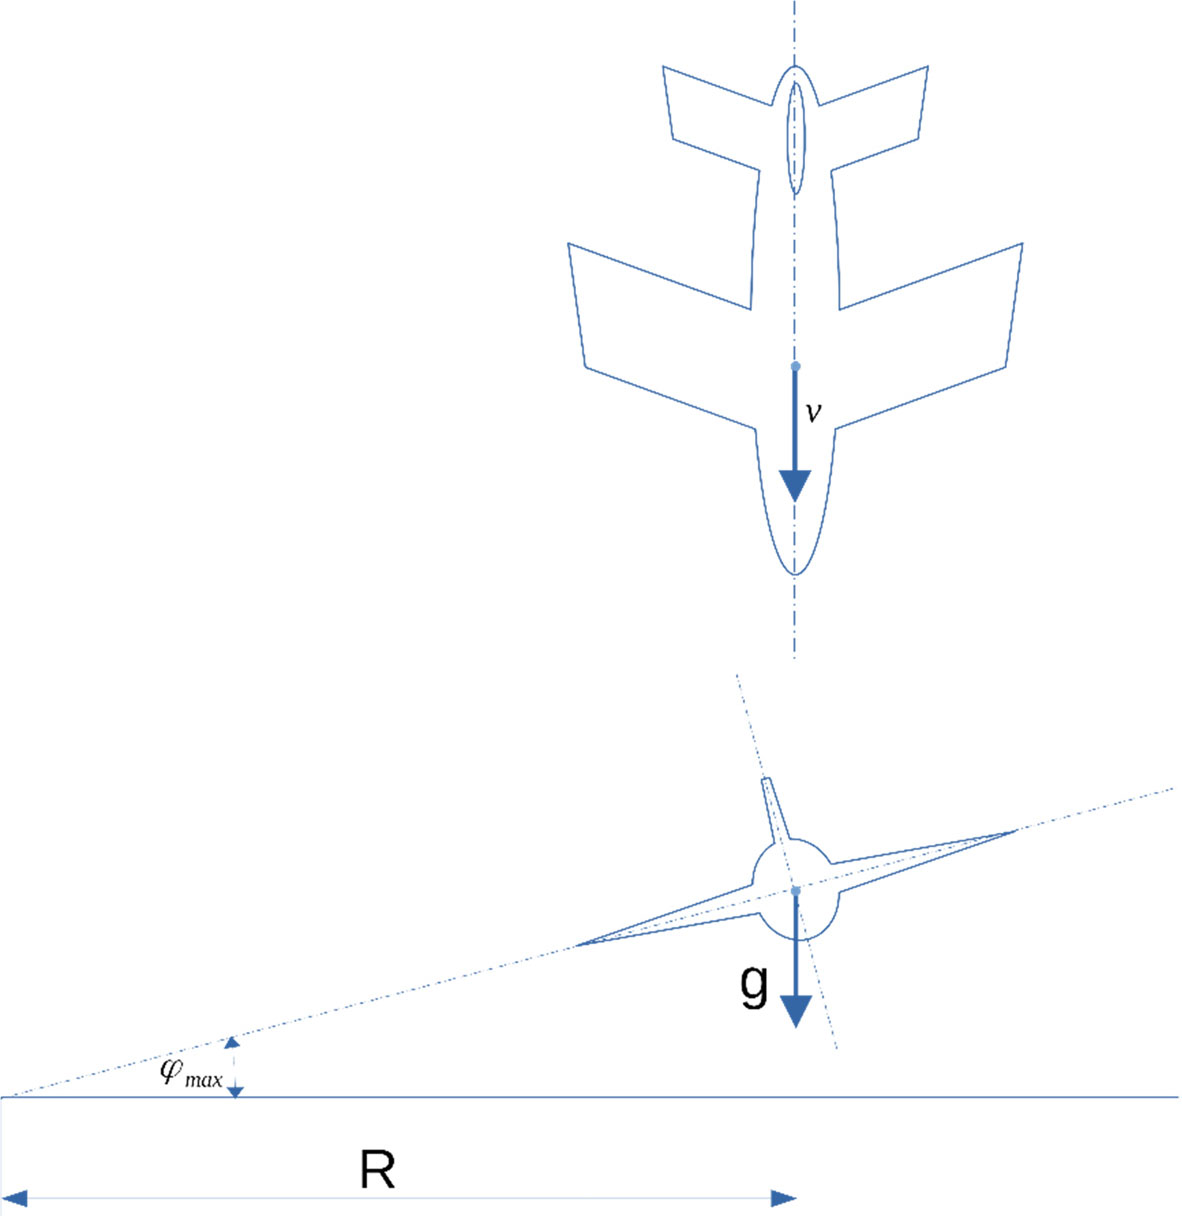
Fig. 2.
Airplane in a steady-state turn
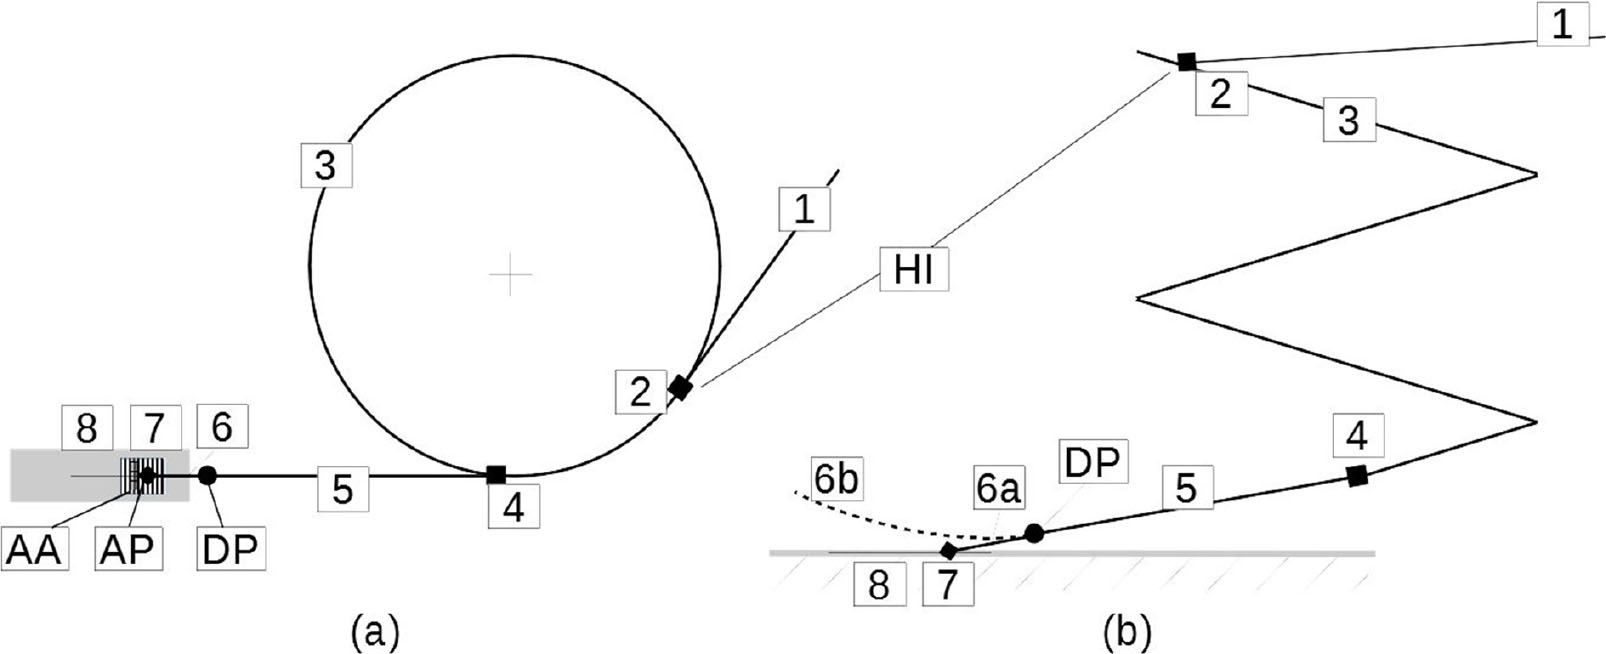
Fig. 3.
Landing phases (A) top view, (B) side view. AA, aiming area; AP, aiming point; DP, decision point.
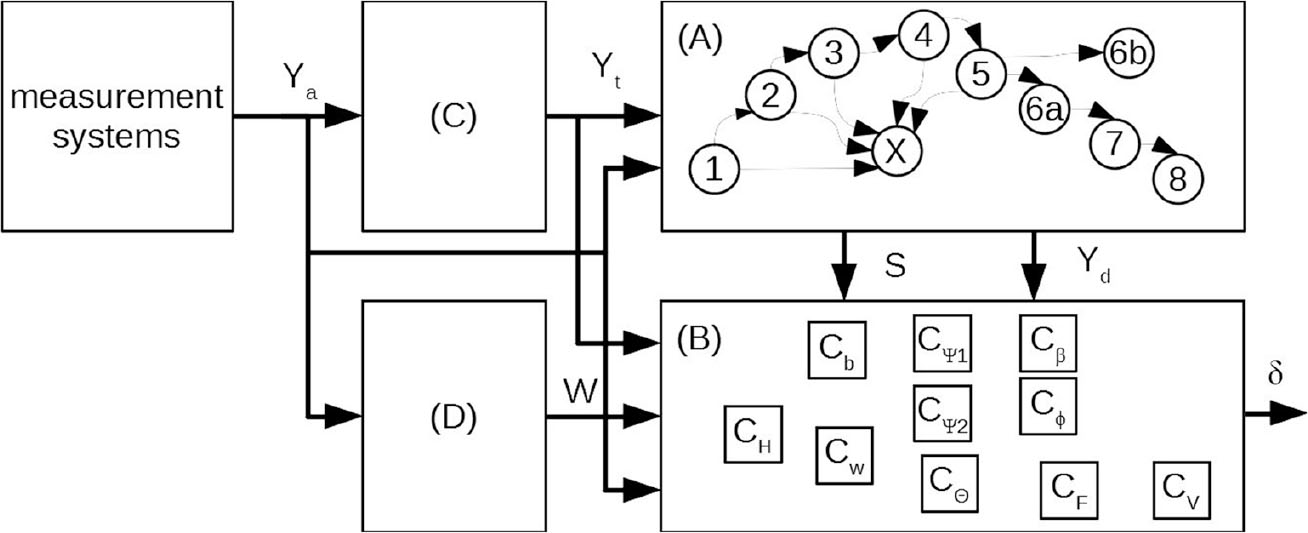
Fig. 4.
General structure of the aircraft landing control system
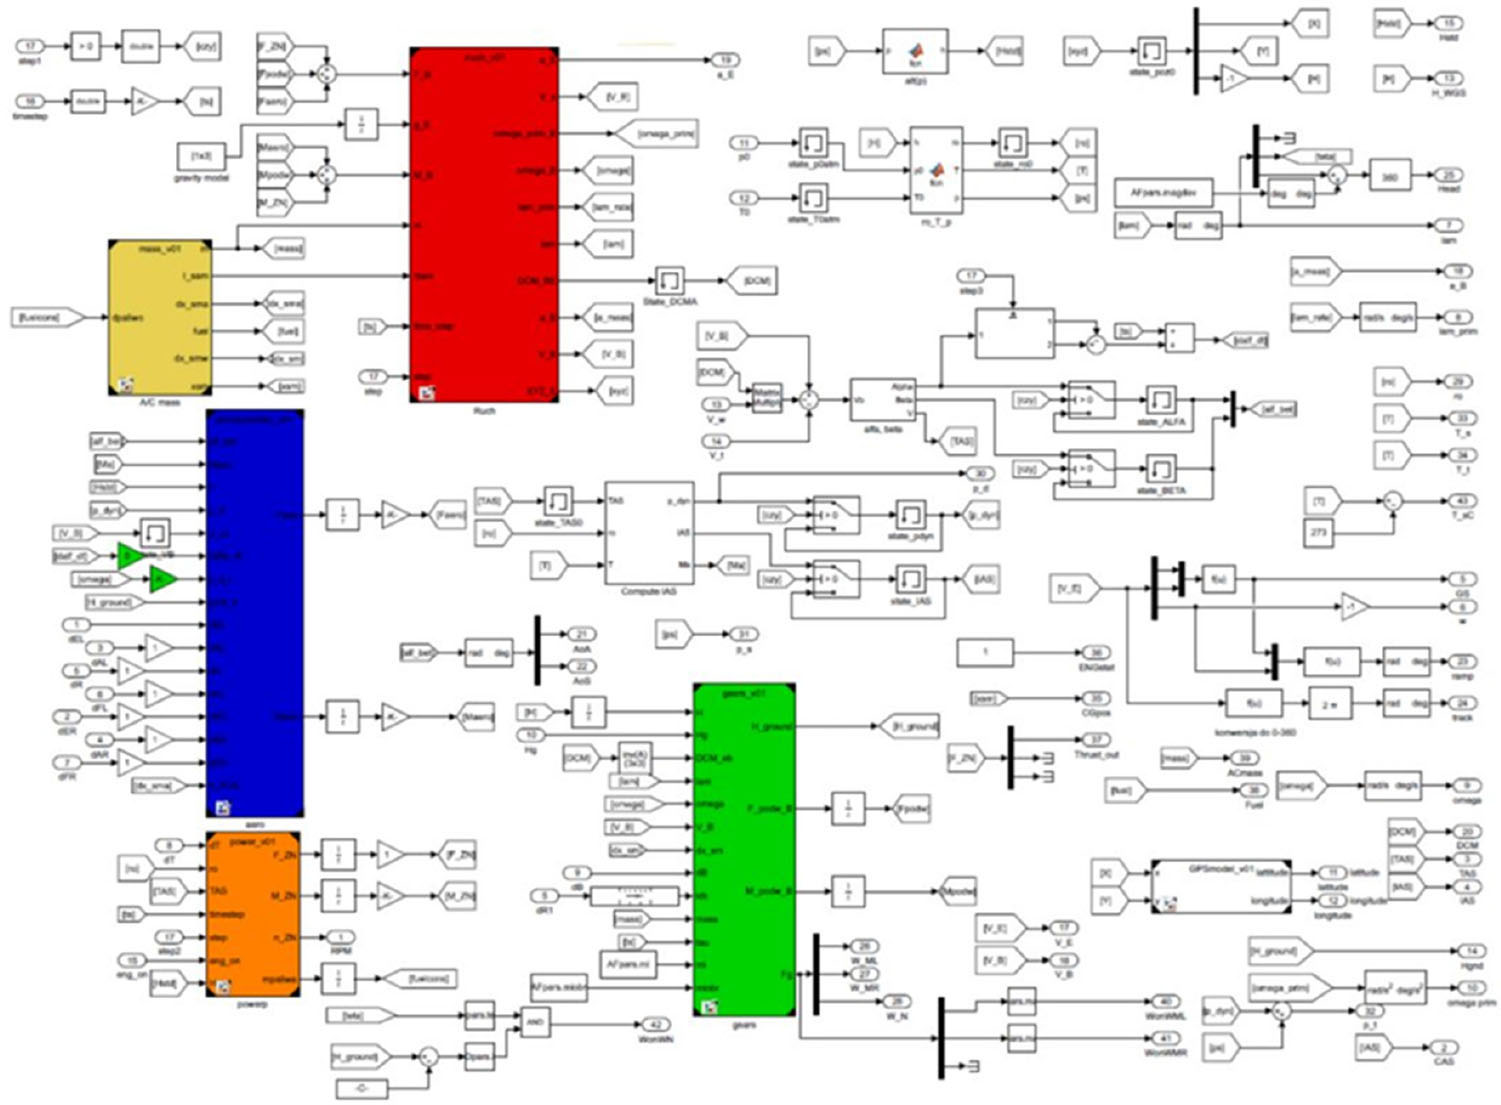
Fig. 5.
The image of the aircraft model of motion realised in Simulink.
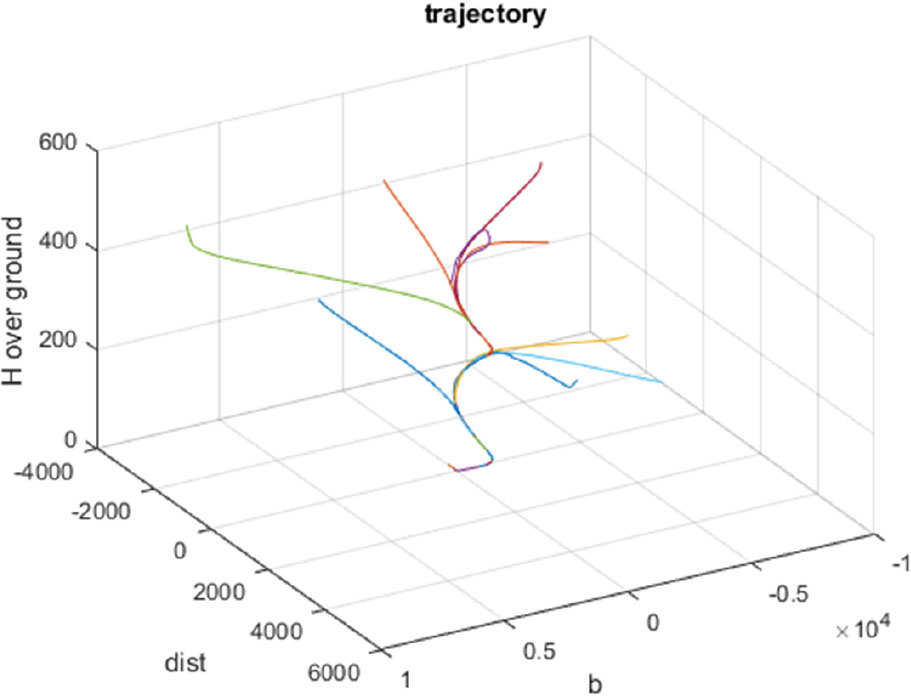
Fig. 6.
Approach trajectory with different initial states.
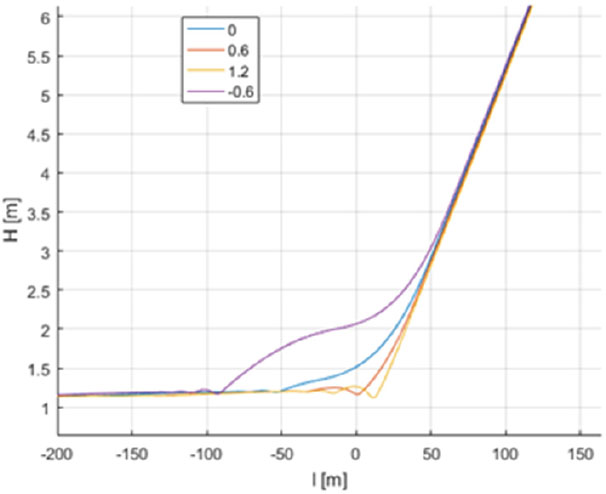
Fig. 7.
Aircraft CG height during landing (0 – proper flare, 0.6, 1.2 – delayed flare initialisation, height deviation 0.6 m and 1.2 m appropriately, -0.6 – too early flare initialisation, height deviation −0.6 m). CG, centre of gravity.
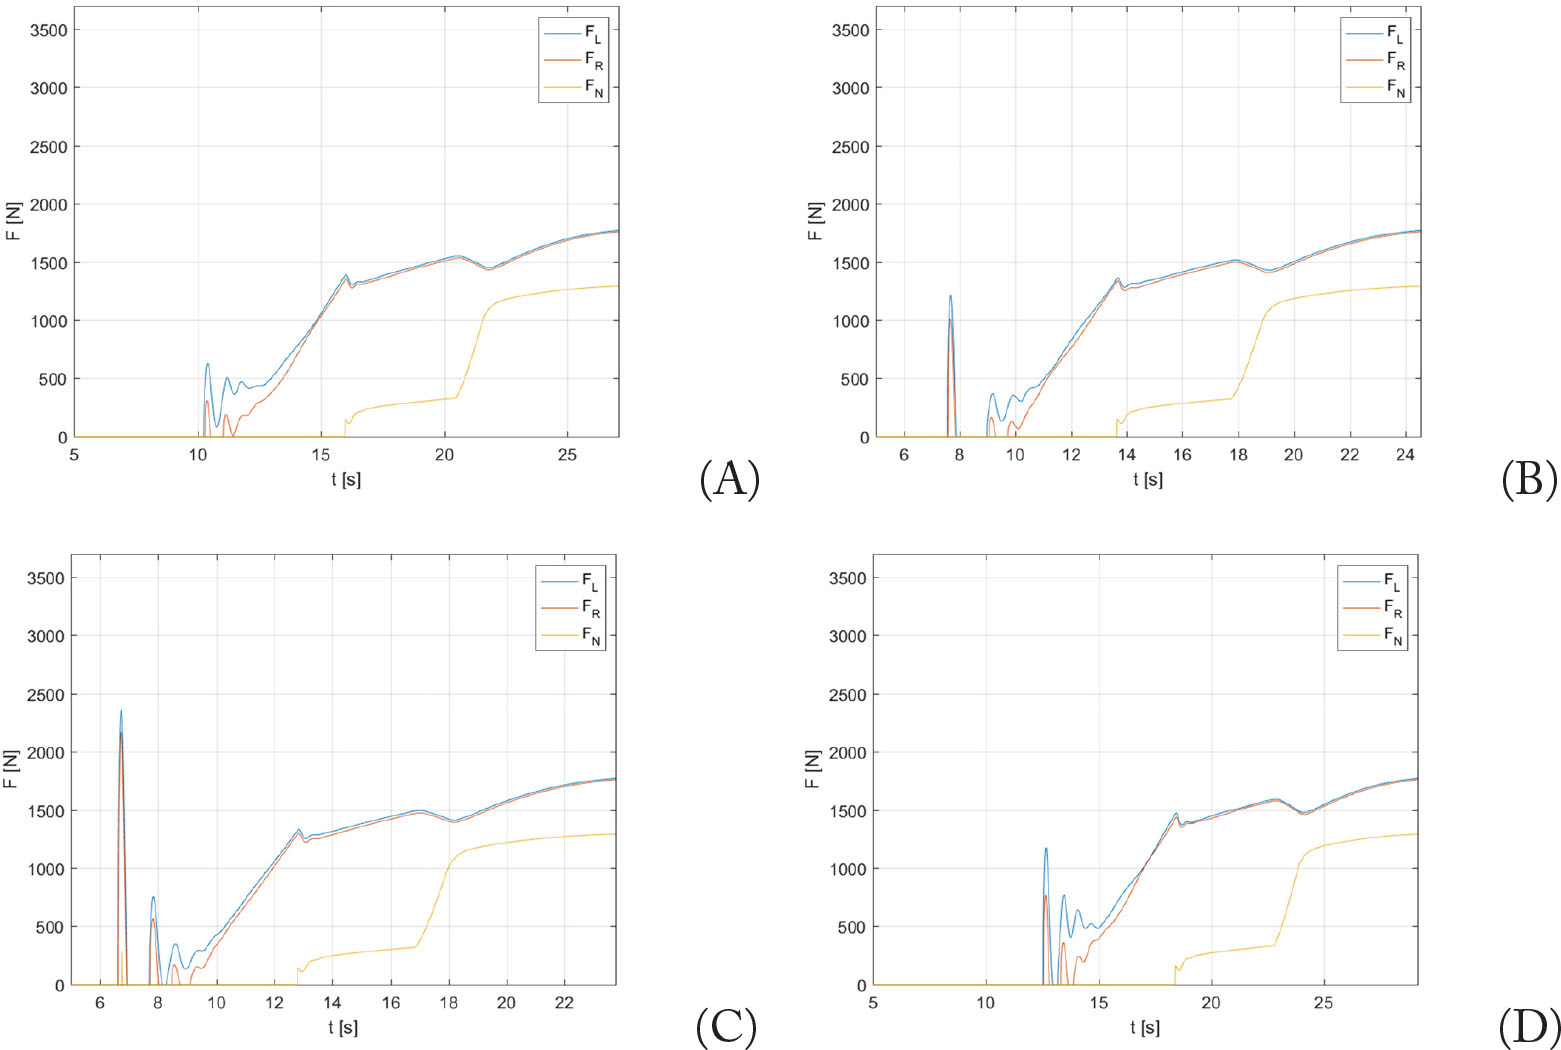
Fig. 8.
Wheel normal forces during landing (A) proper flare, (B) delayed flare (0.6 m), (C) delayed flare (1.2 m), (D) early flare (-0.6 m).
Table 1:
Test cases.
| Test case | Side wind [m/s] | Head wind [m/s] | Wind estimator | Comment | |
|---|---|---|---|---|---|
| (0, 0) | No | No | Yes | Active but unnecessary | |
| (0, 7) | 7 | 0 | Yes | ||
| (0,−7) | −7 | 0 | Yes | ||
| (7, 0) | 0 | 7 | Yes | Head wind decrease GS on approach last segment | |
| (−5,0) | 0 | −5 | Yes | Back wind increases GS on approach last segment | |
| (0, 7*) | 7 | 0 | No | Inactive wind estimator causes no prediction of wind effect in control algorithm | |
| (0, −7*) | −7 | 0 | No | ||
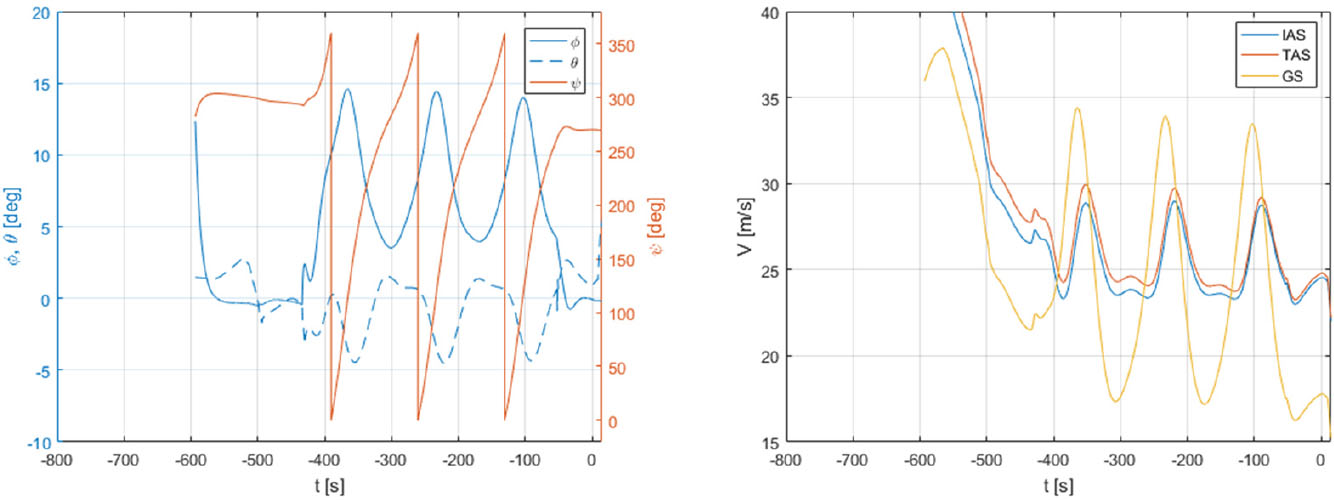
Fig. 9.
Aircraft attitude (left) and velocity (right): case (7, 0).
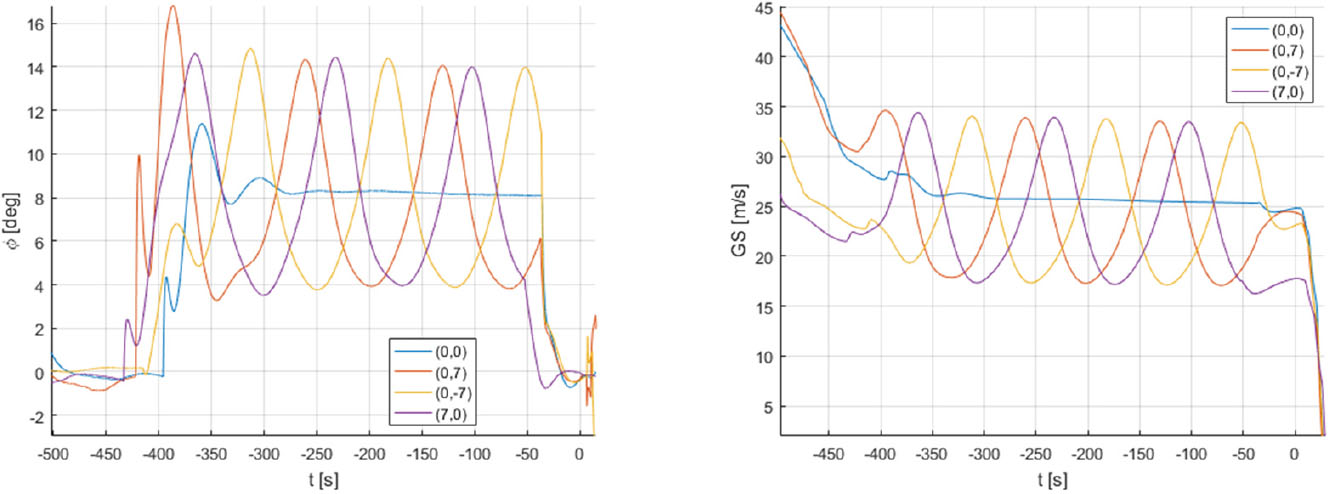
Fig. 10.
Aircraft bank angle (left) and ground velocity (right): cases as in Table 1 comparison.
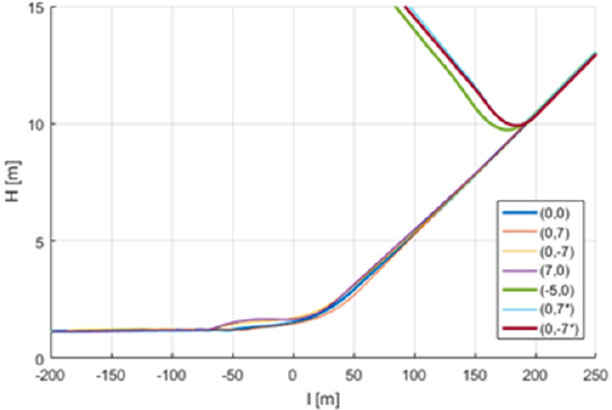
Fig. 11.
Aircraft CG height during landing (condition as in Table 1). CG, centre of gravity.
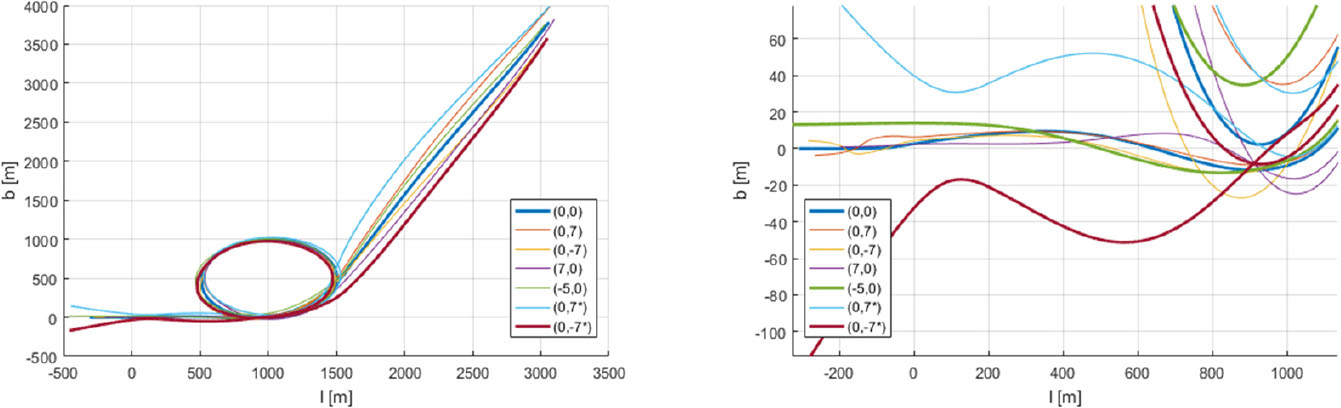
Fig. 12.
Horizontal view of the aircraft trajectories.
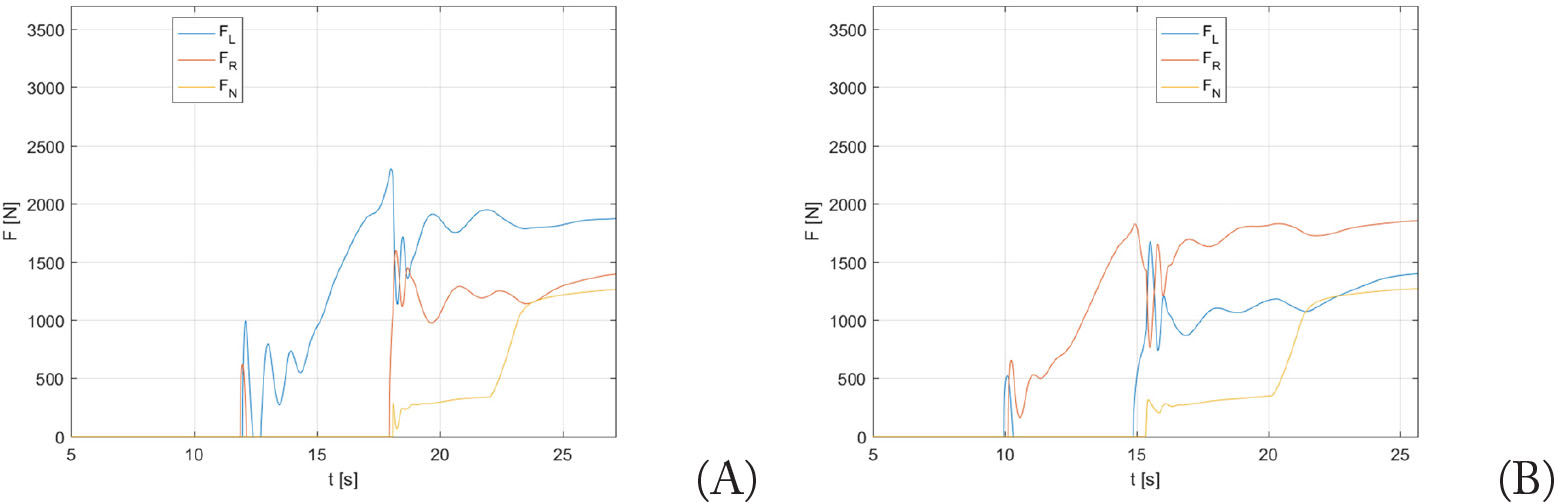
Fig. 13.
Wheel normal forces during landing with side wind. (A) – right side wind, (B) – left side wind
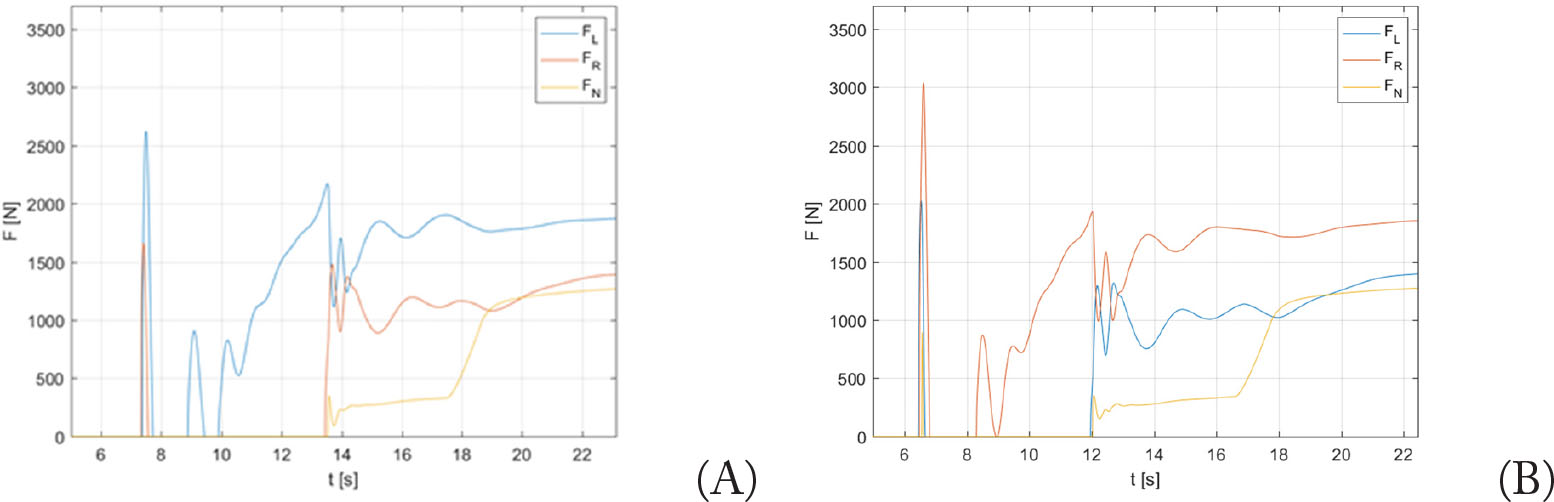
Fig. 14.
Wheel normal forces during landing with side wind with delayed flare.
(A) – right side wind, (B) – left side wind