

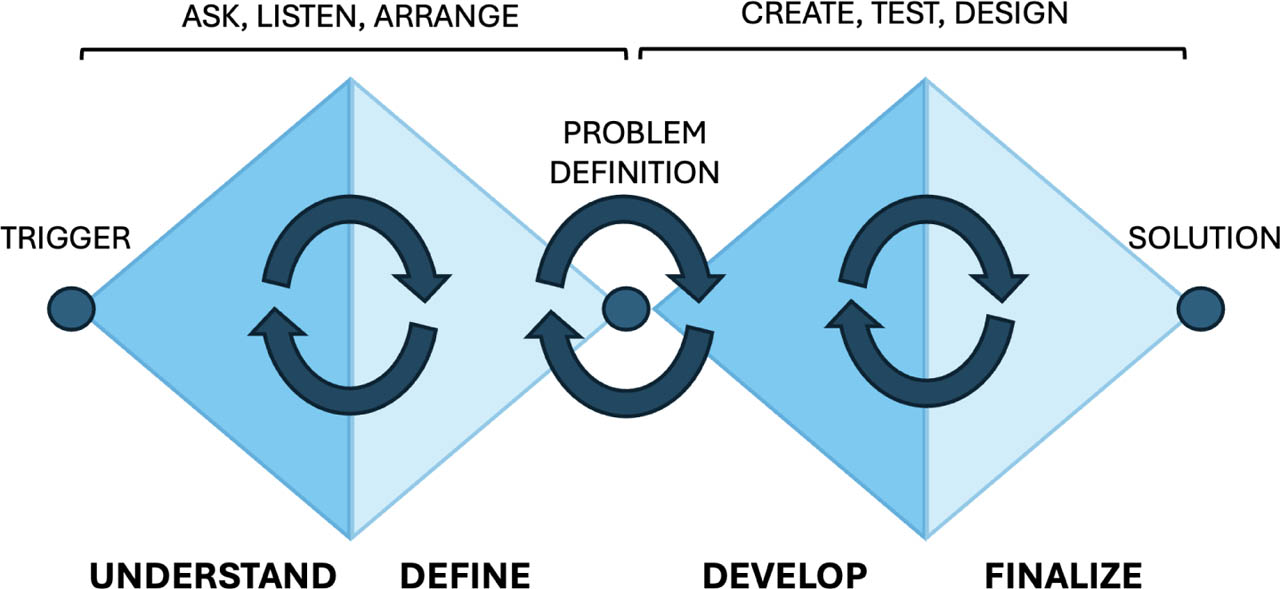
Figure 1:
Double Diamond Model
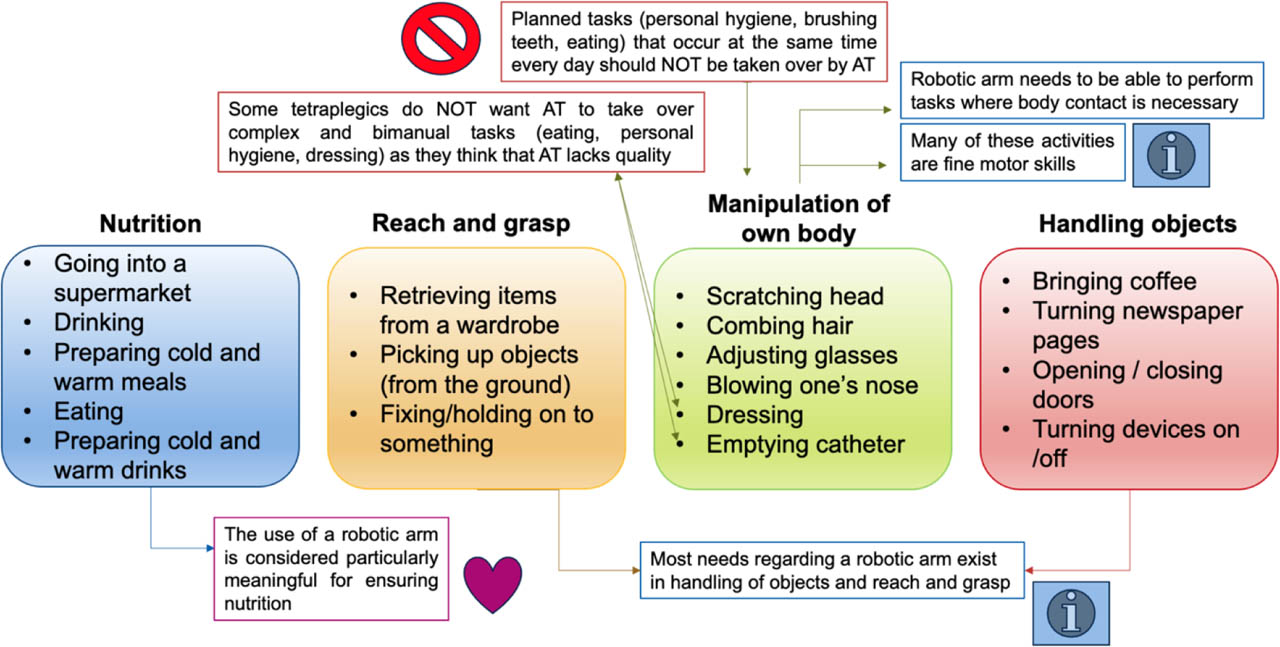
Figure 2:
Needs of individuals with tetraplegia
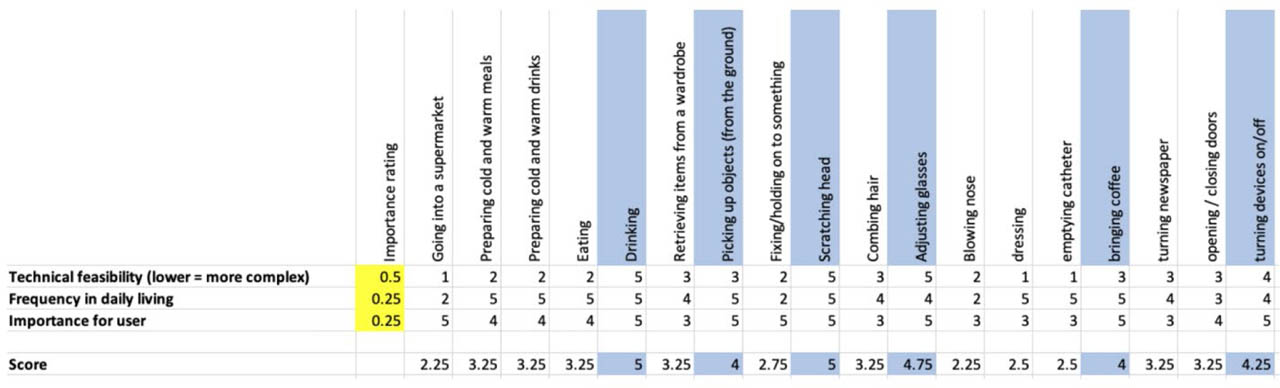
Figure 3:
ADL (Activities of Daily Living) assessment matrix analysis revealing which tasks are most relevant for integration into the robotic arm system, based on user preferences and technical considerations
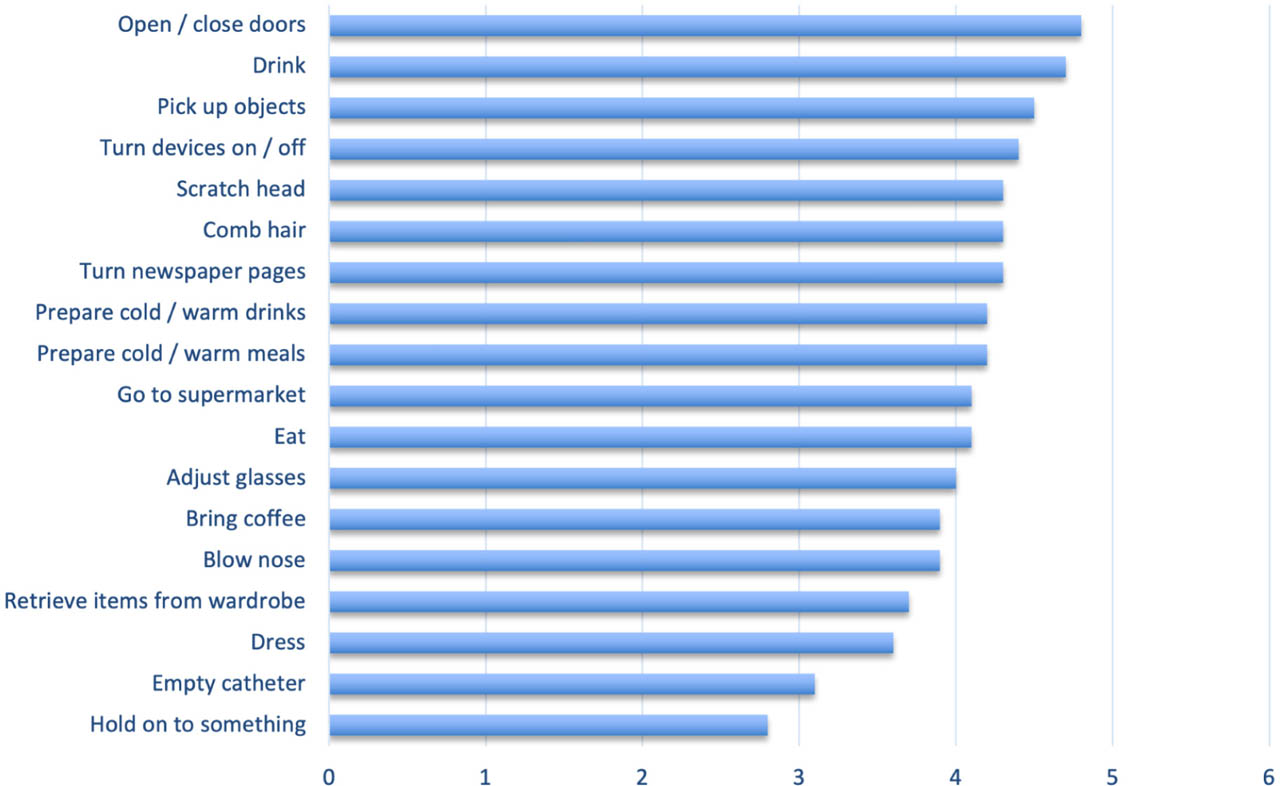
Figure 4:
Average importance of ADL (Activities of Daily Living) for individuals with tetraplegia from 0 (not important) to 6 (very important)
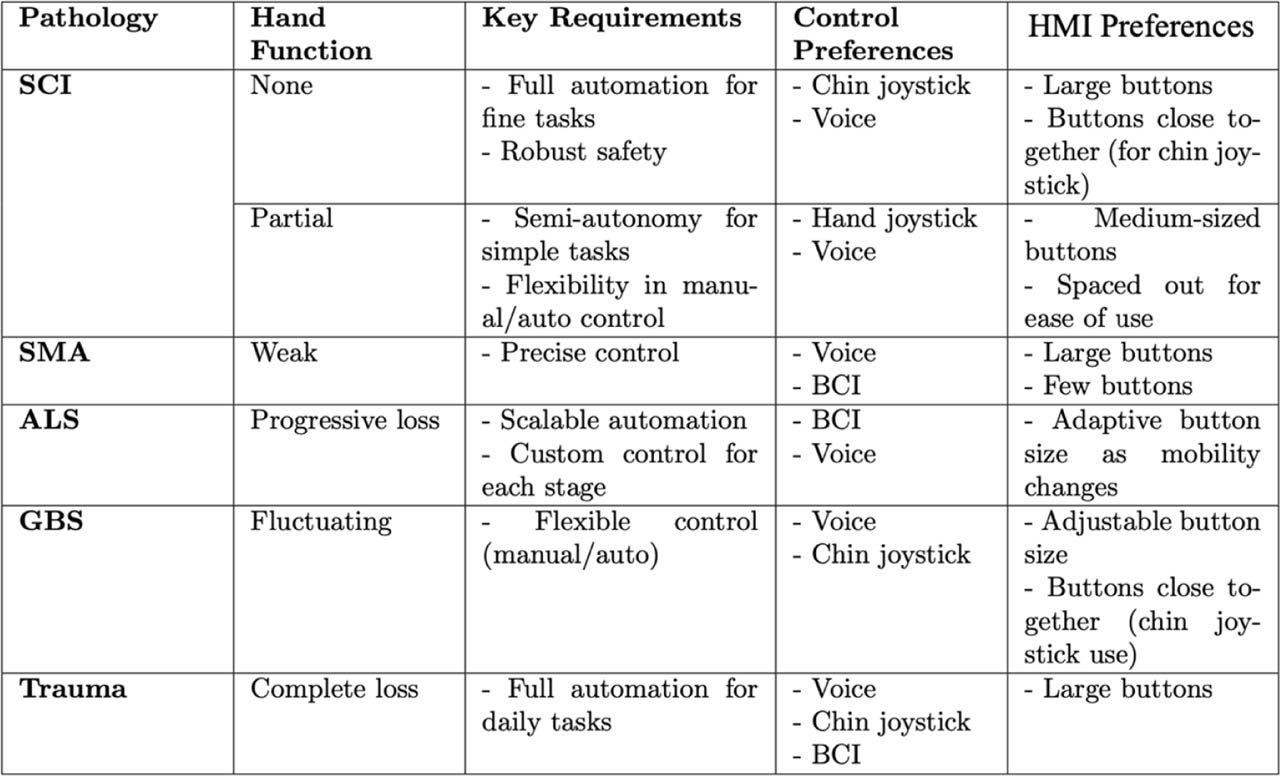
Figure 5:
Different HMI (Human-Machine Interface) designs depending on pathology. Abbreviations: Spinal Cord Injury (SCI), Spinal Muscular Atrophy (SMA), Amyotrophic Lateral Sclerosis (ALS), Guillain-Barré Syndrome (GBS), Brain Computer Interface (BCI)
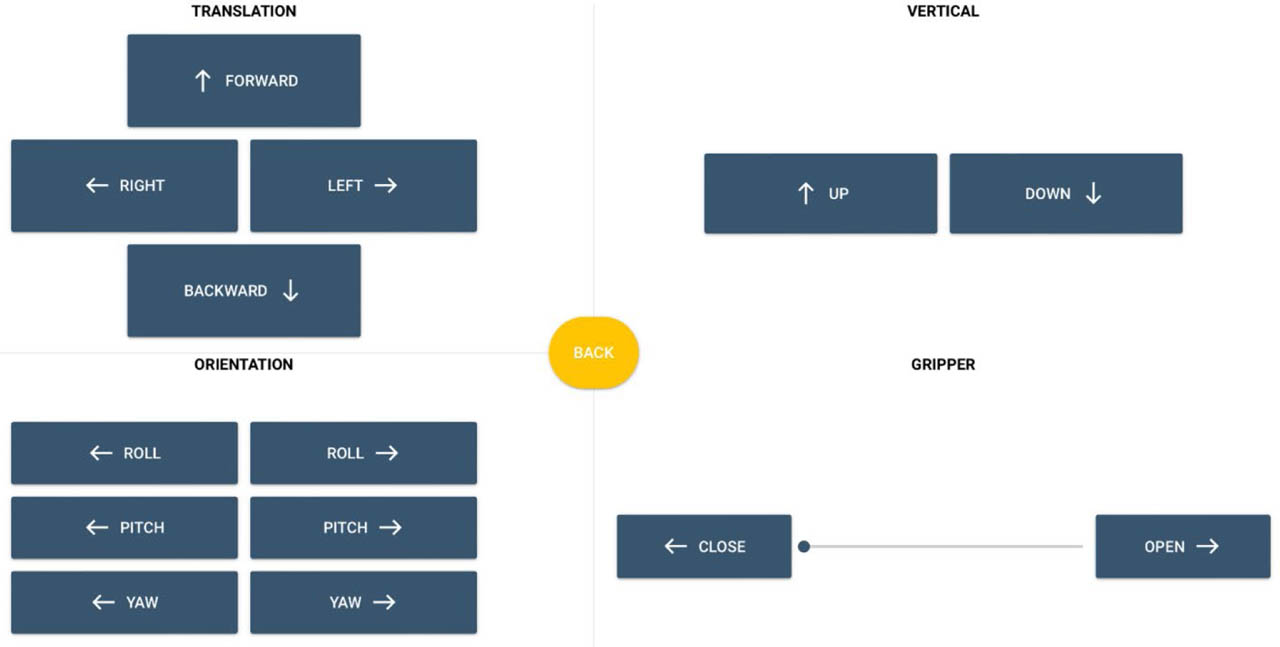
Figure 6:
Standard GUI (Graphical User Interface) Layout
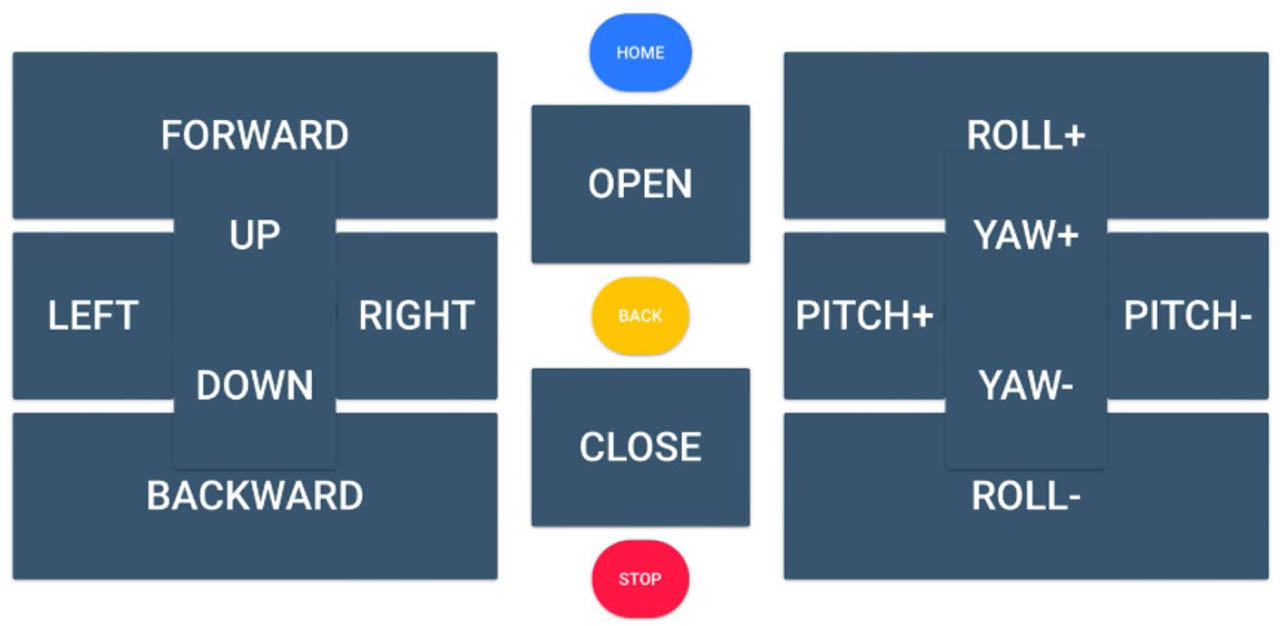
Figure 7:
Large Button GUI (Graphical User Interface) Layout
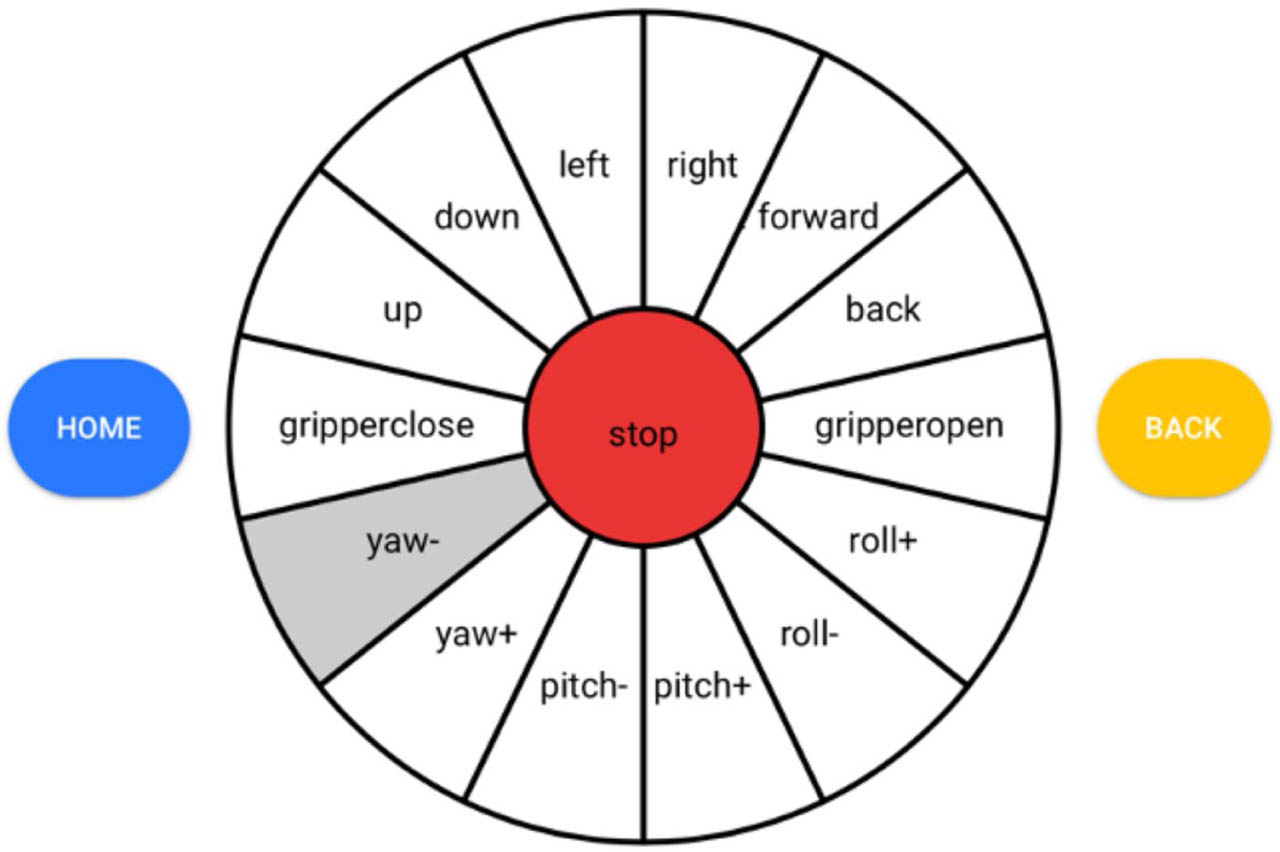
Figure 8:
Compact GUI (Graphical User Interface) Layout
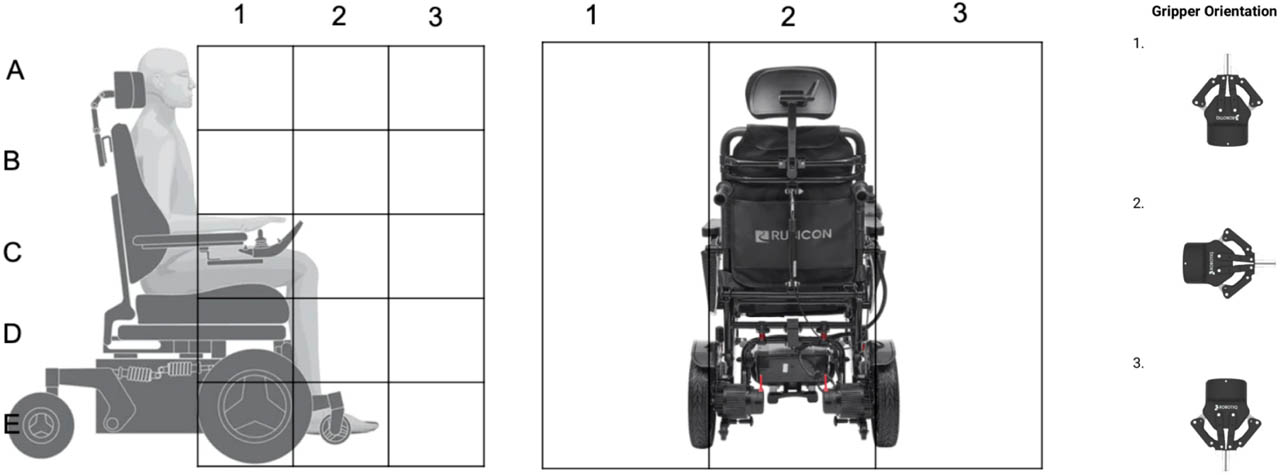
Figure 9:
Fast navigation three-step GUI. Left: First step, choose a position that the robotic arm should reach. Center: Second step, choose the lateral position to be reached. Right: Third step, choose the gripper orientation
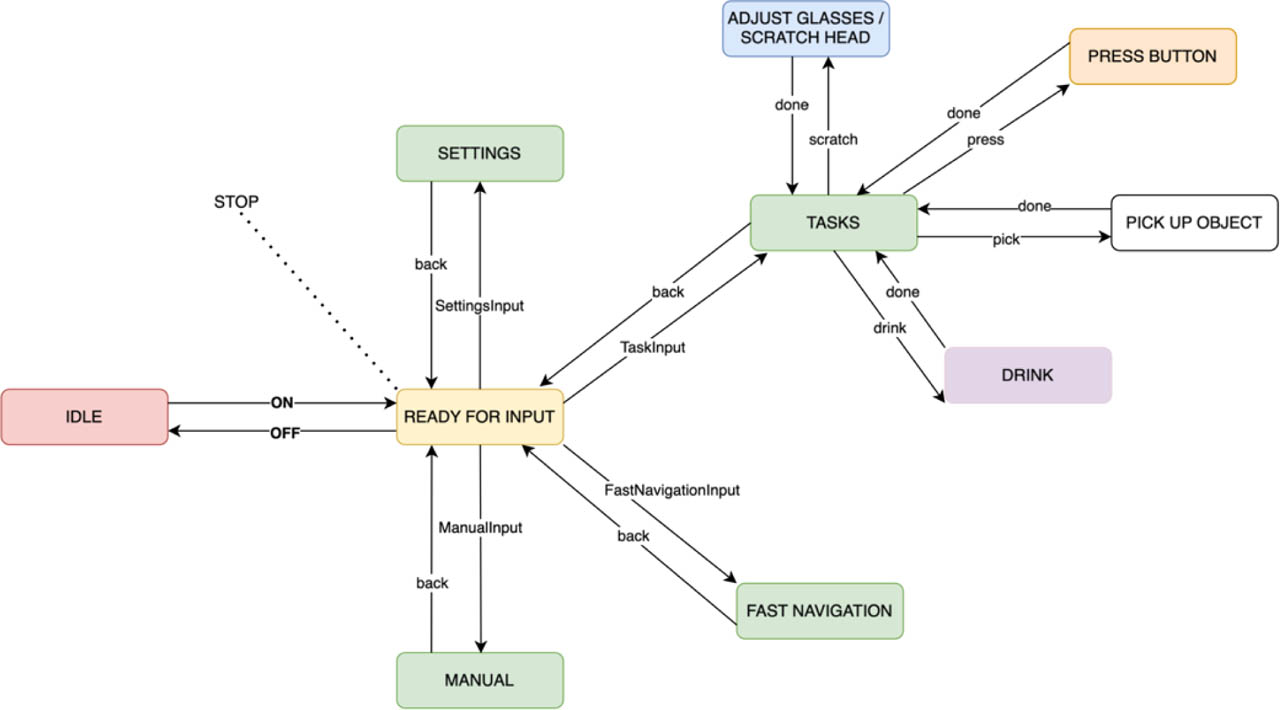
Figure 10:
Exemplary Finite State Machine Task Execution