

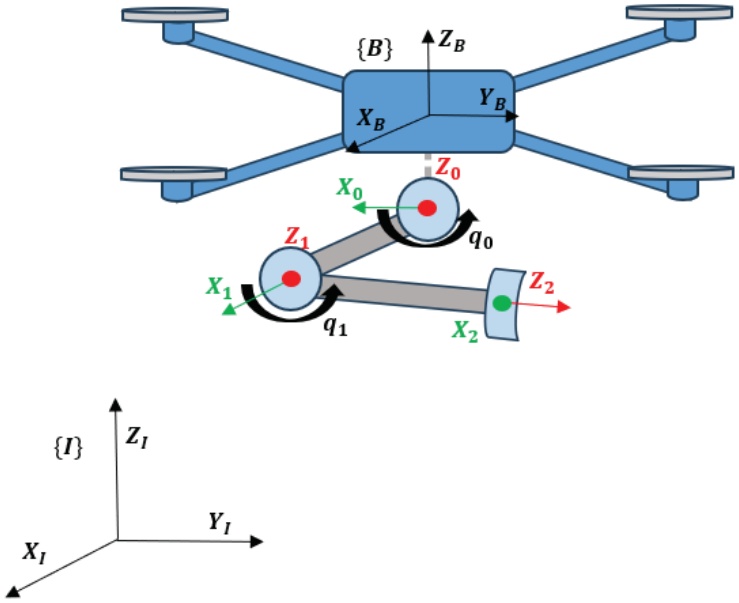
Figure 1.
UAV manipulator system
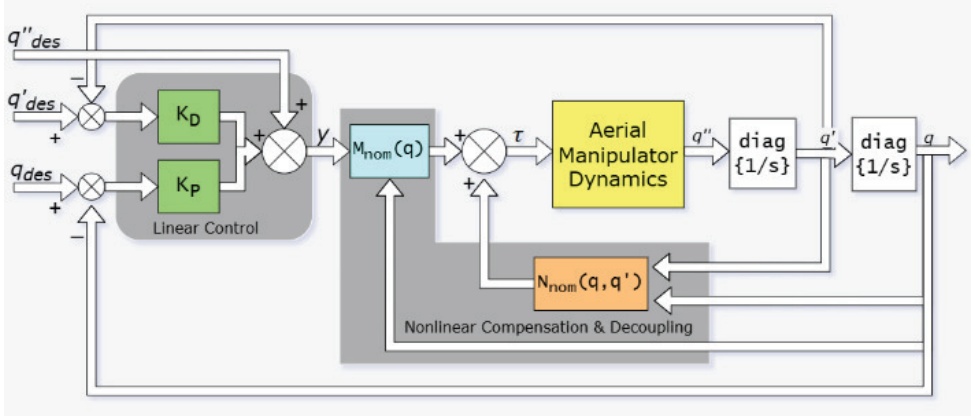
Figure 2.
Block diagram of the UAV manipulator system
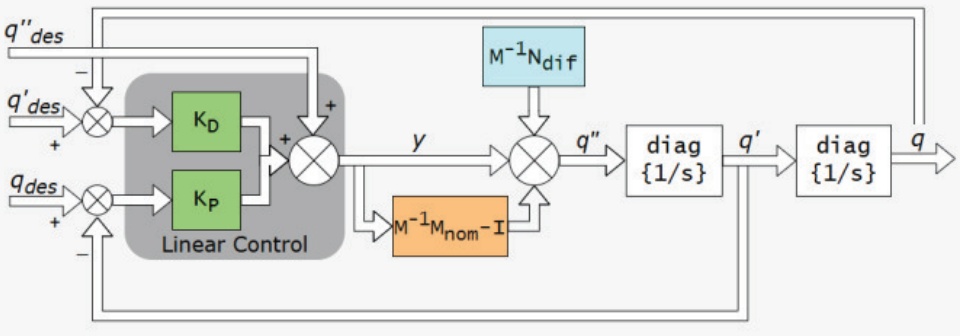
Figure 3.
Block diagram of the linearized system
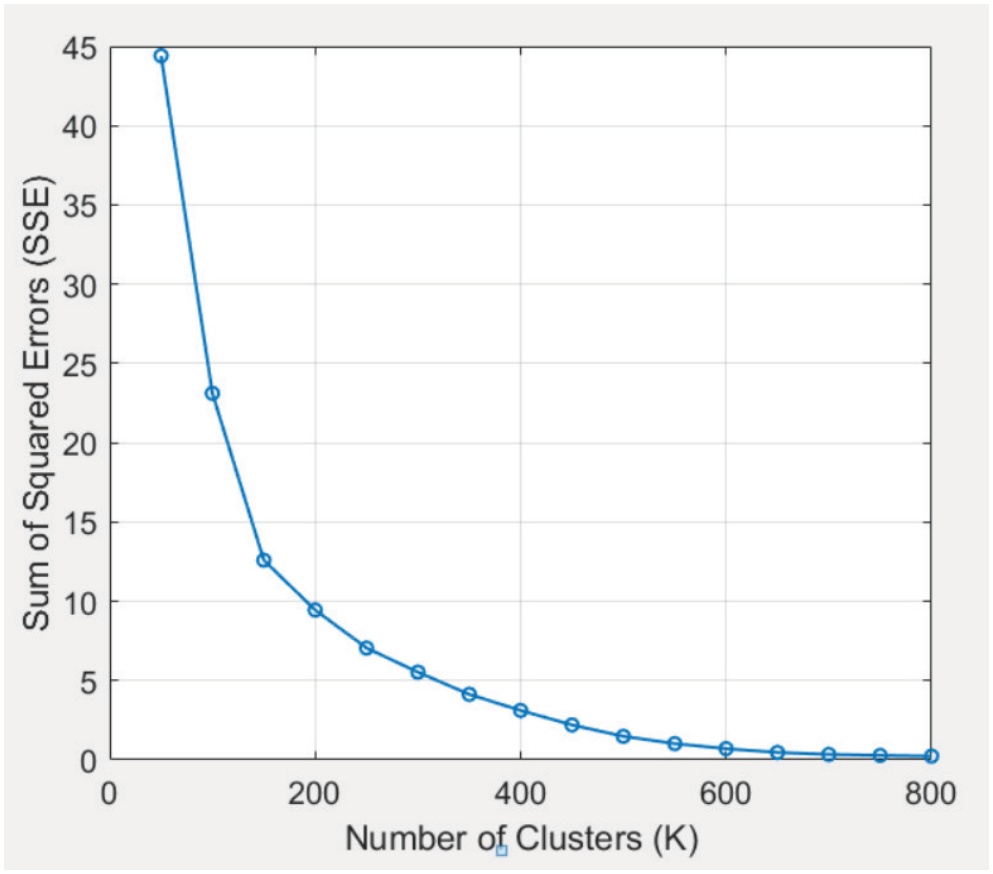
Figure 4.
Elbow method for optimal K
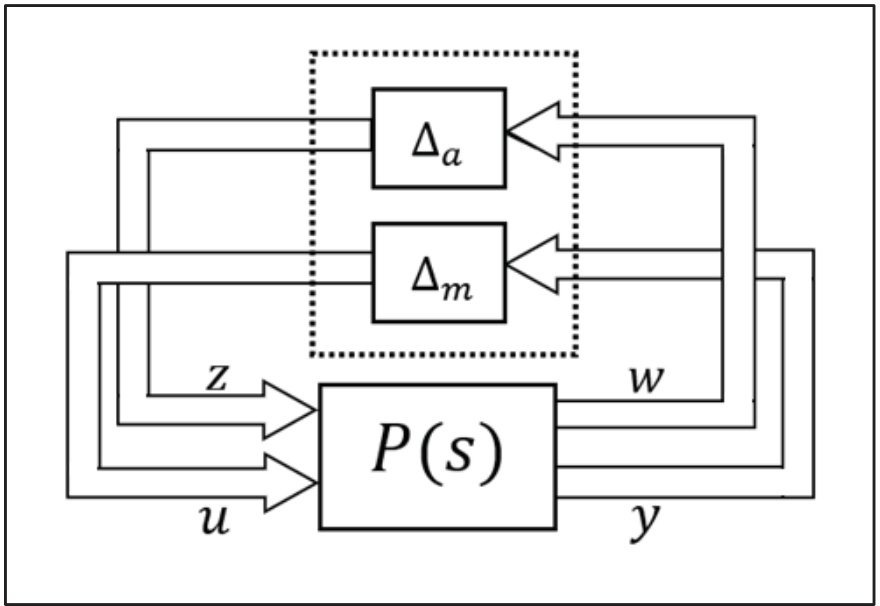
Figure 5.
LFT model of the system
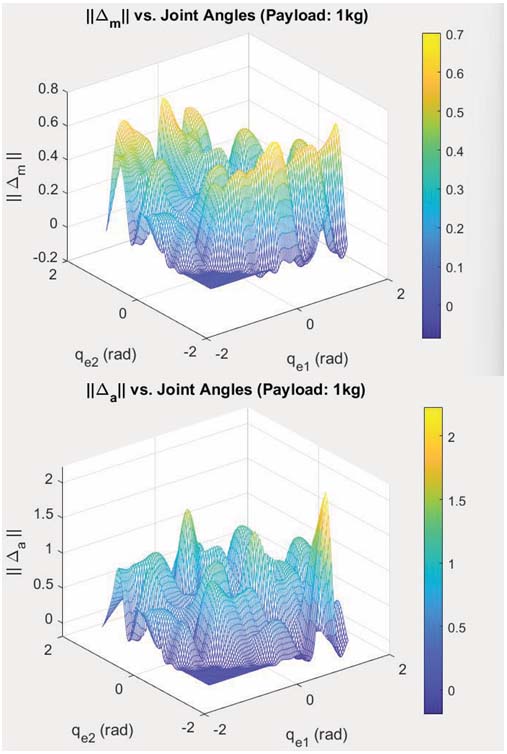
Figure 6.
Uncertainty norms in clusters
Table 1.
UAV and manipulator characteristics
| Parameter | Symbol | Value | Unit |
|---|---|---|---|
| UAV mass | mUAV | 4.5 | kg |
| UAV arm length | LUAV | 0.5 | m |
| UAV moment of inertia (X,Y axes) | IX, IY | 0.075 | kgm2 |
| UAV moment of inertia (Z-axis) | IZ | 0.12 | kgm2 |
| Length of link 1 | L1 | 0.2 | m |
| Length of link 2 | L2 | 0.3 | m |
| Mass of link 1 | mL1 | 0.3 | kg |
| Mass of link 2 | mL2 | 0.45 | kg |
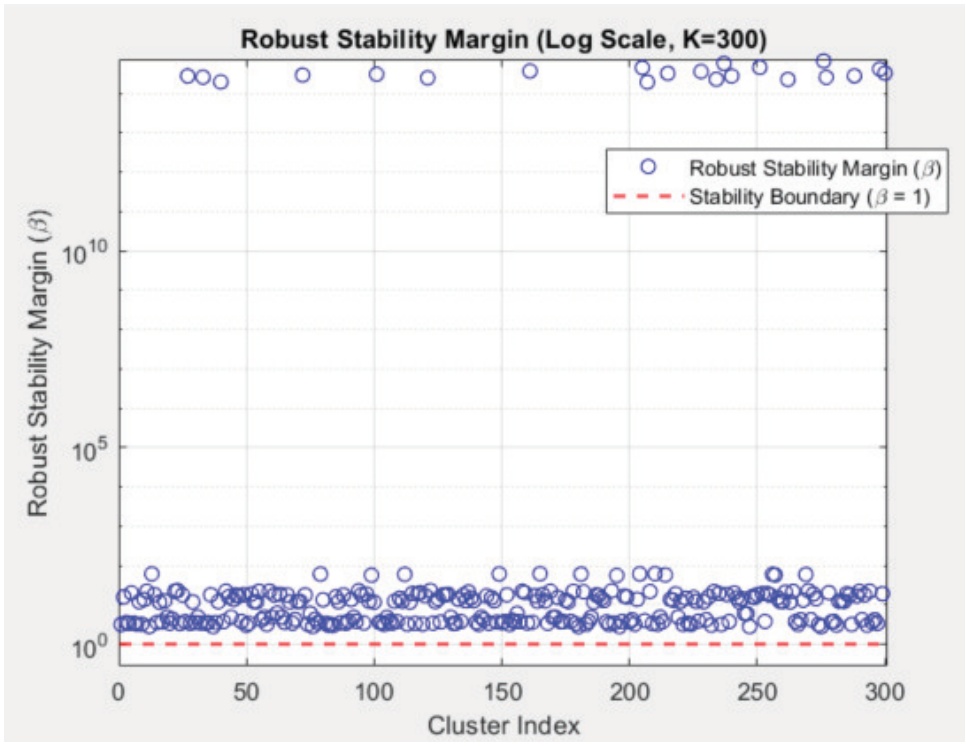
Figure 7.
Robust stability margin (β) on a logarithmic scale
Table 2.
Payload characteristics
| Object | Time | Mass (kg) | Dimensions (m) |
|---|---|---|---|
| Small | 0-10 sec | 0.1 | 0.1, 0.02, 0.02 |
| Medium | 10-20 sec | 0.5 | 0.4, 0.05, 0.05 |
| Big | 20-30 sec | 1 | 0.6, 0.08, 0.08 |
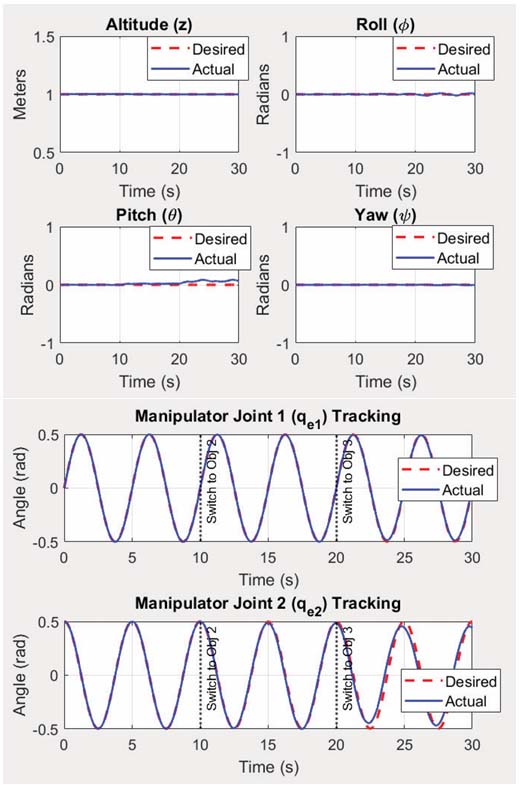
Figure 8.
Trajectory tracking of the system
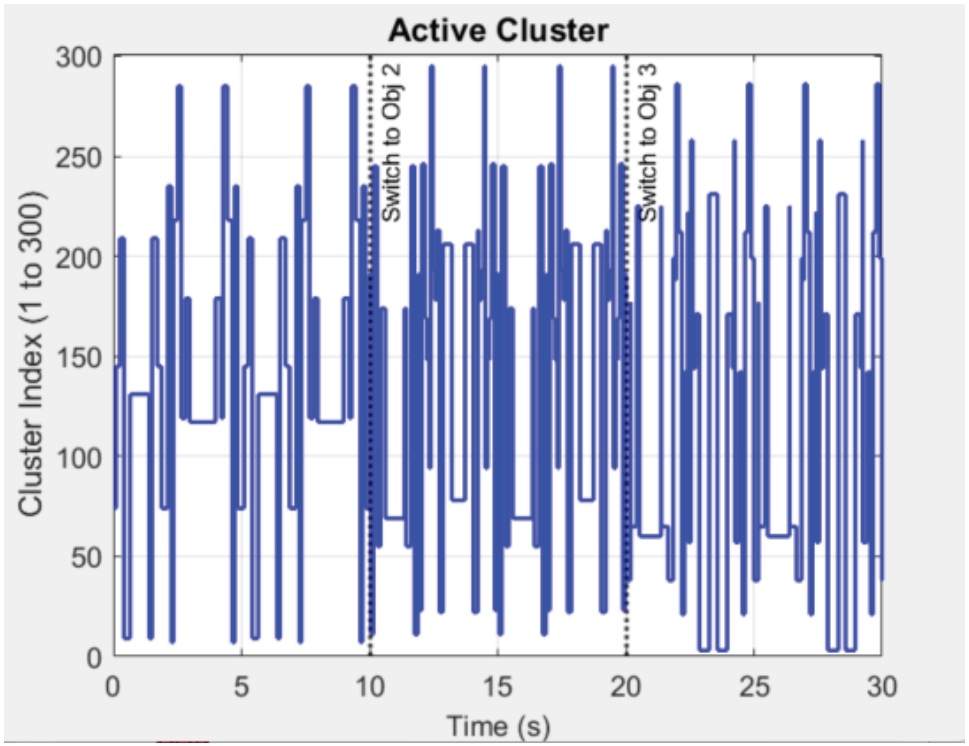
Figure 9.
Active cluster index over time
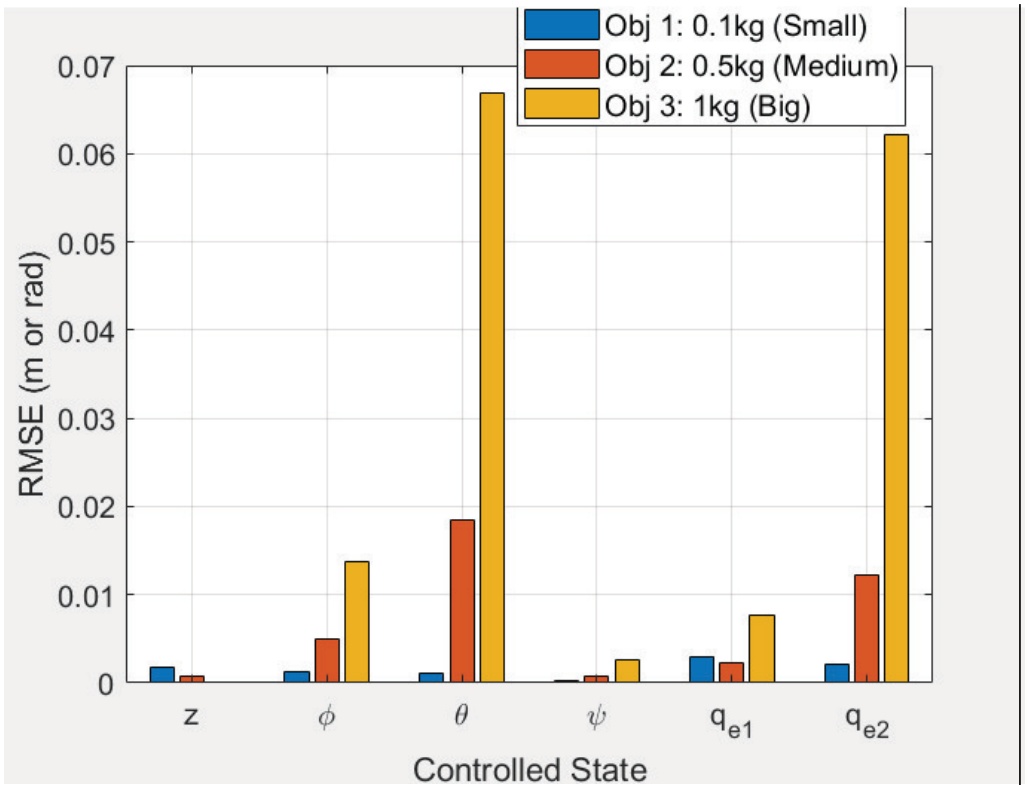
Figure 10.
RMSE by state