

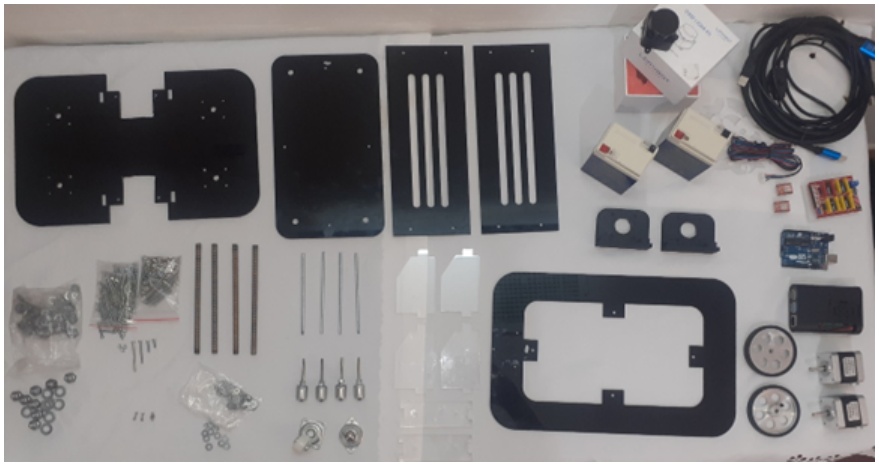
Figure 1.
Robot components used in the proposed mobile robot platform
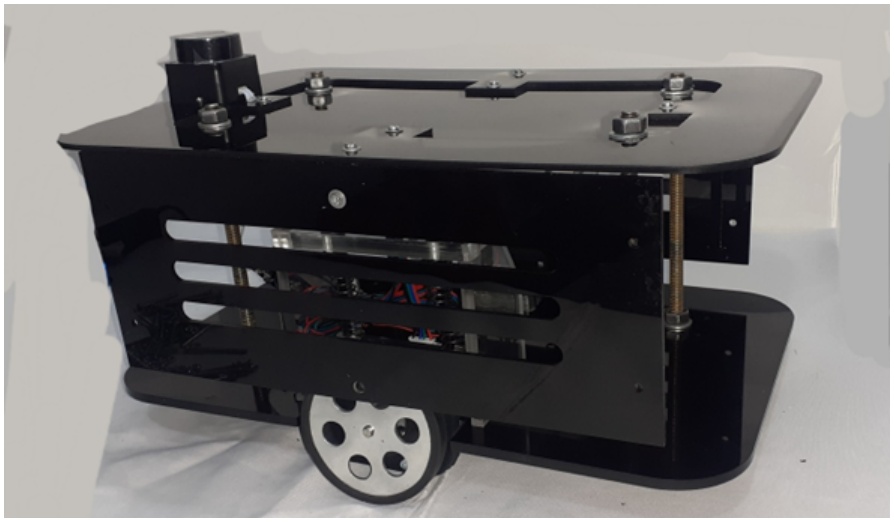
Figure 2.
Fully assembled differential-drive mobile robot system
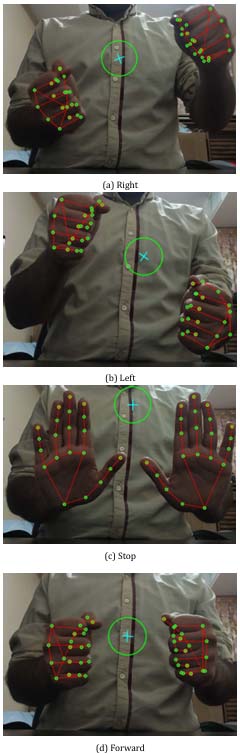
Figure 3.
Hand gestures for controlling the system: Right, Left, Stop, and Forward
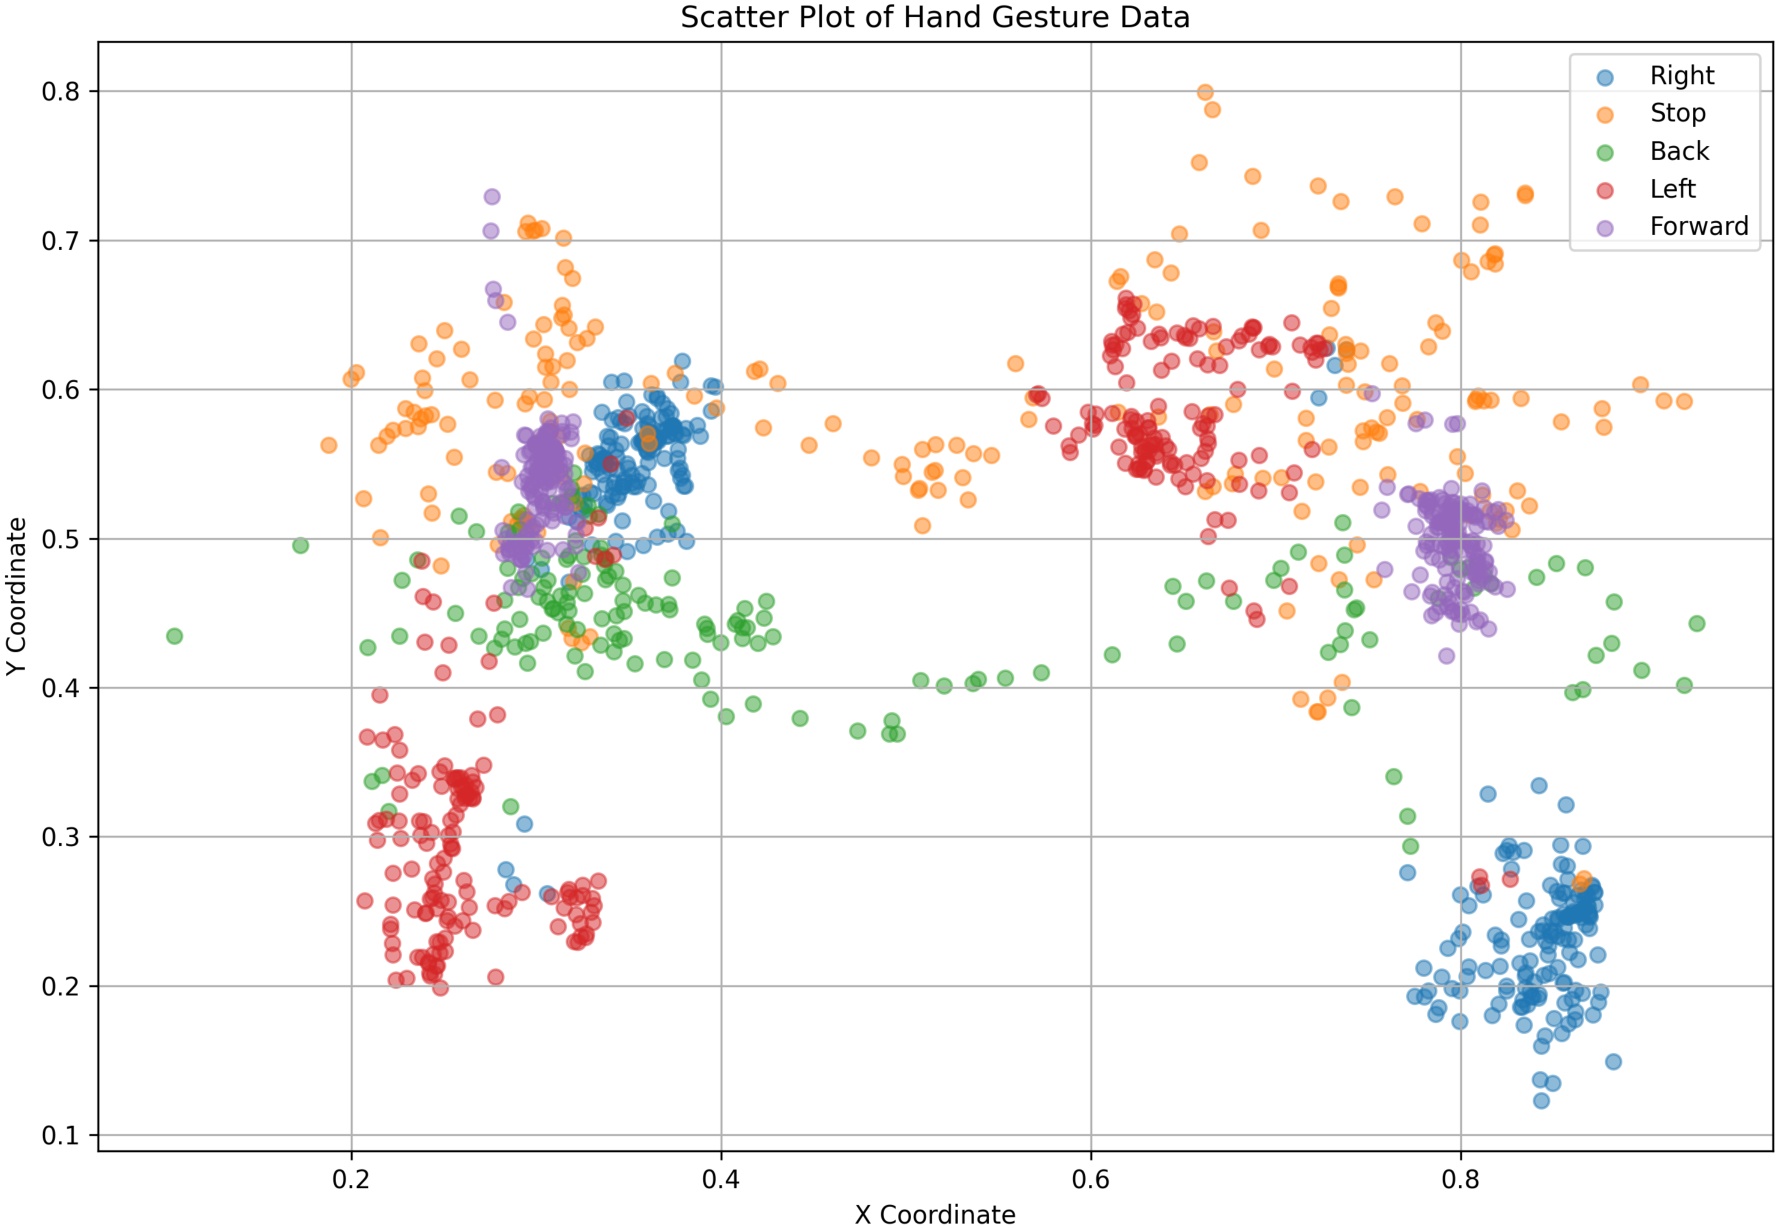
Figure 4.
Scatter plot of the data collected
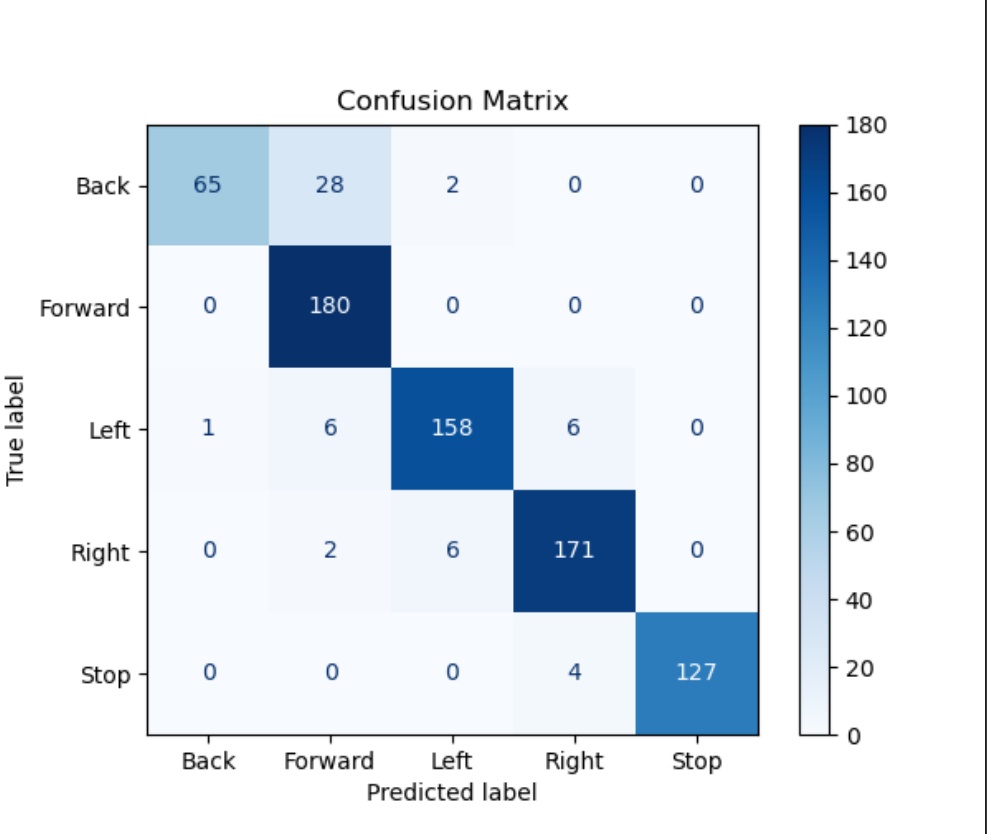
Figure 5.
Confusion matrix of the model