

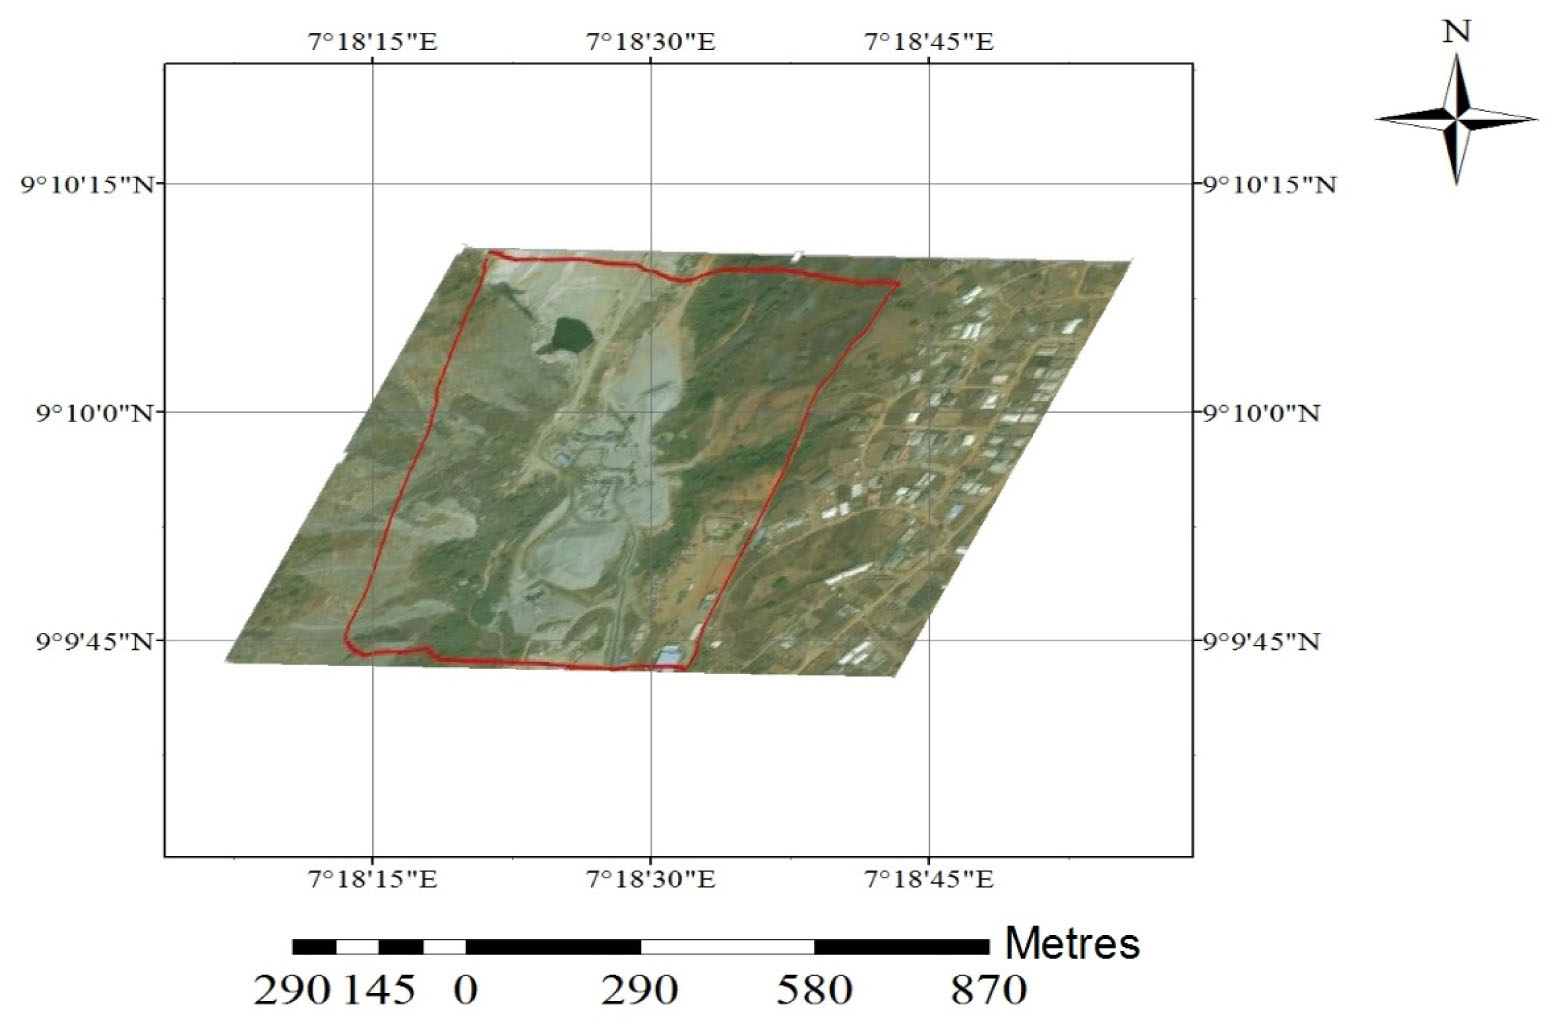
Figure 1
Location map of the project site
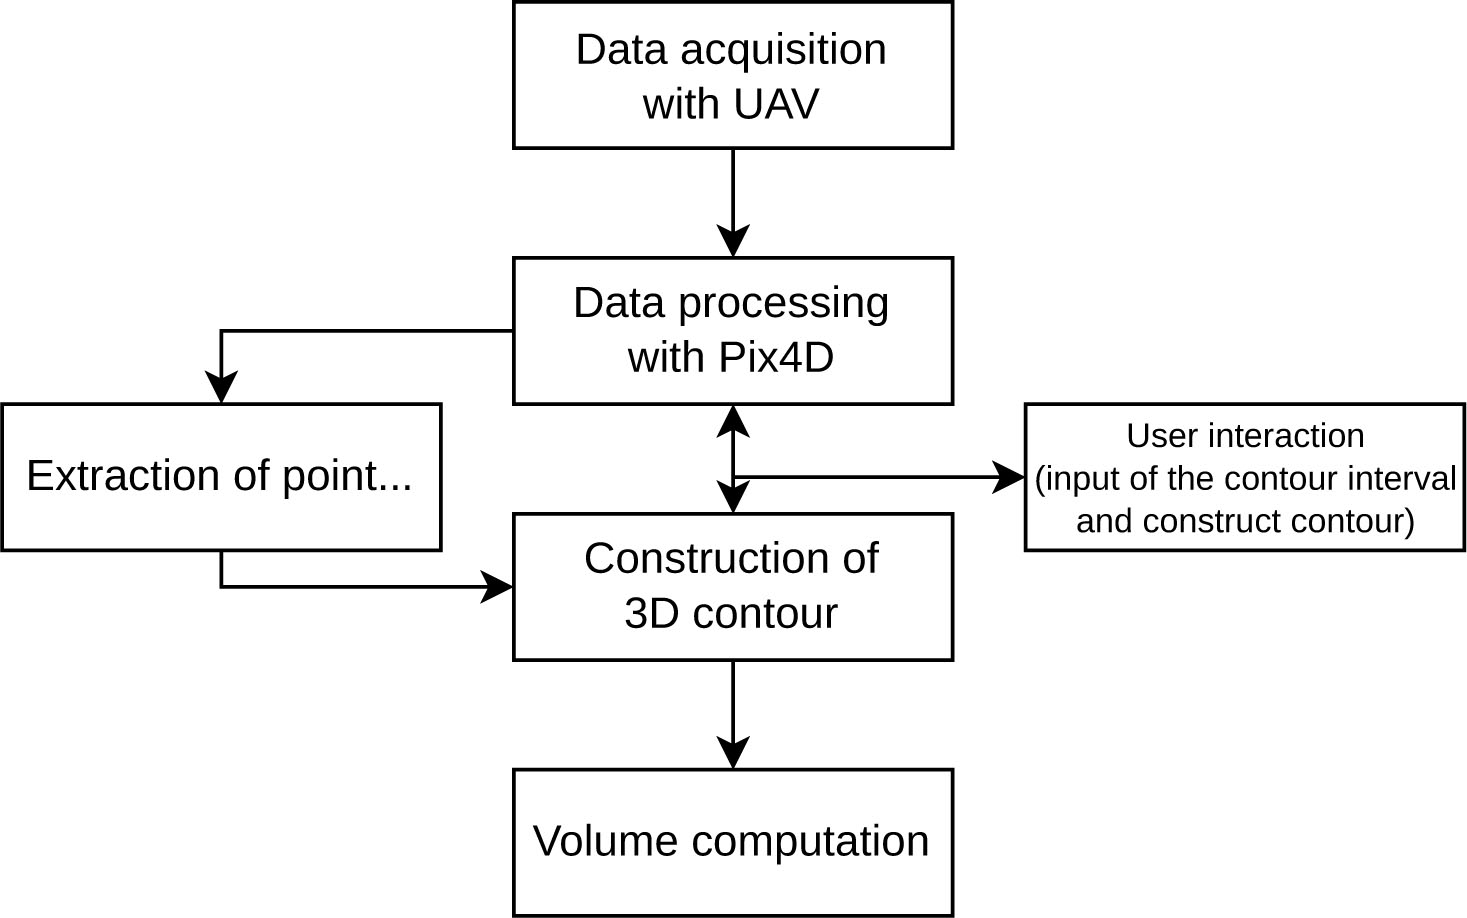
Figure 2
Workflow of the methodology
Table 1
Technical parameters of DJI Phantom 4 (Source: DJI (nd))
| Technical Data | Parameters |
|---|---|
| Aircraft | diagonal size: 350 mm, battery: 1380 g, maximum wind resistance: 10 m/s, maximum flight time: approx. 28 minutes, satellite positioning system: GPS and GLONASS |
| Intelligent flight battery | capacity: 5350 mA h, voltage: 15.2 V, net weight: 462 g, energy: 81.3 W h |
| Gimbal | controllable range: pitch: −90° to +30°, stabilisation(3-axis; pitch, roll, yaw, maximum controllable angular speed: pitch: 90°/s |
| Camera | sensor: 12.4 MP CMOS, lens: FOV 94° 20 mm [35-mm format equivalent] f/2.8 focus at 1, image size: 4000 × 3000 |
| Remote controller | Operating frequency: 2.400–2.483 GHz, battery: 6000 mA h LiPo25, operating current/voltage: 1.24@7.4V |
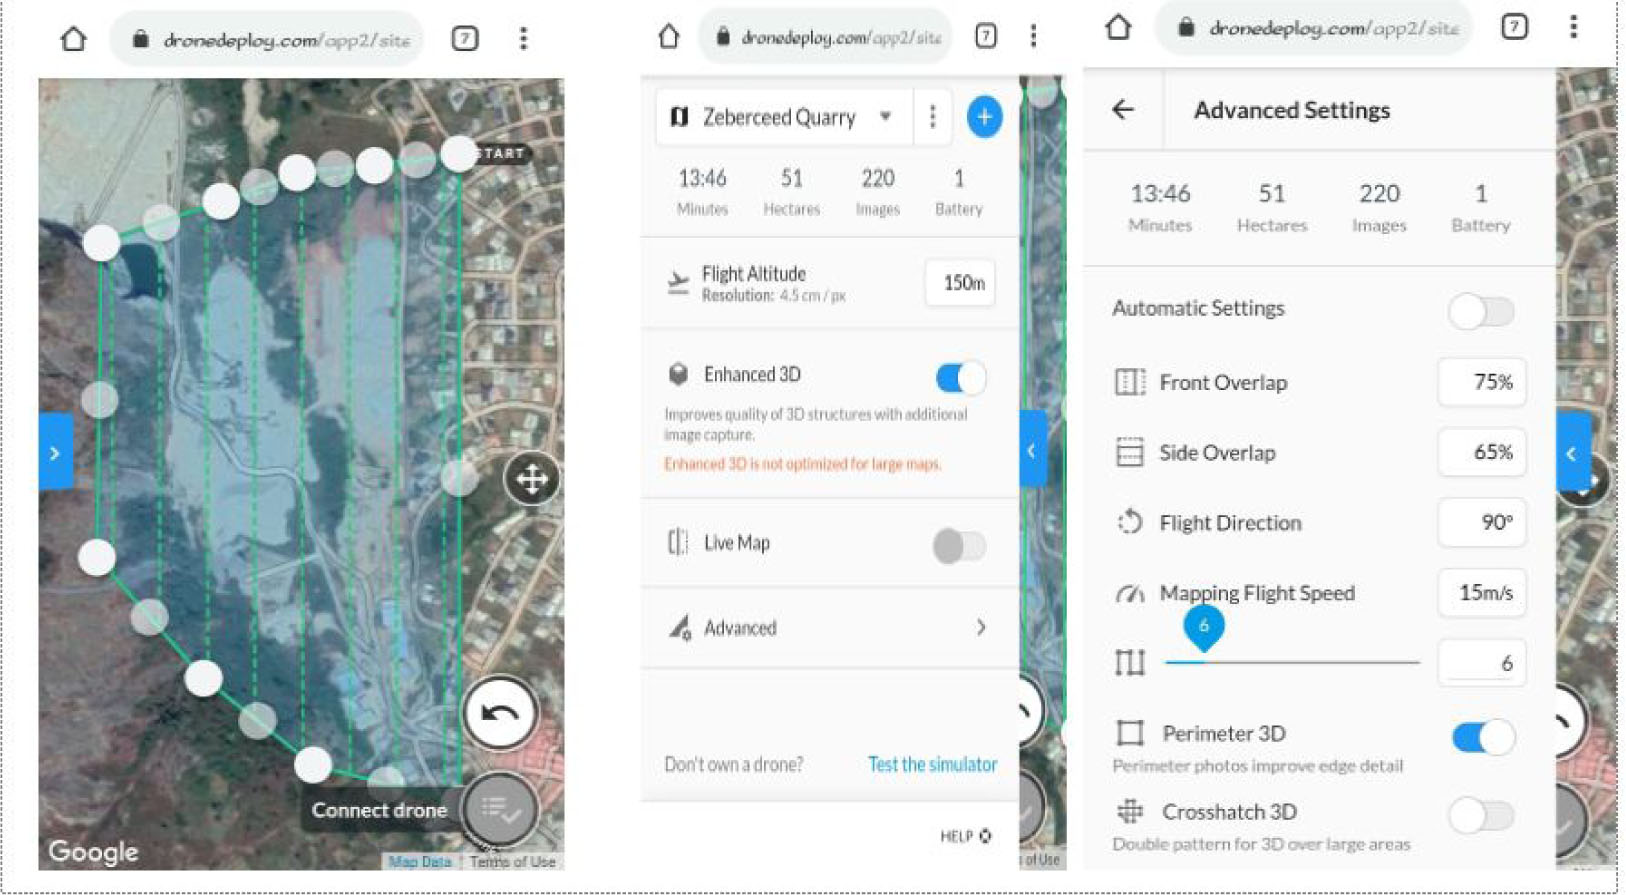
Figure 3
Flight plan made from Dronedeploy
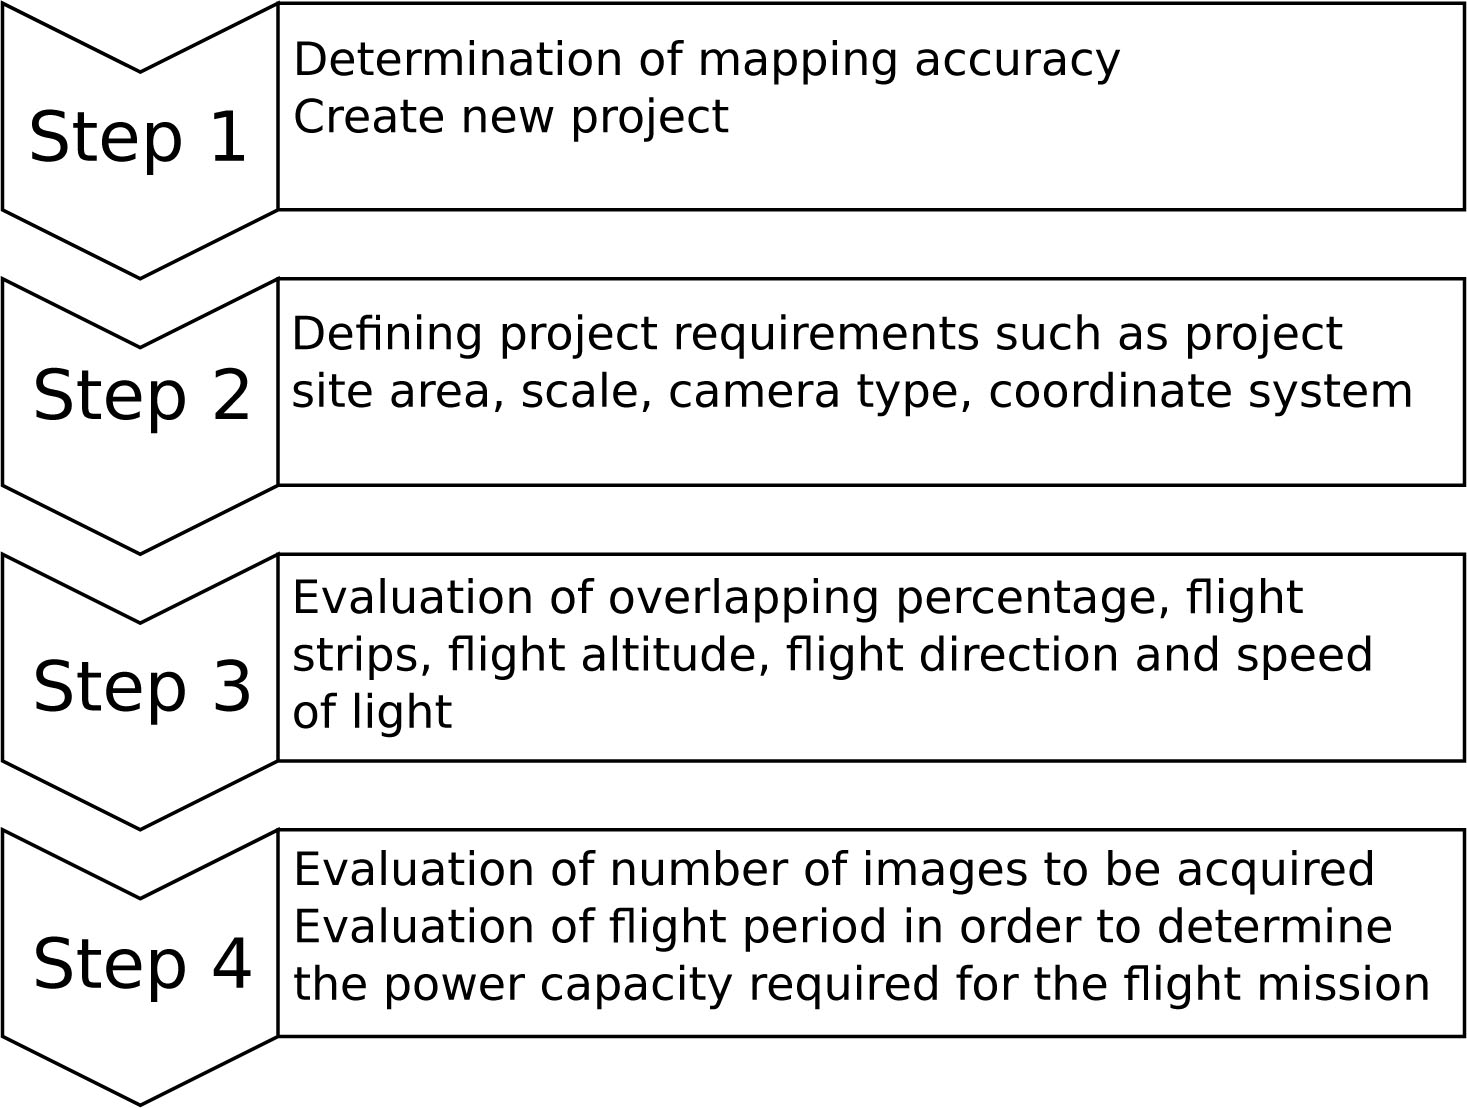
Figure 4
Graphical scheme of flight planning
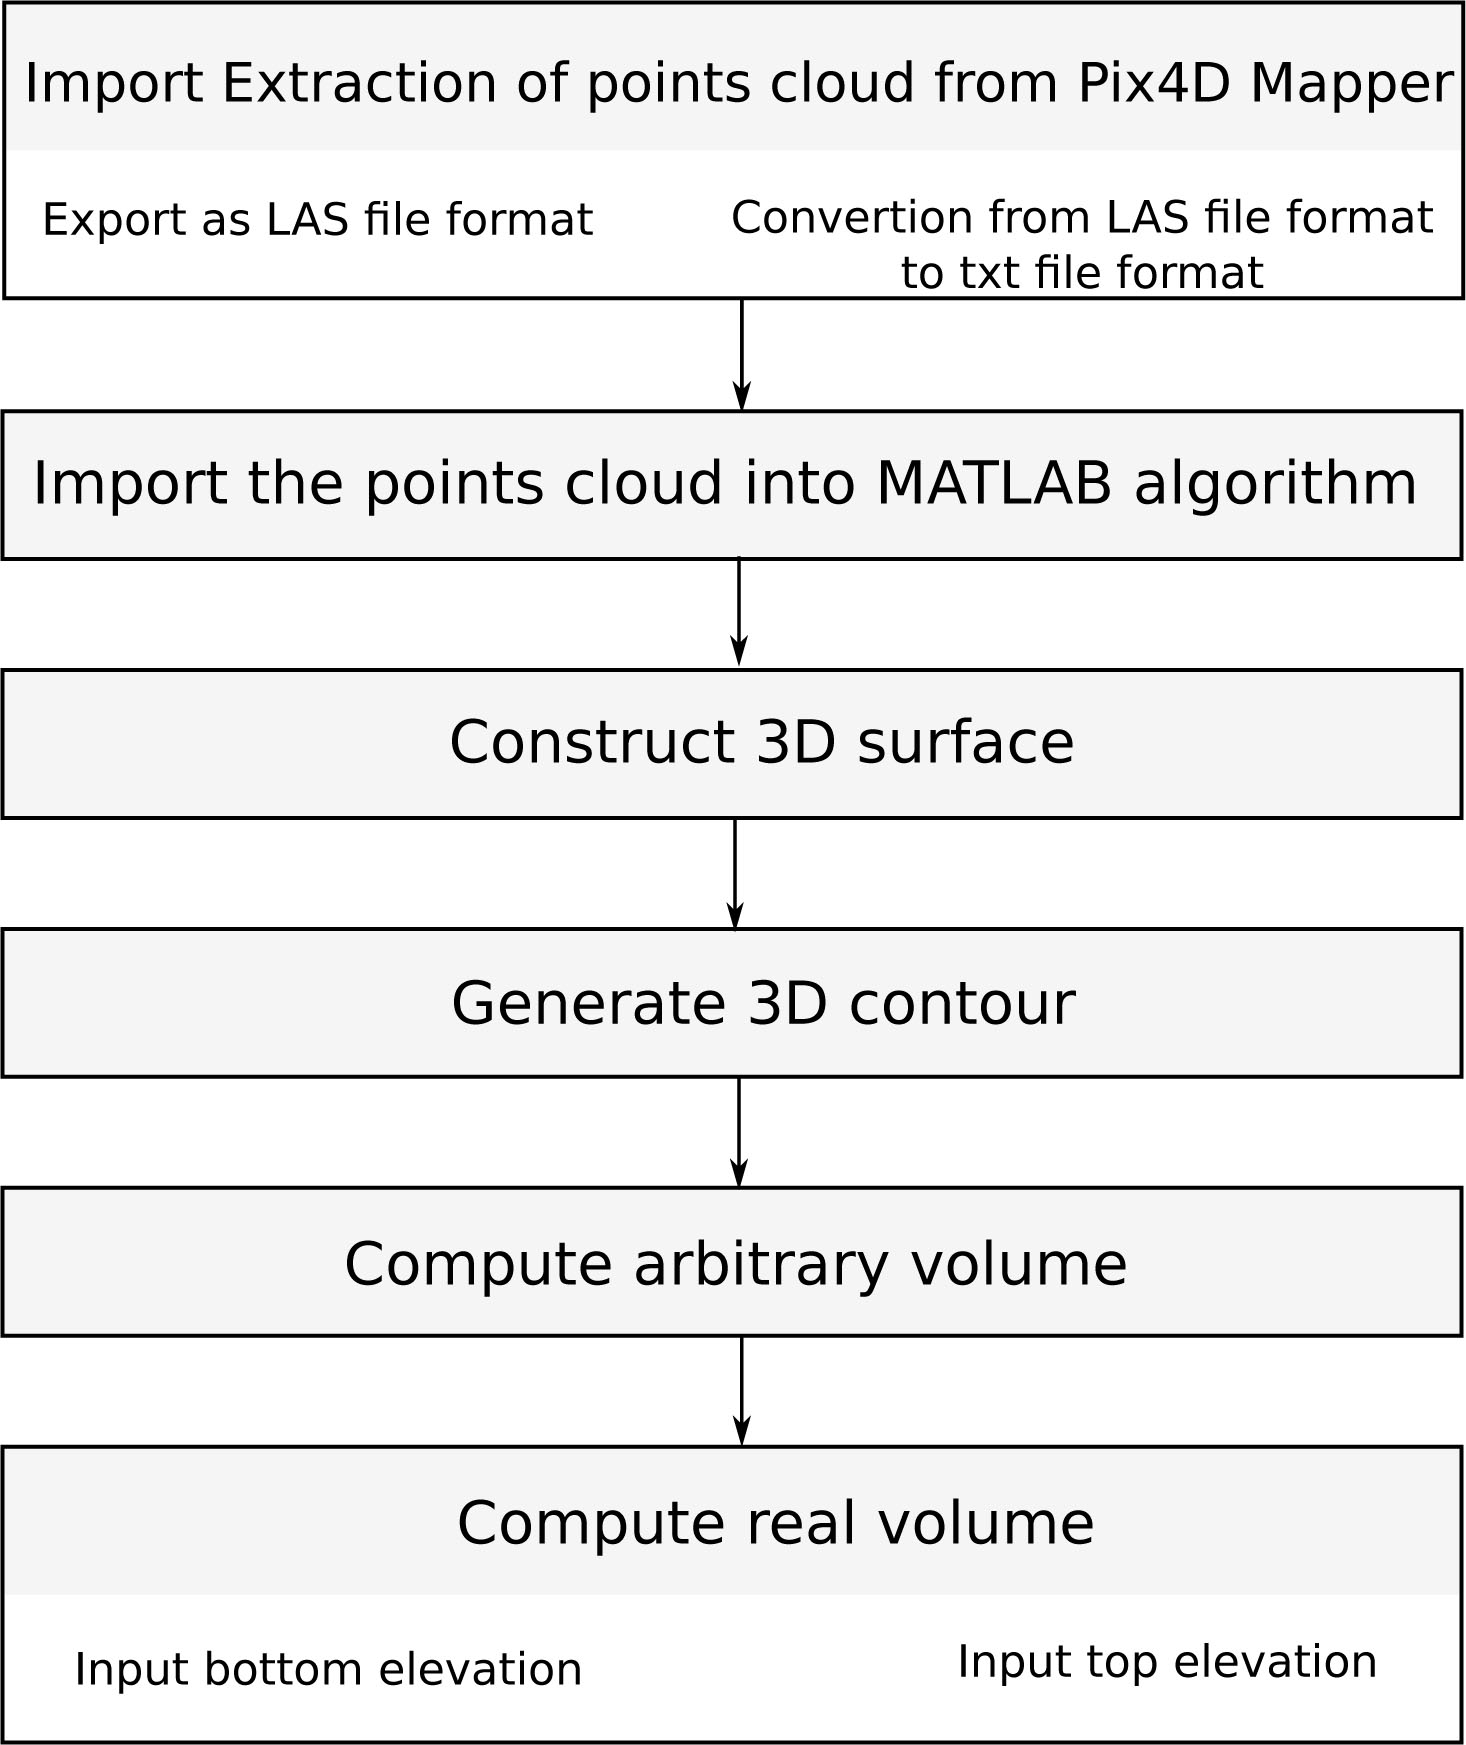
Figure 5
Workflow of the developed algorithm
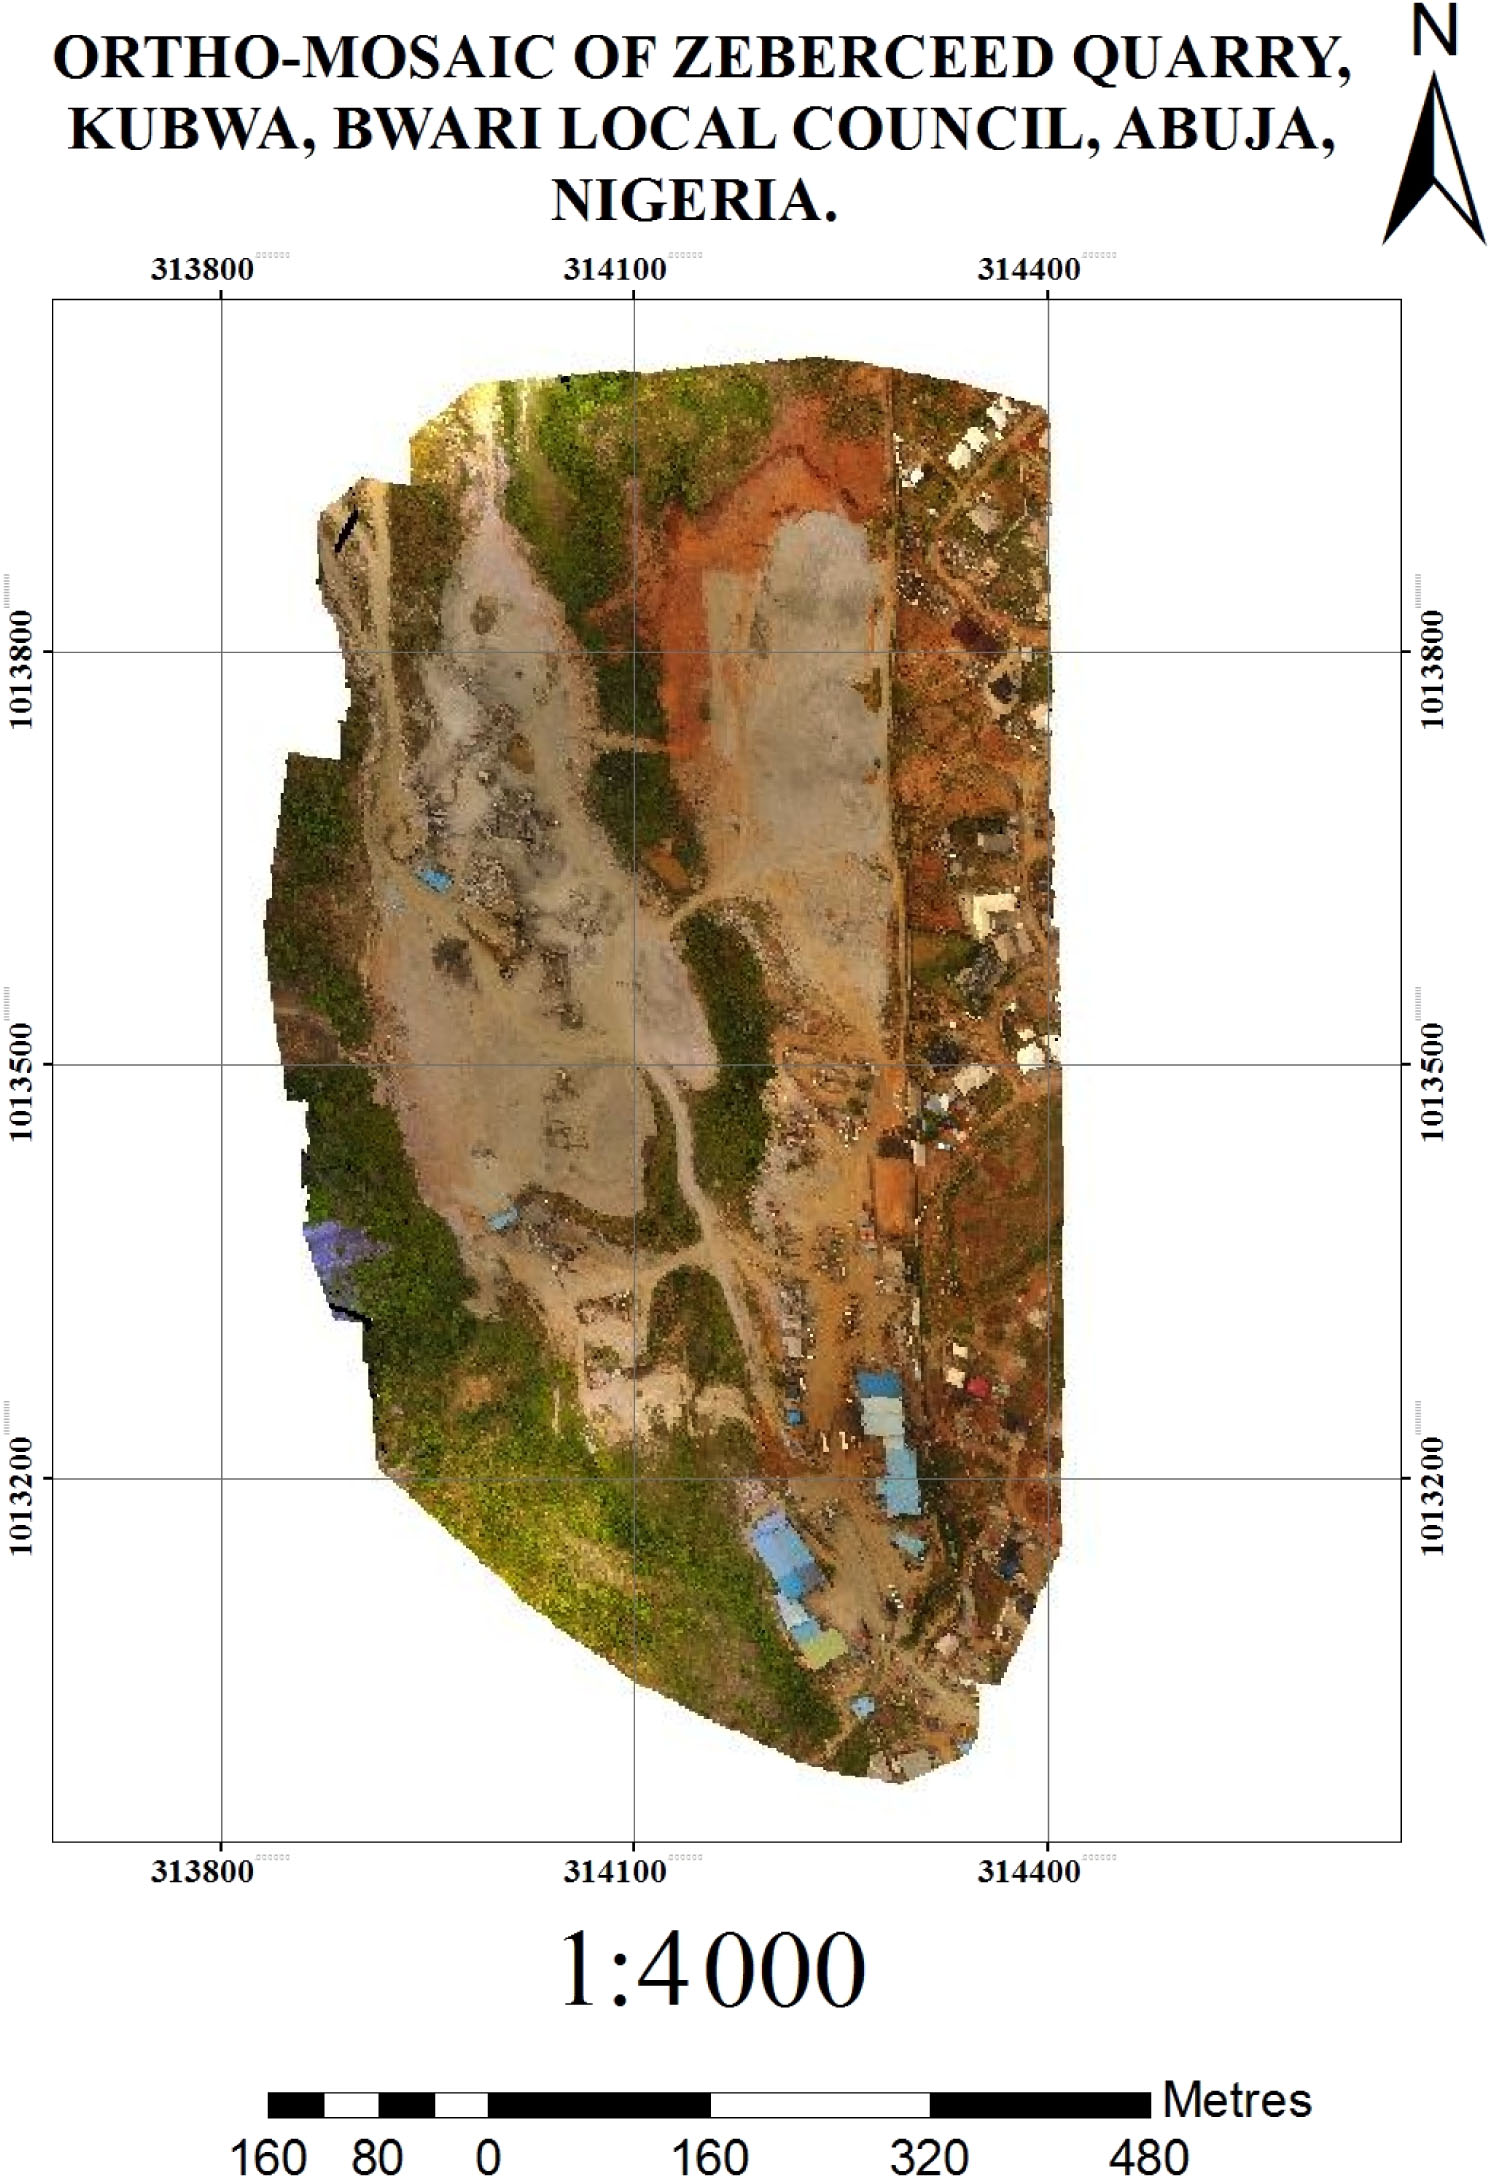
Figure 6
Orthomosaic of the study site obtained from Pix4D
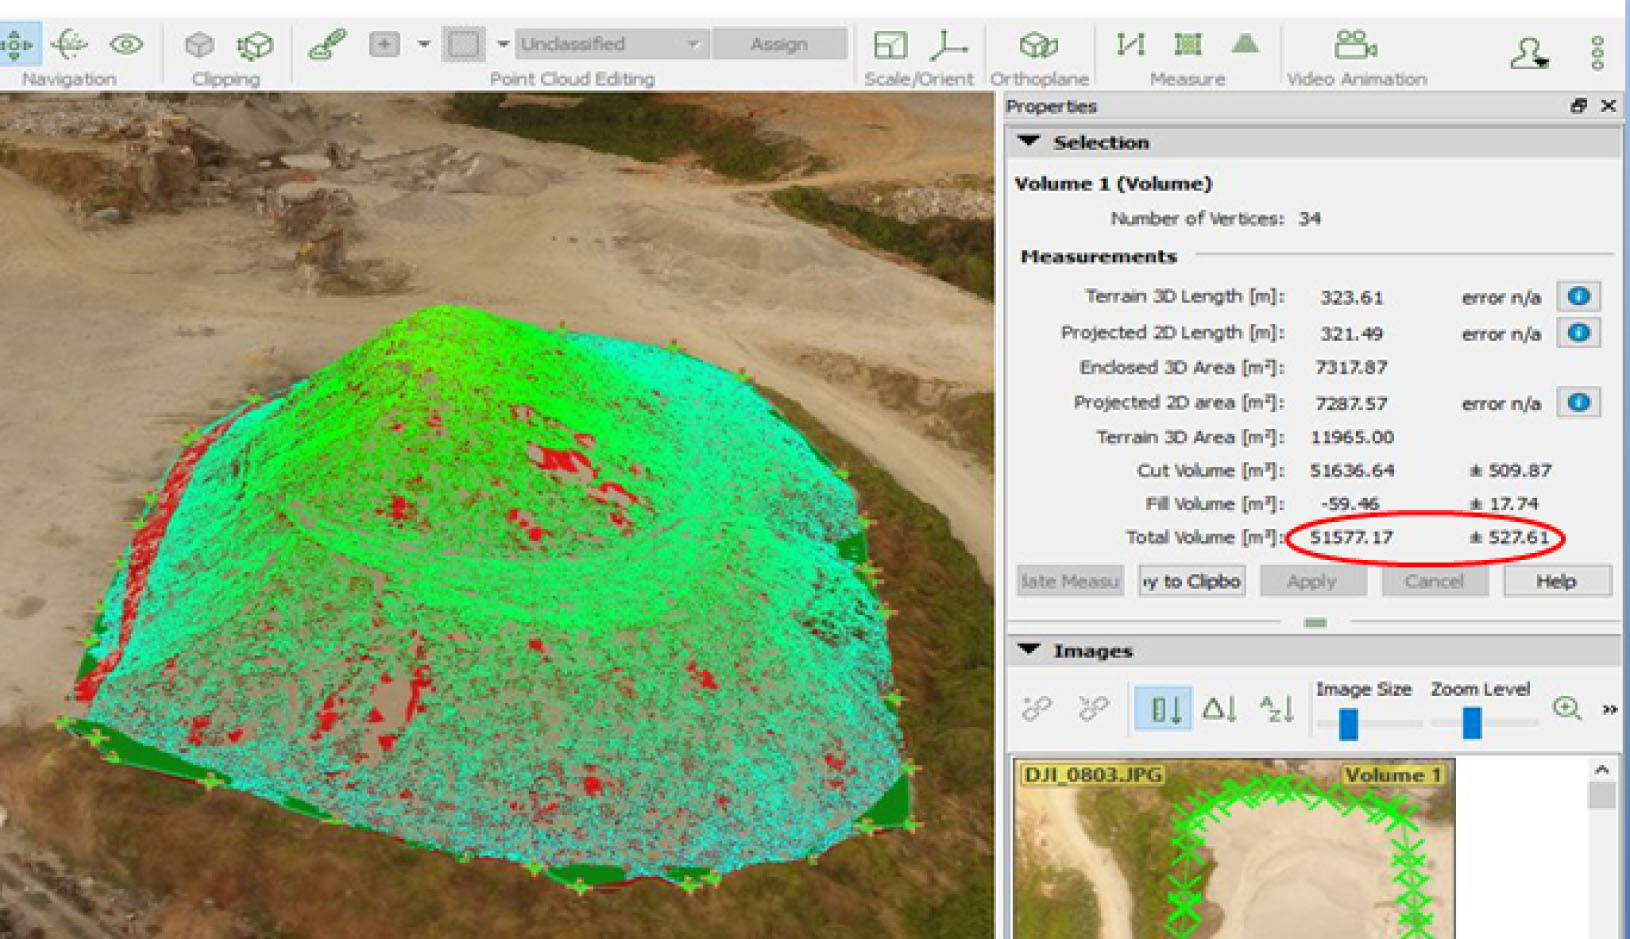
Figure 7
The major stockpile with marked base for volume computation
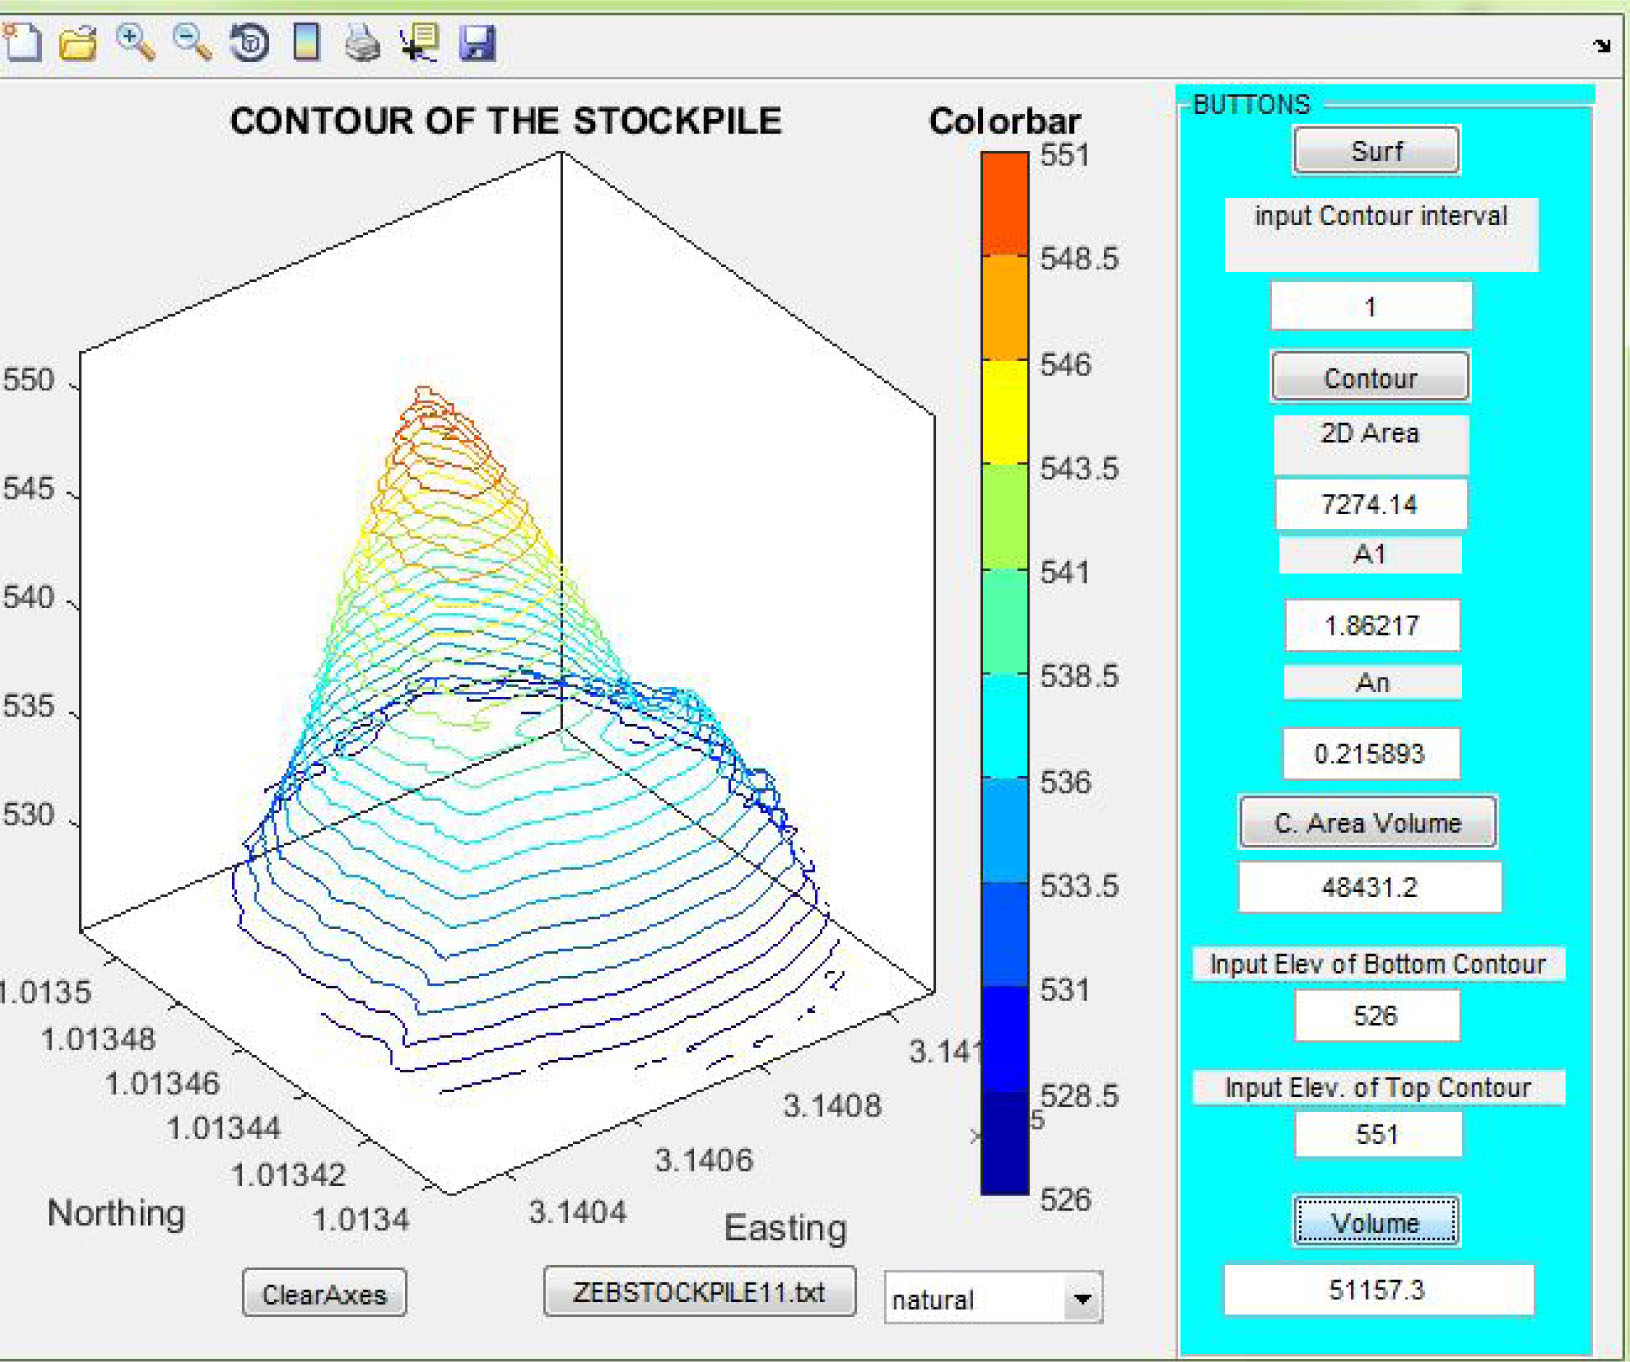
Figure 8
Image of the major stockpile contour and volume values