Have a personal or library account? Click to login
Determining of correlation relationship between roll, pitch, and yaw for UAVs Cover

Determining of correlation relationship between roll, pitch, and yaw for UAVs

Open Access
|May 2019

Figures & Tables

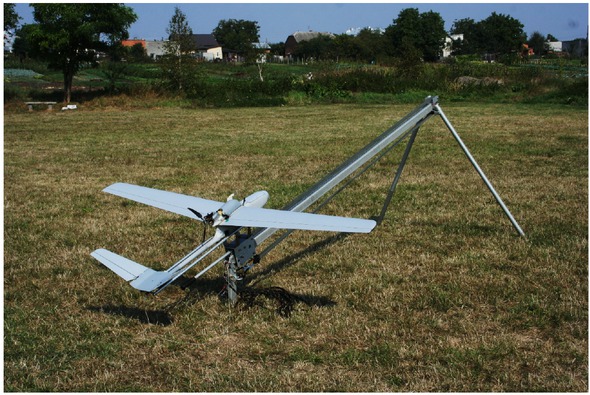
Figure 1

UAV ‘Arrow’ aircraft type

Table 1

The technical characteristics of the UAV ‘Arrow’

CharacteristicsParameters
Digital cameraSony QX1
Take-off weight [kg]4.8
Battery capacity [Ah]16
Minimum flight speed [km/h]50
Cruising flight speed [km/h]60–80
Maximum flight time [min]100
Maximum flight range [km]100
Maximum controlled distance from the base [km]15
Maximum flight altitude [m]5000
Minimum operational altitude [m]75
The maximum image resolution [sm/px]2
Dimensions in transportation configuration [sm]120 × 25 × 25
Limiting wind speed [m/s]12
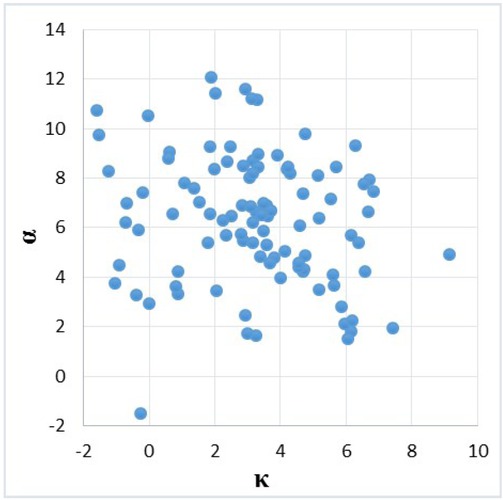
Figure 2

Correlation diagram ĸ and α

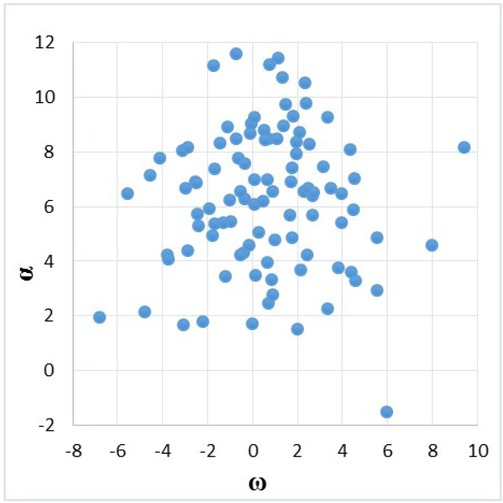
Figure 3

Correlation diagram α and ω
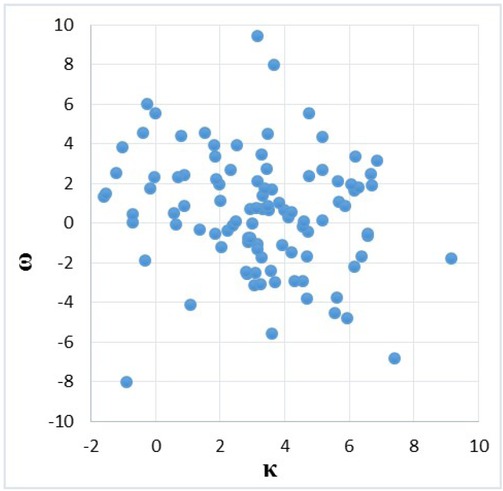
Figure 4

Correlation diagram ĸ and ω
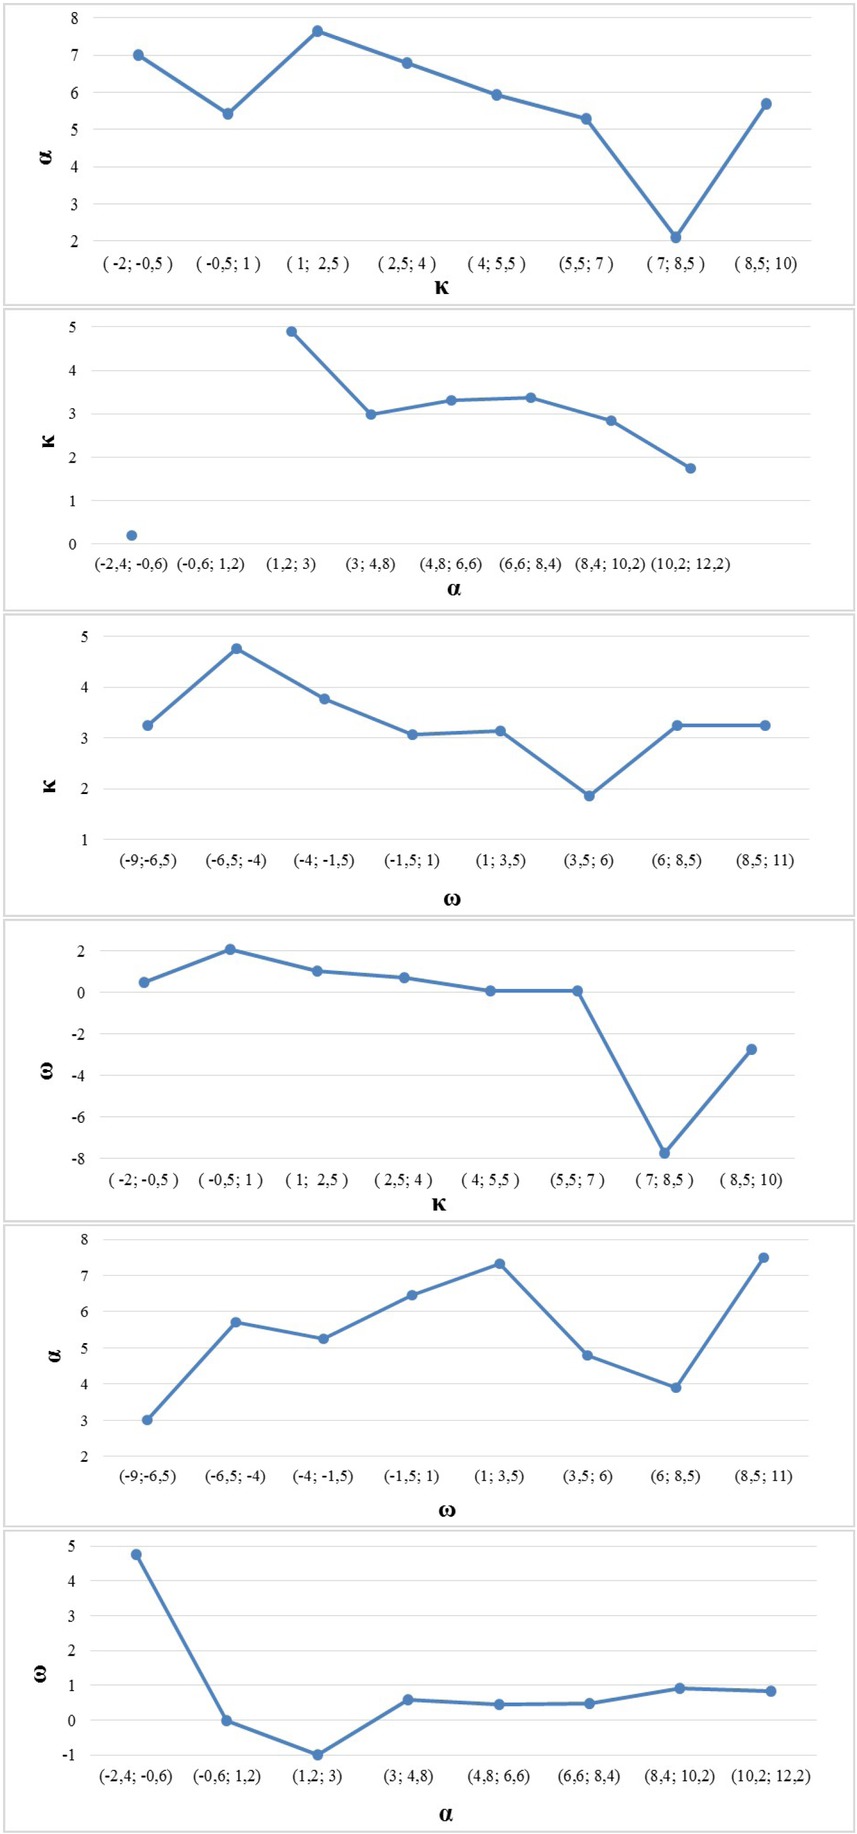
Figure 5

Empirical regression lines

Table 2

Coefficient of multiple correlation

Regression statistics
R0.378
R20.143
Standardized R20.125
Table 3

Parameters of the regression model

Coeff. of regr. modelStandard Errort-statisticP-valueLower 95%Upper 95%
a04.4821.7590892.54780.01244440.98967.9741
a1-1.2330.312375-3.94690.0001517-1.8530-0.6128
a2-0.2480.228563-1.08510.2806222-0.70180.2057
Table 4

Dispersion analysis

dfSSMSF-valueSignificance level F
Factors (m)21046.16831523.08415517.9372867510.000649162
Residue956260.7029765.90213653
nm – 1977306.871281
DOI: https://doi.org/10.2478/rgg-2019-0002 | Journal eISSN: 2391-8152 (formerly 0867-3179) | Journal ISSN: 0867-3179
Language: English
Page range: 13 - 18
Submitted on: Sep 7, 2018
Accepted on: Mar 15, 2019
Published on: May 11, 2019
Published by: Warsaw University of Technology
In partnership with: Paradigm Publishing Services
Publication frequency: 2 issues per year

© 2019 Volodymyr Hlotov, Alla Hunina, Mariana Yurkiv, Zbigniew Siejka, published by Warsaw University of Technology
This work is licensed under the Creative Commons Attribution-NonCommercial-NoDerivatives 4.0 License.