
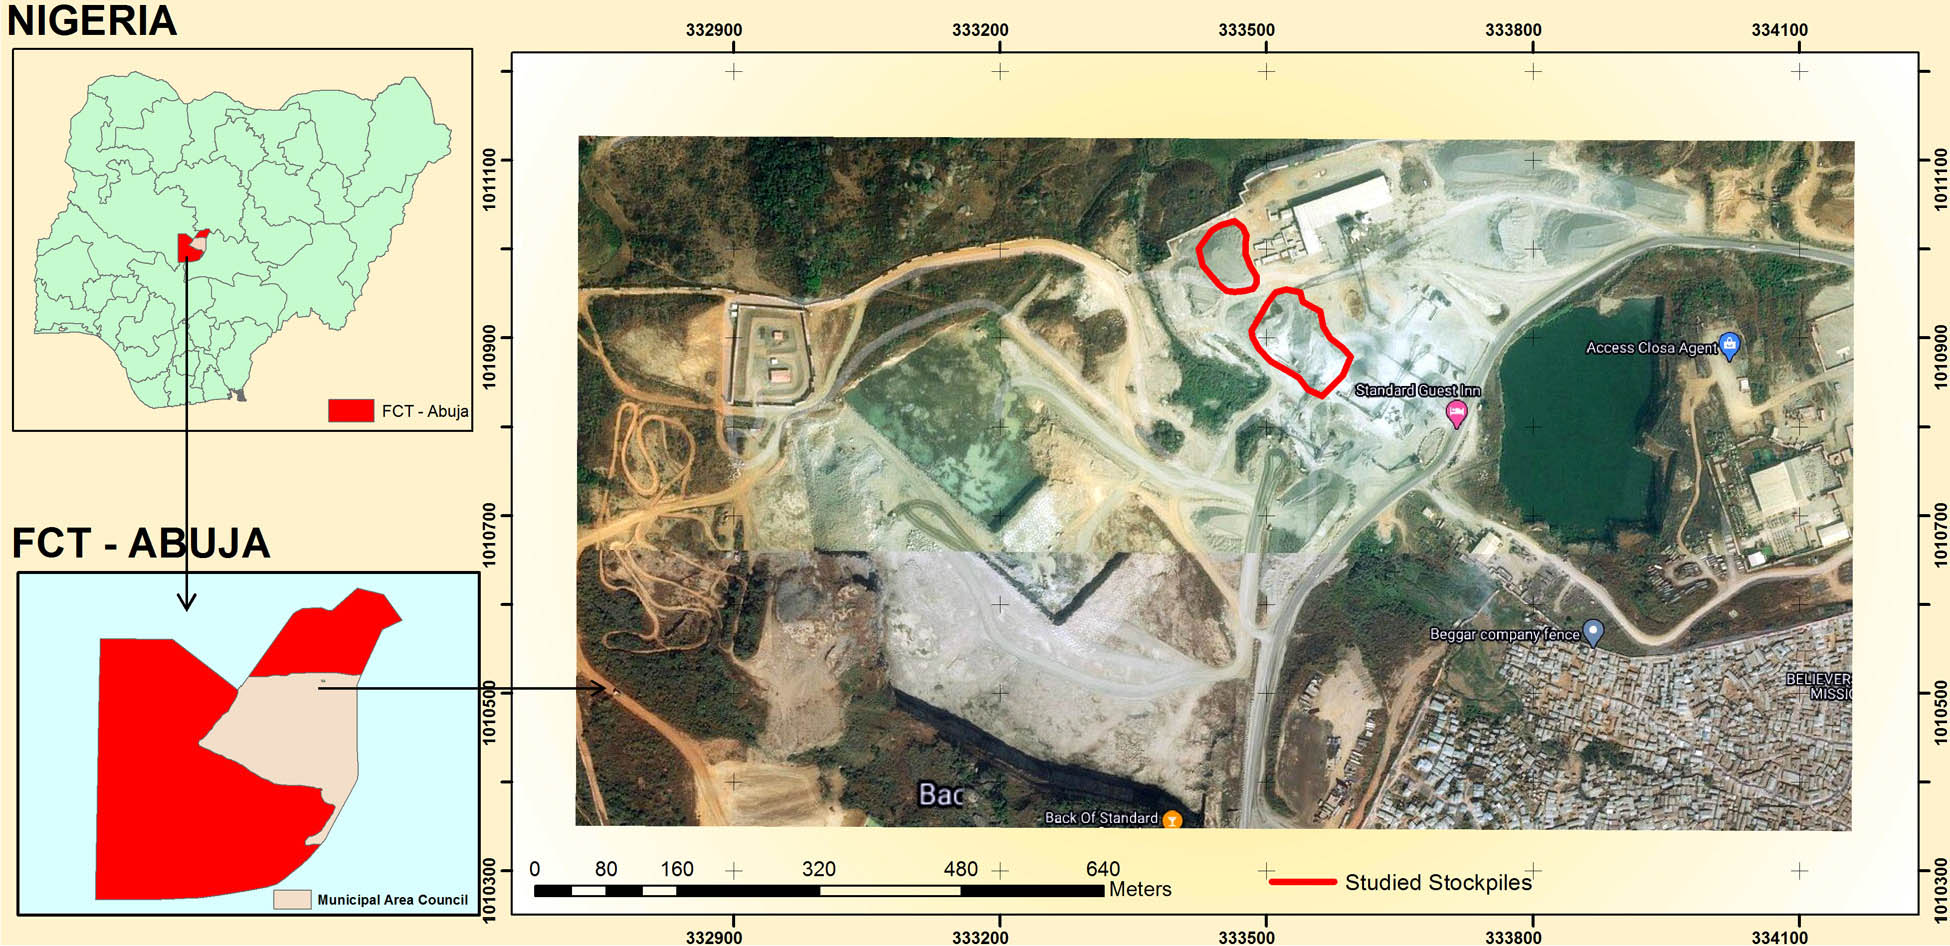
Fig. 1
Diagrammatic representation of the study area.
Table 1
Technical Parameters of DJI Mavic Air UAV.
| Components | Parameter |
|---|---|
| Aircraft | Take-off Weight: 430 g, GNSS (GPS + GLONASS), internal storage (8 GB), operating temperature range (0–40°), maximum flight distance (10 km), maximum wind speed resistance (29–38 kph). |
| Remote Controller | Operating frequency (2.400–2.4835 GHz, 5.725–5.850 GHz), operating temperature (0–40°), battery (2970 mAh). |
| Gimbal | Mechanical range (Tilt: −100° to 22°, Roll: −30° to 30°, Pan: −12° to 12°), stabilization (3-axis, that is, tilt, roll and pan), controllable range (−90° to 0° as default setting, −90° to +17° as extended setting). |
| Camera | Sensor (1/2.3″ CMOS), Lens (FOV: 85°, 35 mm format equivalent to 24 mm, aperture: f/2.8, shooting range: 0.5 m to ∞), photo format (JPEG/DNG (RAW)), supported file format (FAT32). |
| Intelligent flight battery | Capacity (2375 mAh), voltage (11.55 v), Battery type (LiPo 3S), net weight (140 g) |
| Mobile device control | Operating frequency (2.400–2.4835 GHz, 5.725–5.850 GHz), maximum transmission distance (80 m) with height of 50 m. |
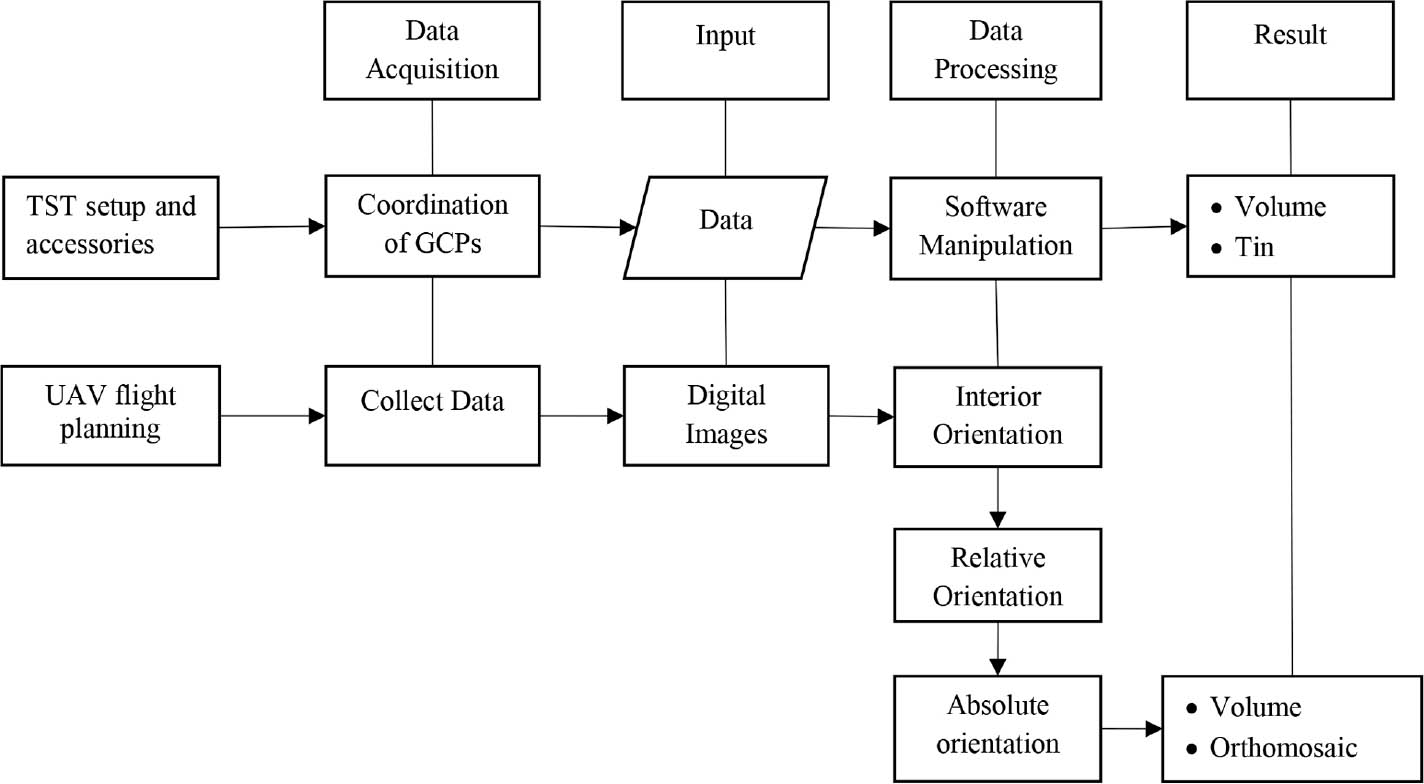
Fig. 2
A chart of the methodology.
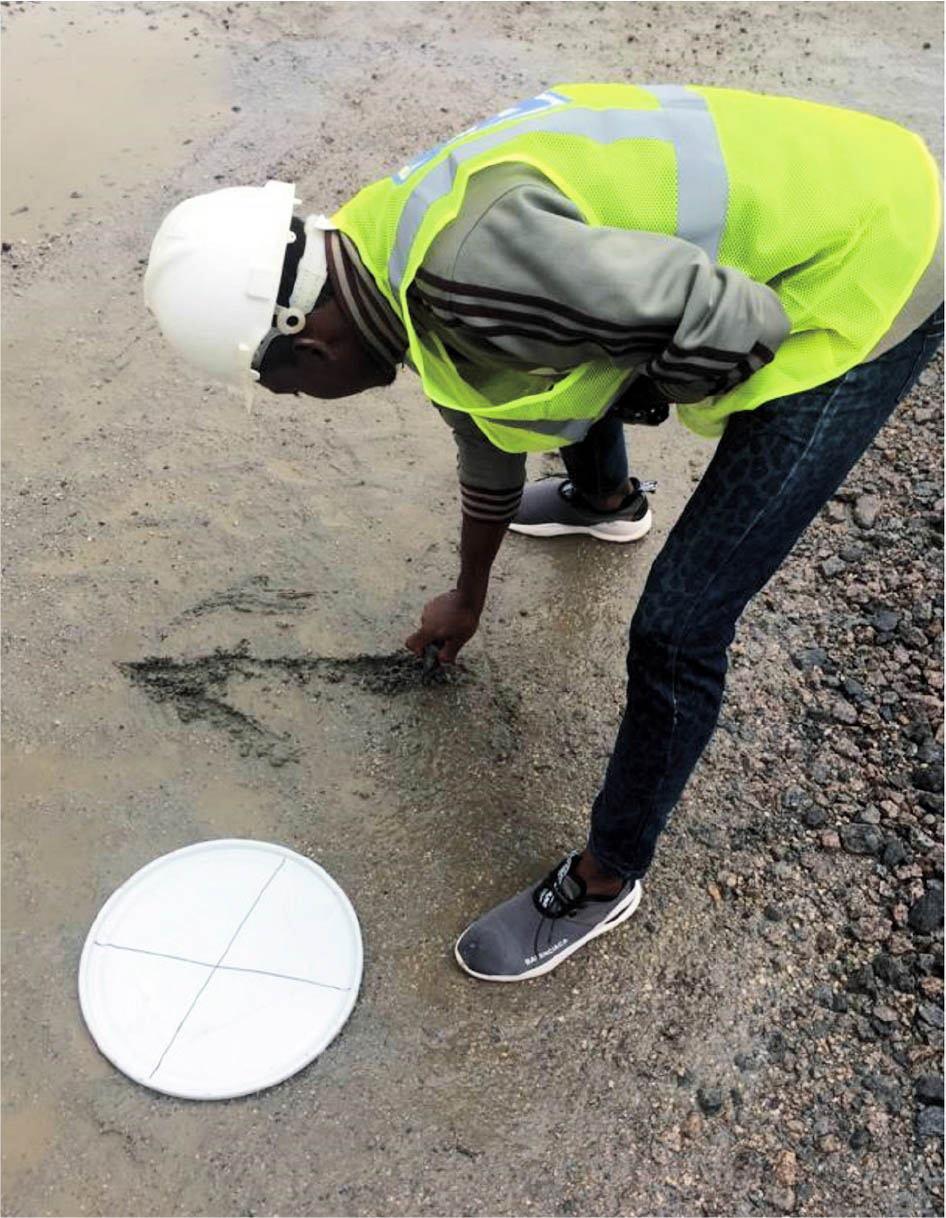
Fig. 3
Ground Control Point (GCP) station selection and marking.
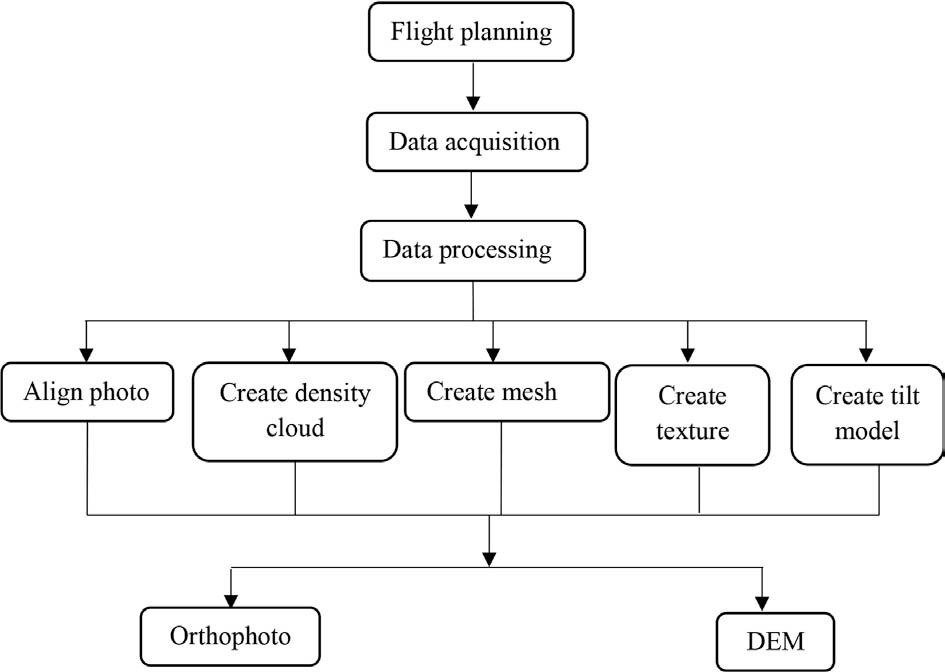
Fig. 4
Workflow of the UAV survey and data processing.
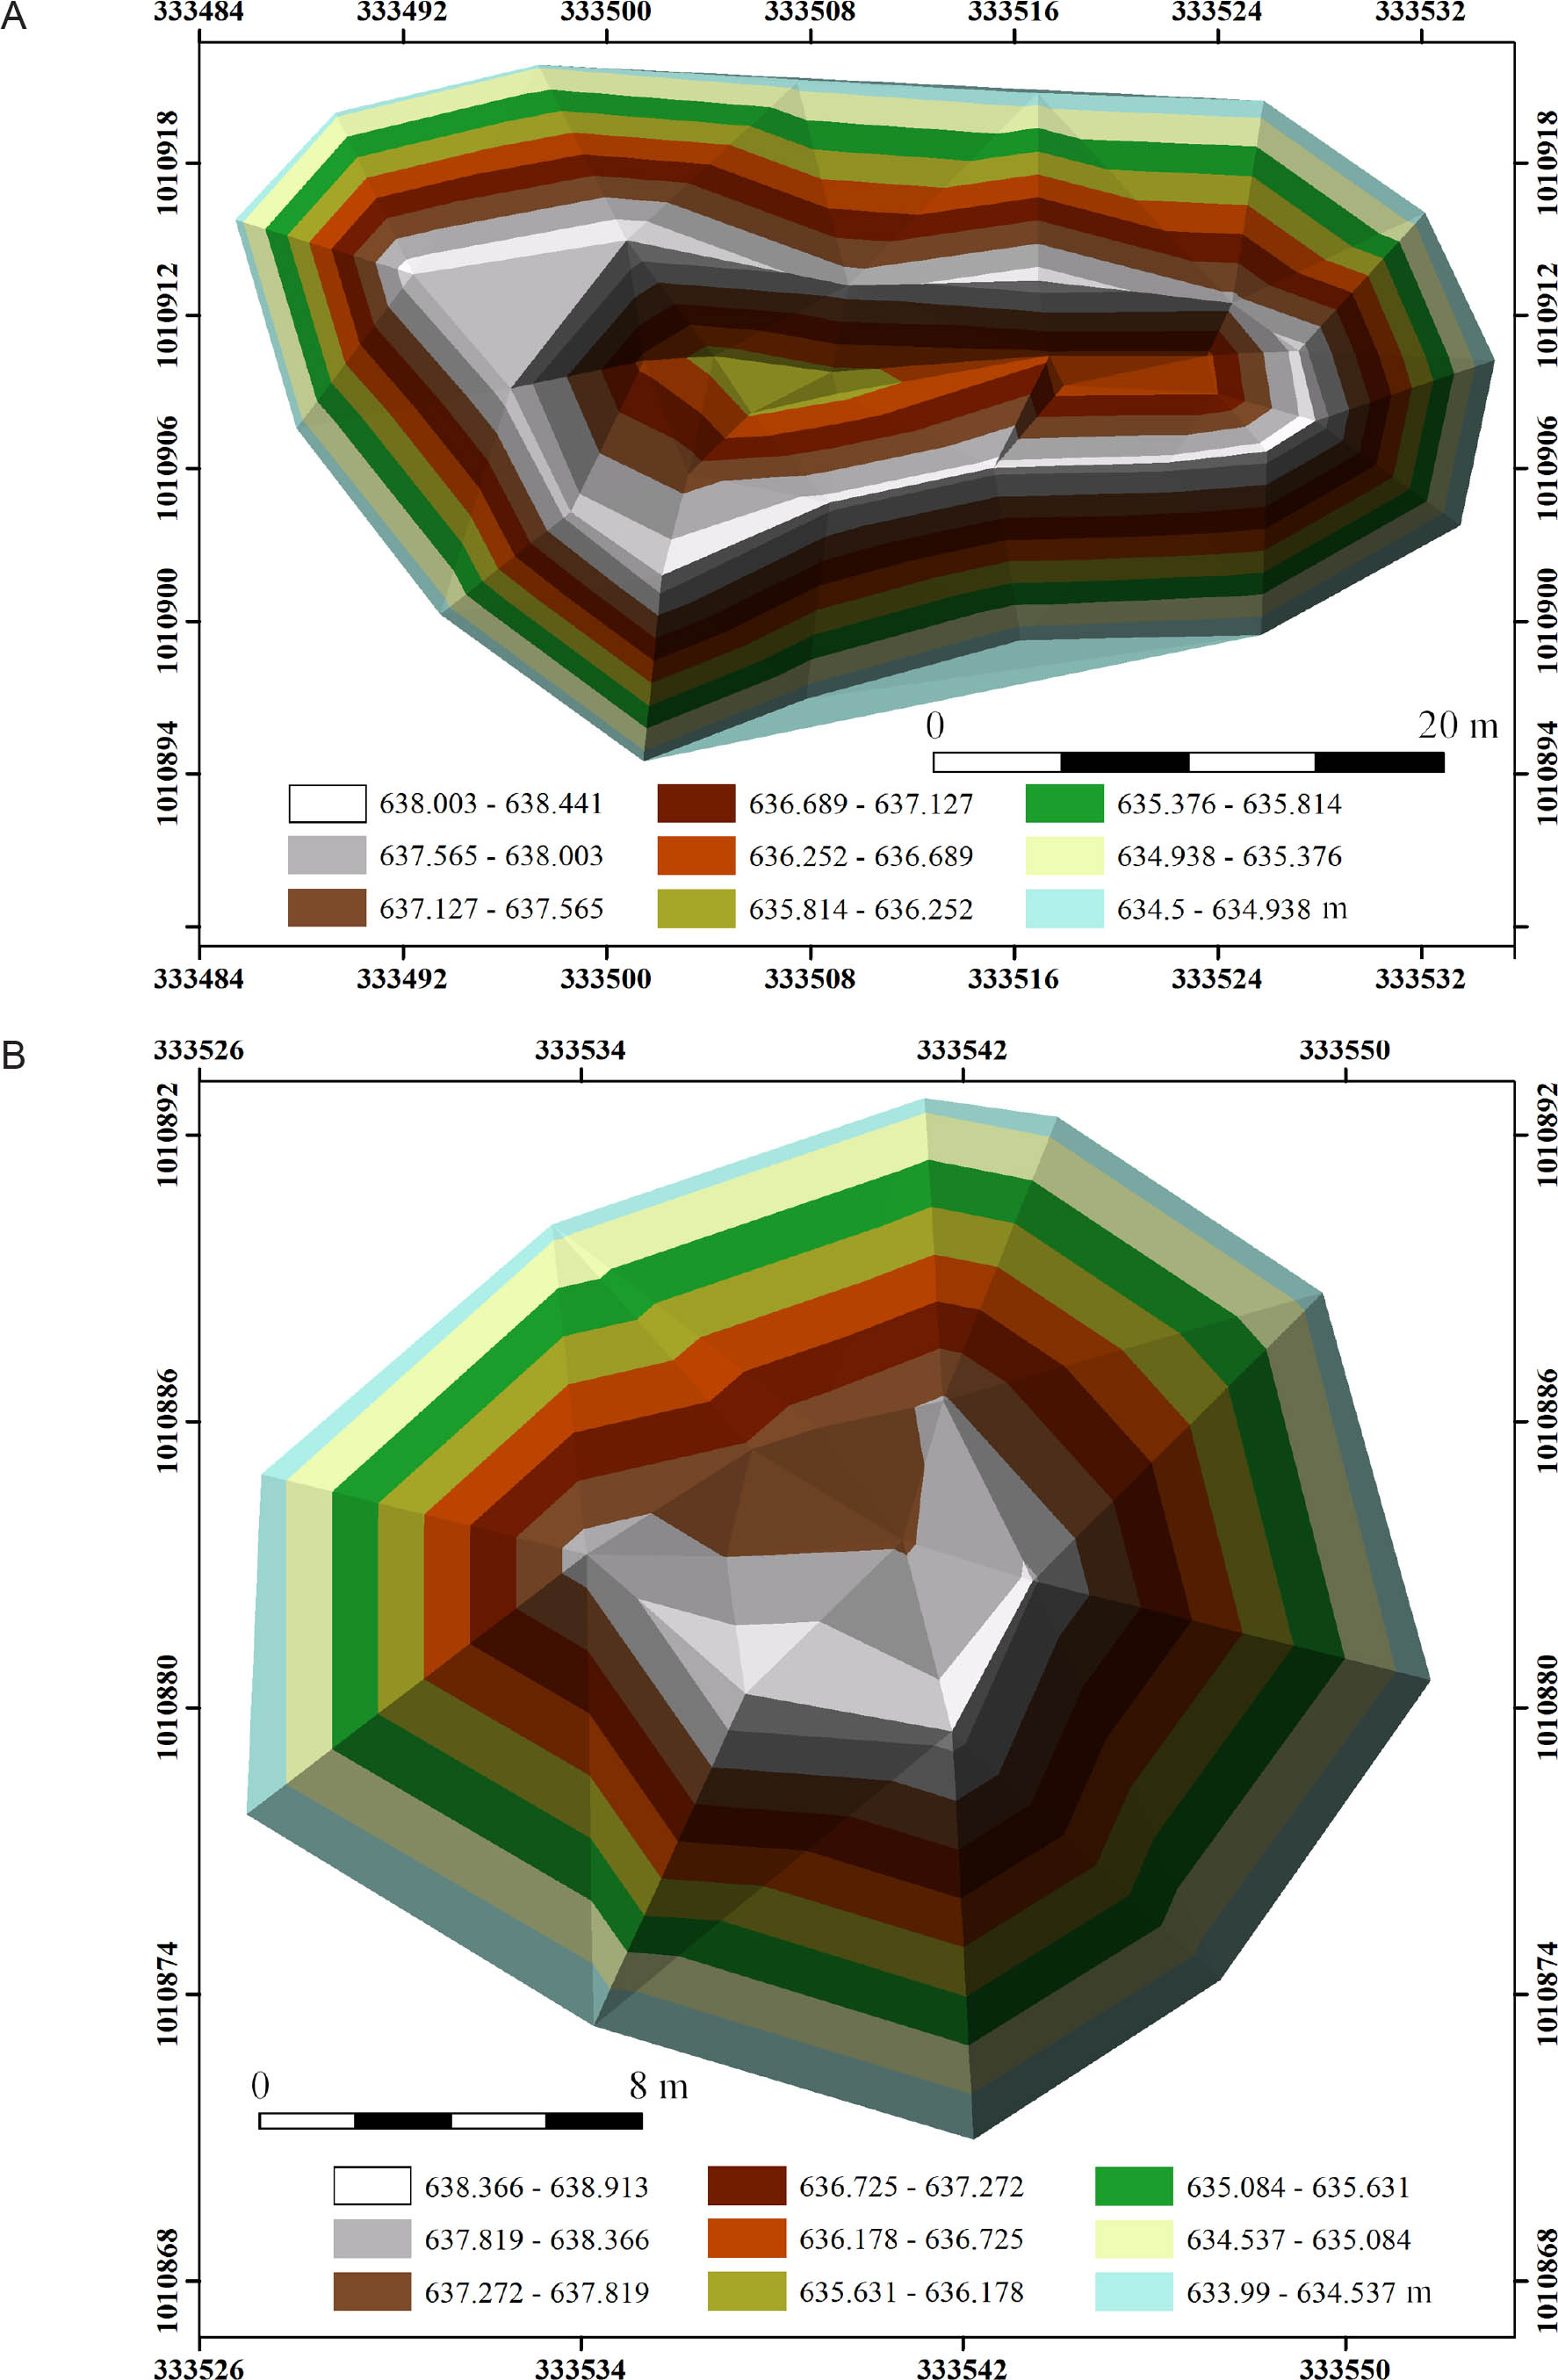
Fig. 5a
TIN model of the stockpiles A and Bgenerated from ArcScene.
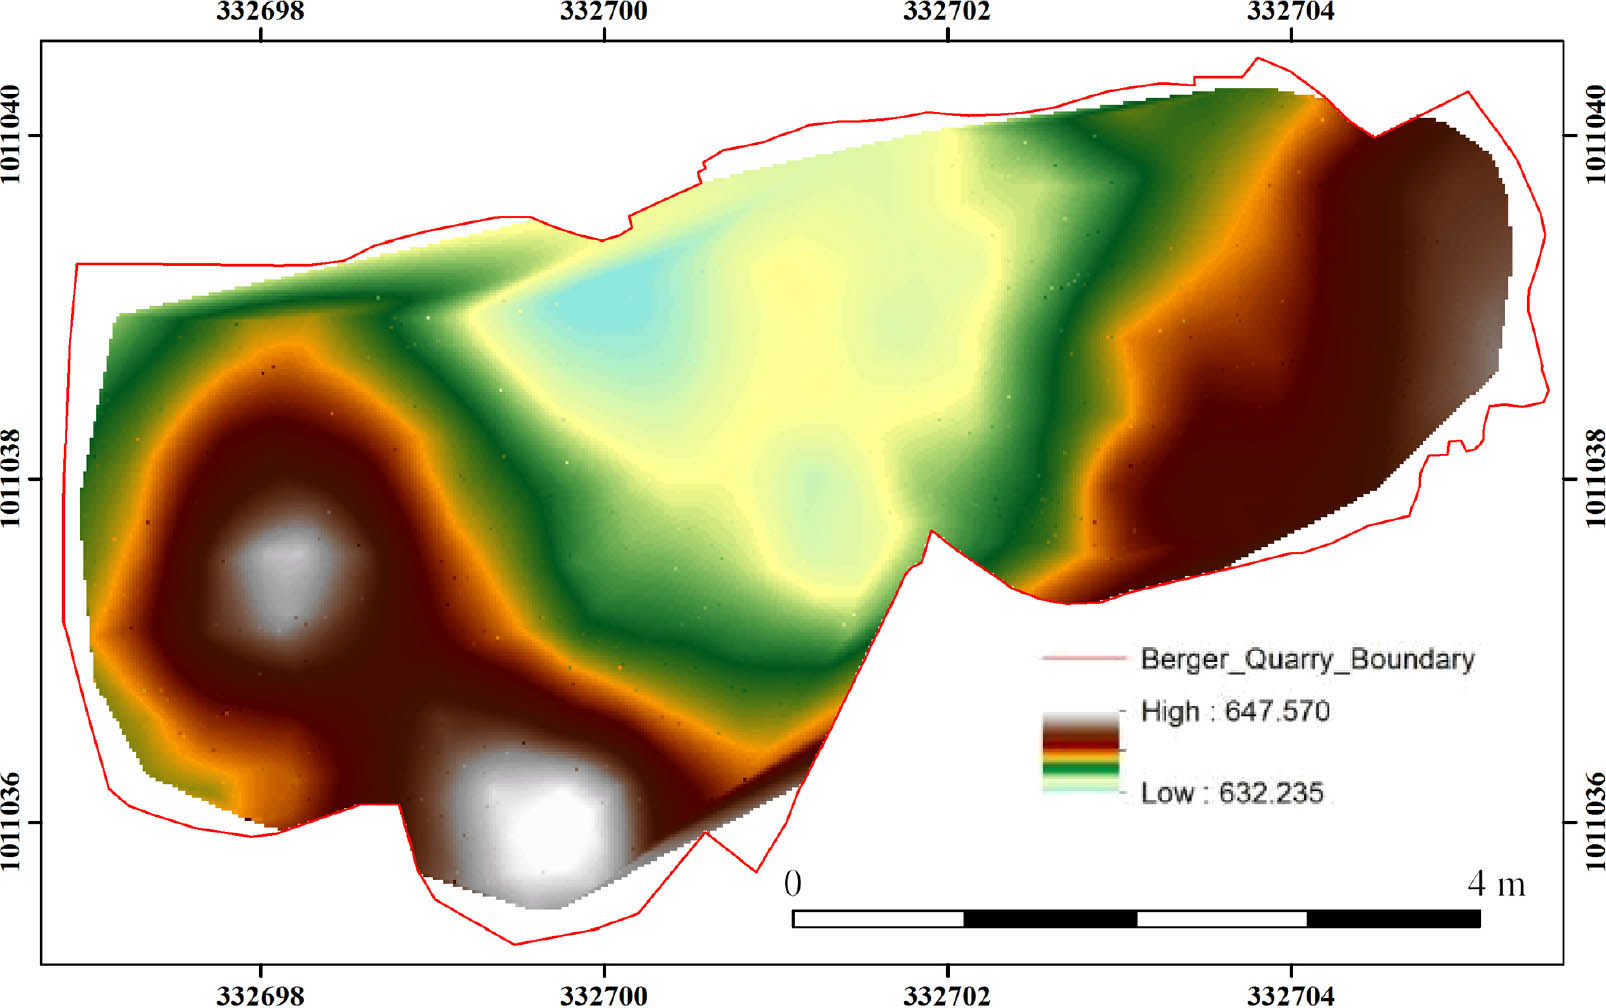
Fig. 5b
TST generated Digital Elevation Model of the stockpiles
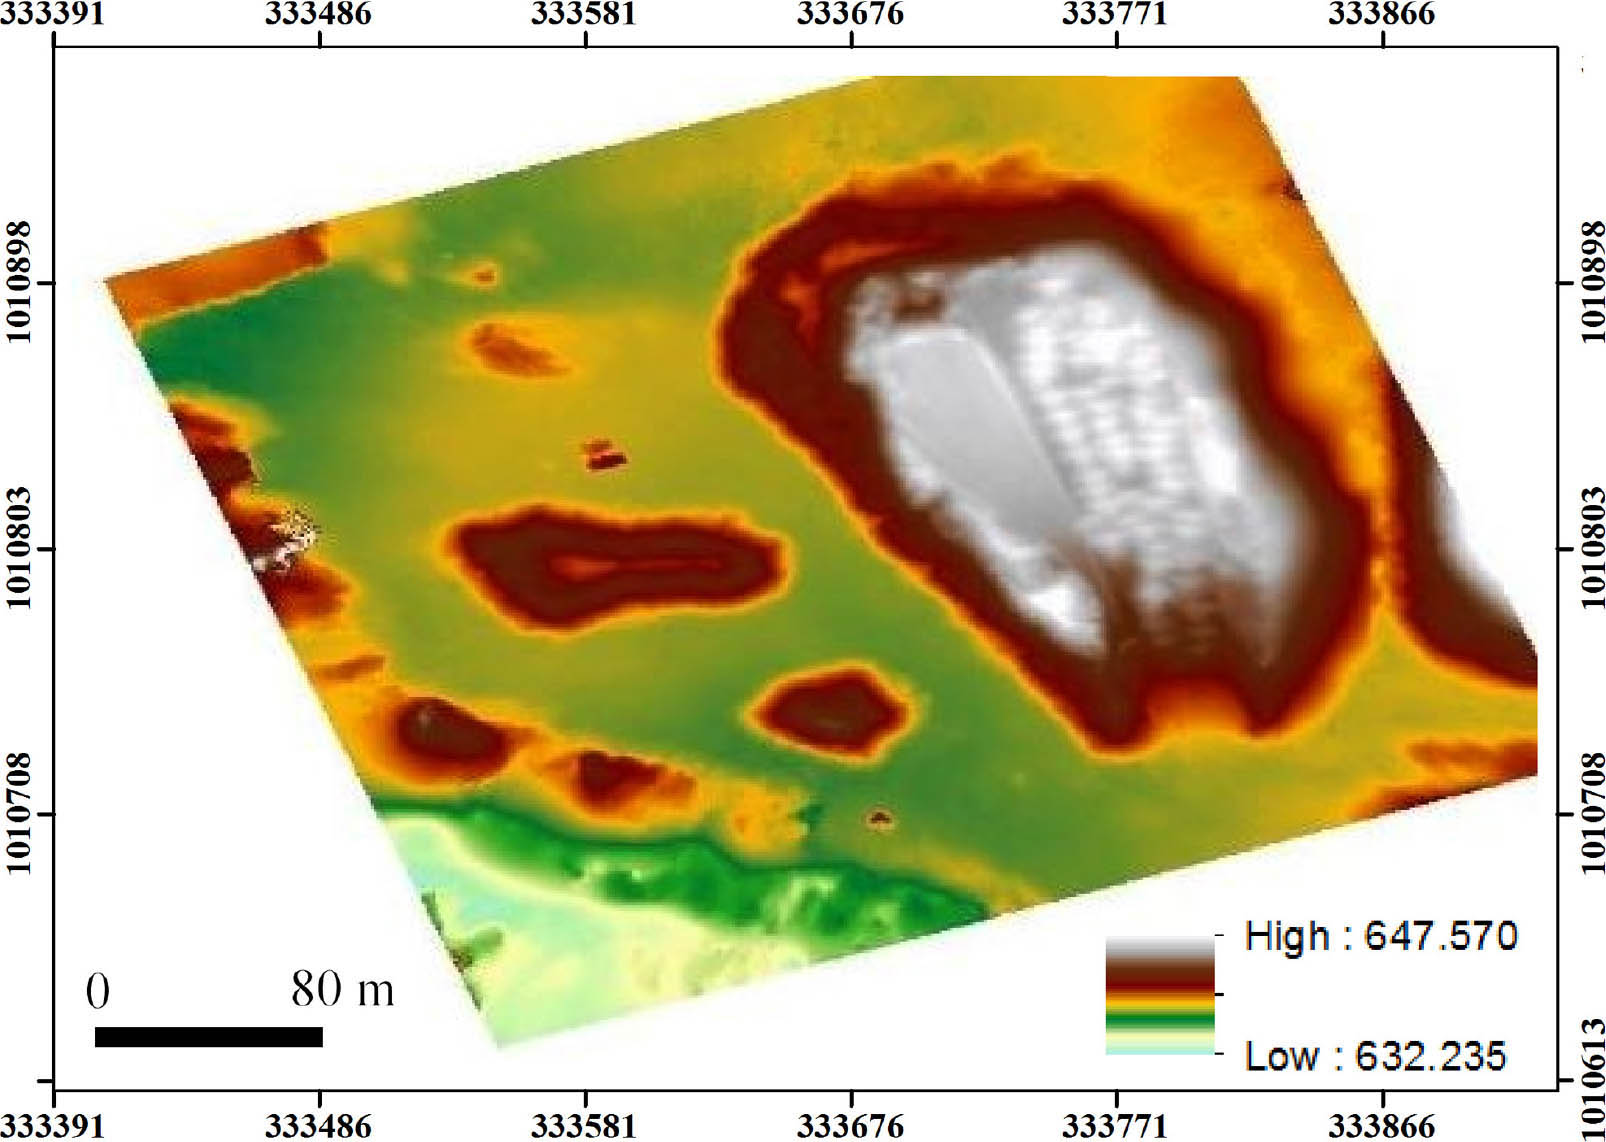
Fig. 6
DEM generated from Agisoft.
Table 2
The calibration coefficient and correlation matrix.
| Value | Error | F | K1 | K2 | K3 | P1 | P2 | |
|---|---|---|---|---|---|---|---|---|
| F | 272.73 | 4.2 | 1.00 | 0.75 | −0.97 | −0.98 | −0.14 | −0.12 |
| K1 | 0.230625 | 0.0008 | – | 1.00 | −0.84 | −0.84 | −0.64 | −0.49 |
| K2 | −0.438133 | 0.0027 | – | – | −1.00 | −1.00 | −0.23 | −0.19 |
| K3 | 0.252709 | 0.0023 | – | – | – | −1.00 | −0.22 | −0.18 |
| P1 | −0.00342852 | 3.9e-005 | – | – | – | – | −1.00 | −0.62 |
| P2 | 0.00346376 | 3.2e-005 | – | – | – | – | – | −1.00 |
Table 3
Average camera location error.
| Camera location component | Error [m] |
|---|---|
| X | 8.35685 |
| Y | 9.07843 |
| Z | 3.01858 |
| XY | 12.339200 |
| Total | 12.703000 |
Table 4
Results of the comparative analysis of the volumes obtained from the TST-produced TIN and the UAV-produced DEM.
| Instrument | Model | Stockpile 1 approx. volume [m3] | Stockpile 2 approx. volume [m3] | Total volume [m3] | Difference between the actual volume and cumulative estimated volume | Standard deviation | Standard error (degree of uncertainty) |
|---|---|---|---|---|---|---|---|
| Actual volume from mill machine | 2750.00 | ||||||
| Total station | TST TIN | 2031.31 | 799.41 | 2830.72 | −80.72 | ±70.23 | +2.9% |
| UAV | UAV DEM | 1902.76 | 783.49 | 2686.25 | −63.74 | ±72.23 | −2.3% |