
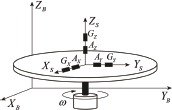
Figure 1.
Scheme of the IMU on a rotating platform. XBYBZB – the body frame; XSYSZS – the sensor frame. IMU, inertial measurement unit.
Table 1.
Characteristics of IMU Xsens MTI-1 sensors.
| Accelometr block | Gyroscope block | |
|---|---|---|
| Measurement range | ±16 g | ±2,000°/s |
| Zero offset instability | 0.03 mg | 10°/h |
| Bandwidth (–3 dB) | 324 (Z: 262) Hz | 255 Hz |
| Noise density | 120μg/√Hz | 0.007°/s/√Hz |
| Non-linearity | 0.5%FS | 0.1%FS |
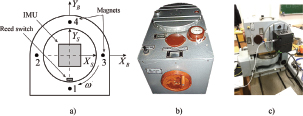
Figure 2.
Scheme of the stand of static products (A). uniaxial rotary stand MPU-1 (B) and a test sample, installed on it in a position with a horizontal axis of rotation (C).
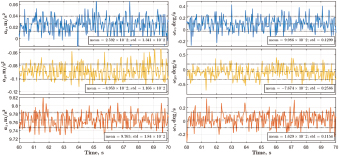
Figure 3.
IMU output without modulating rotation. IMU, inertial measurement unit.
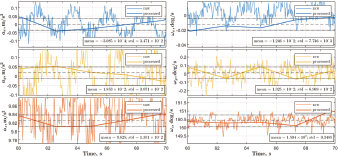
Figure 4.
Output signals of rotated IMU with modulating rotation along a vertical axis. IMU, inertial measurement unit.
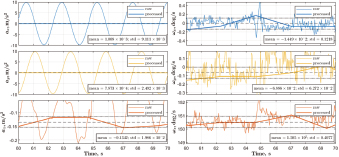
Figure 5.
Output signals of rotated IMU with modulating rotation along a horizontal axis. IMU, inertial measurement unit.
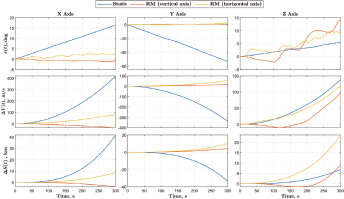
Figure 6.
Graphs of the estimations (3) of the RM IMU with vertical and horizontal rotation axis compared with the stationary case. IMU, inertial measurement unit; RM, rotation modulation.