
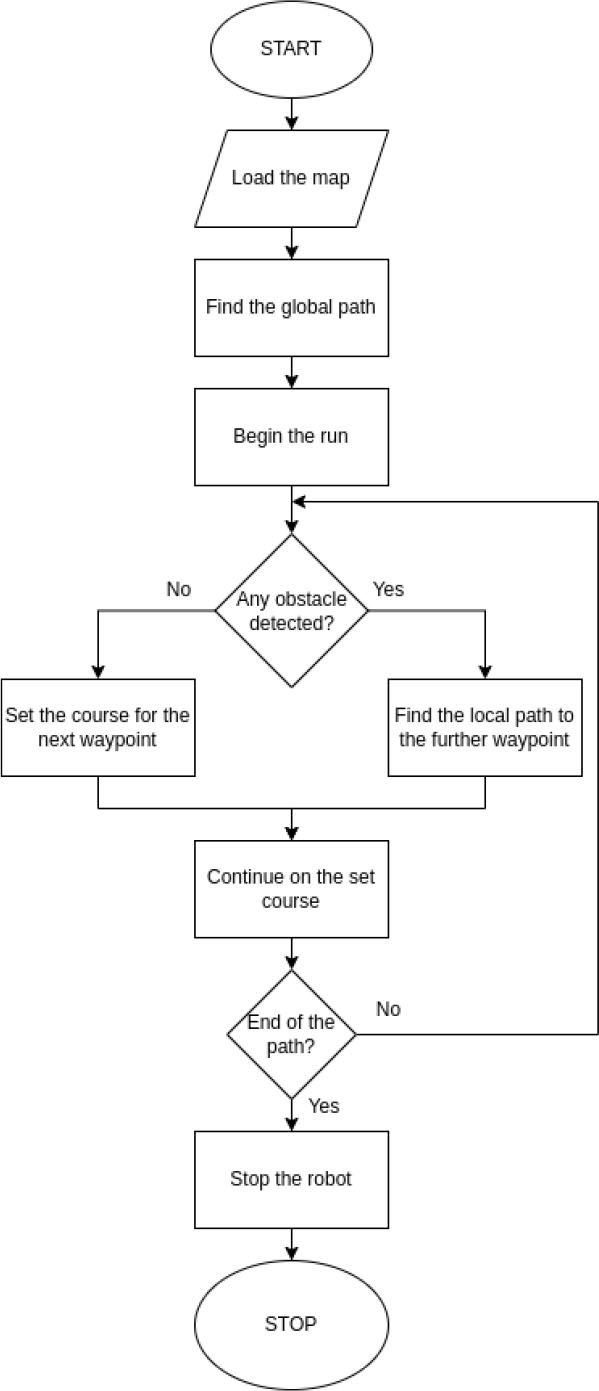
Fig. 1.
Flowchart of 3K method
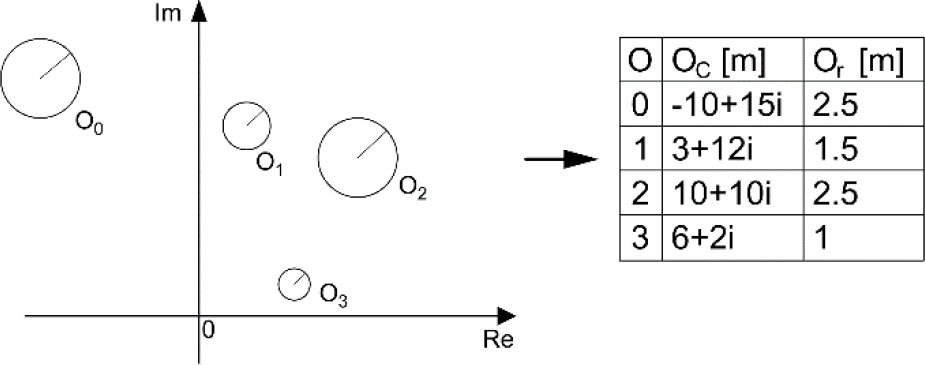
Fig. 2.
Example of map model
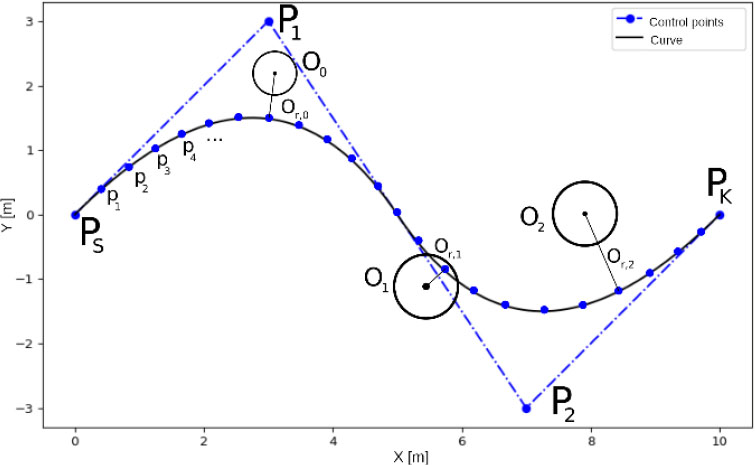
Fig. 3.
Example of collision detection between B-spline and circle-shaped obstacles
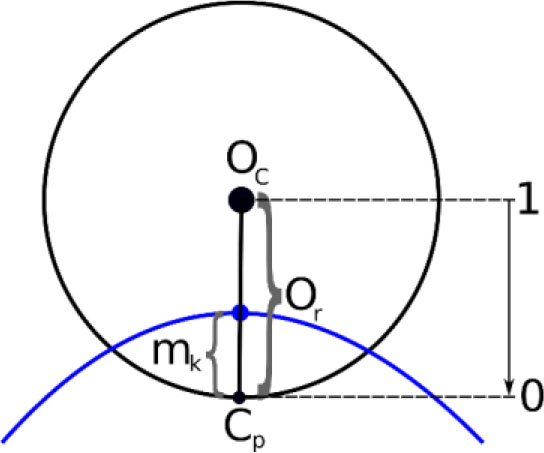
Fig. 4.
Visualization of the collision depth
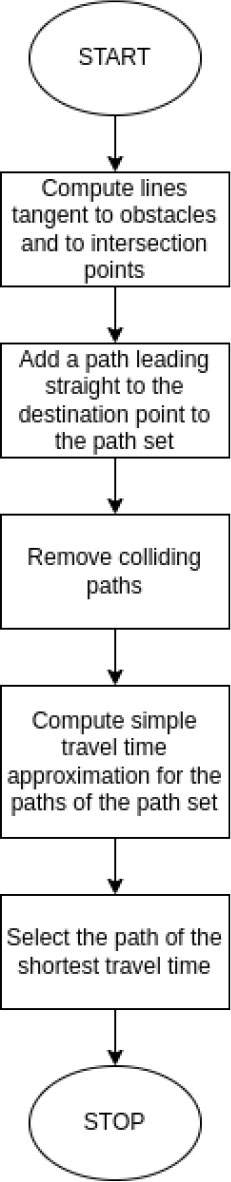
Fig. 5.
Flowchart of the local path finding method
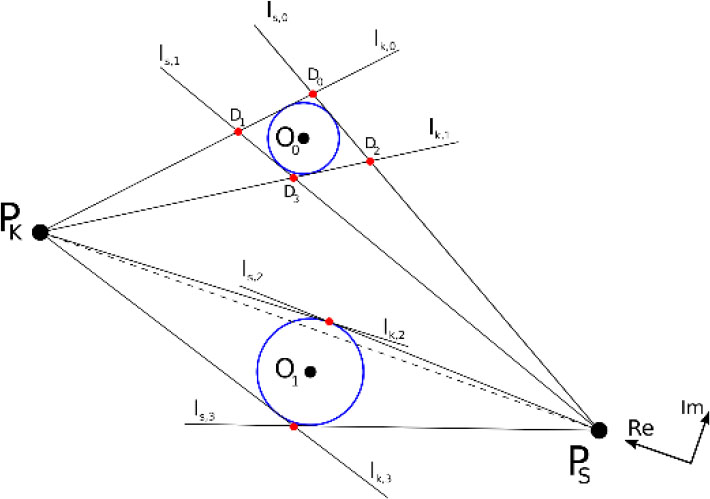
Fig. 6.
Visualization of local path computation